New Tv2 Circuit, Design Reasoning and Side Projects
Fingers Crossed This Works
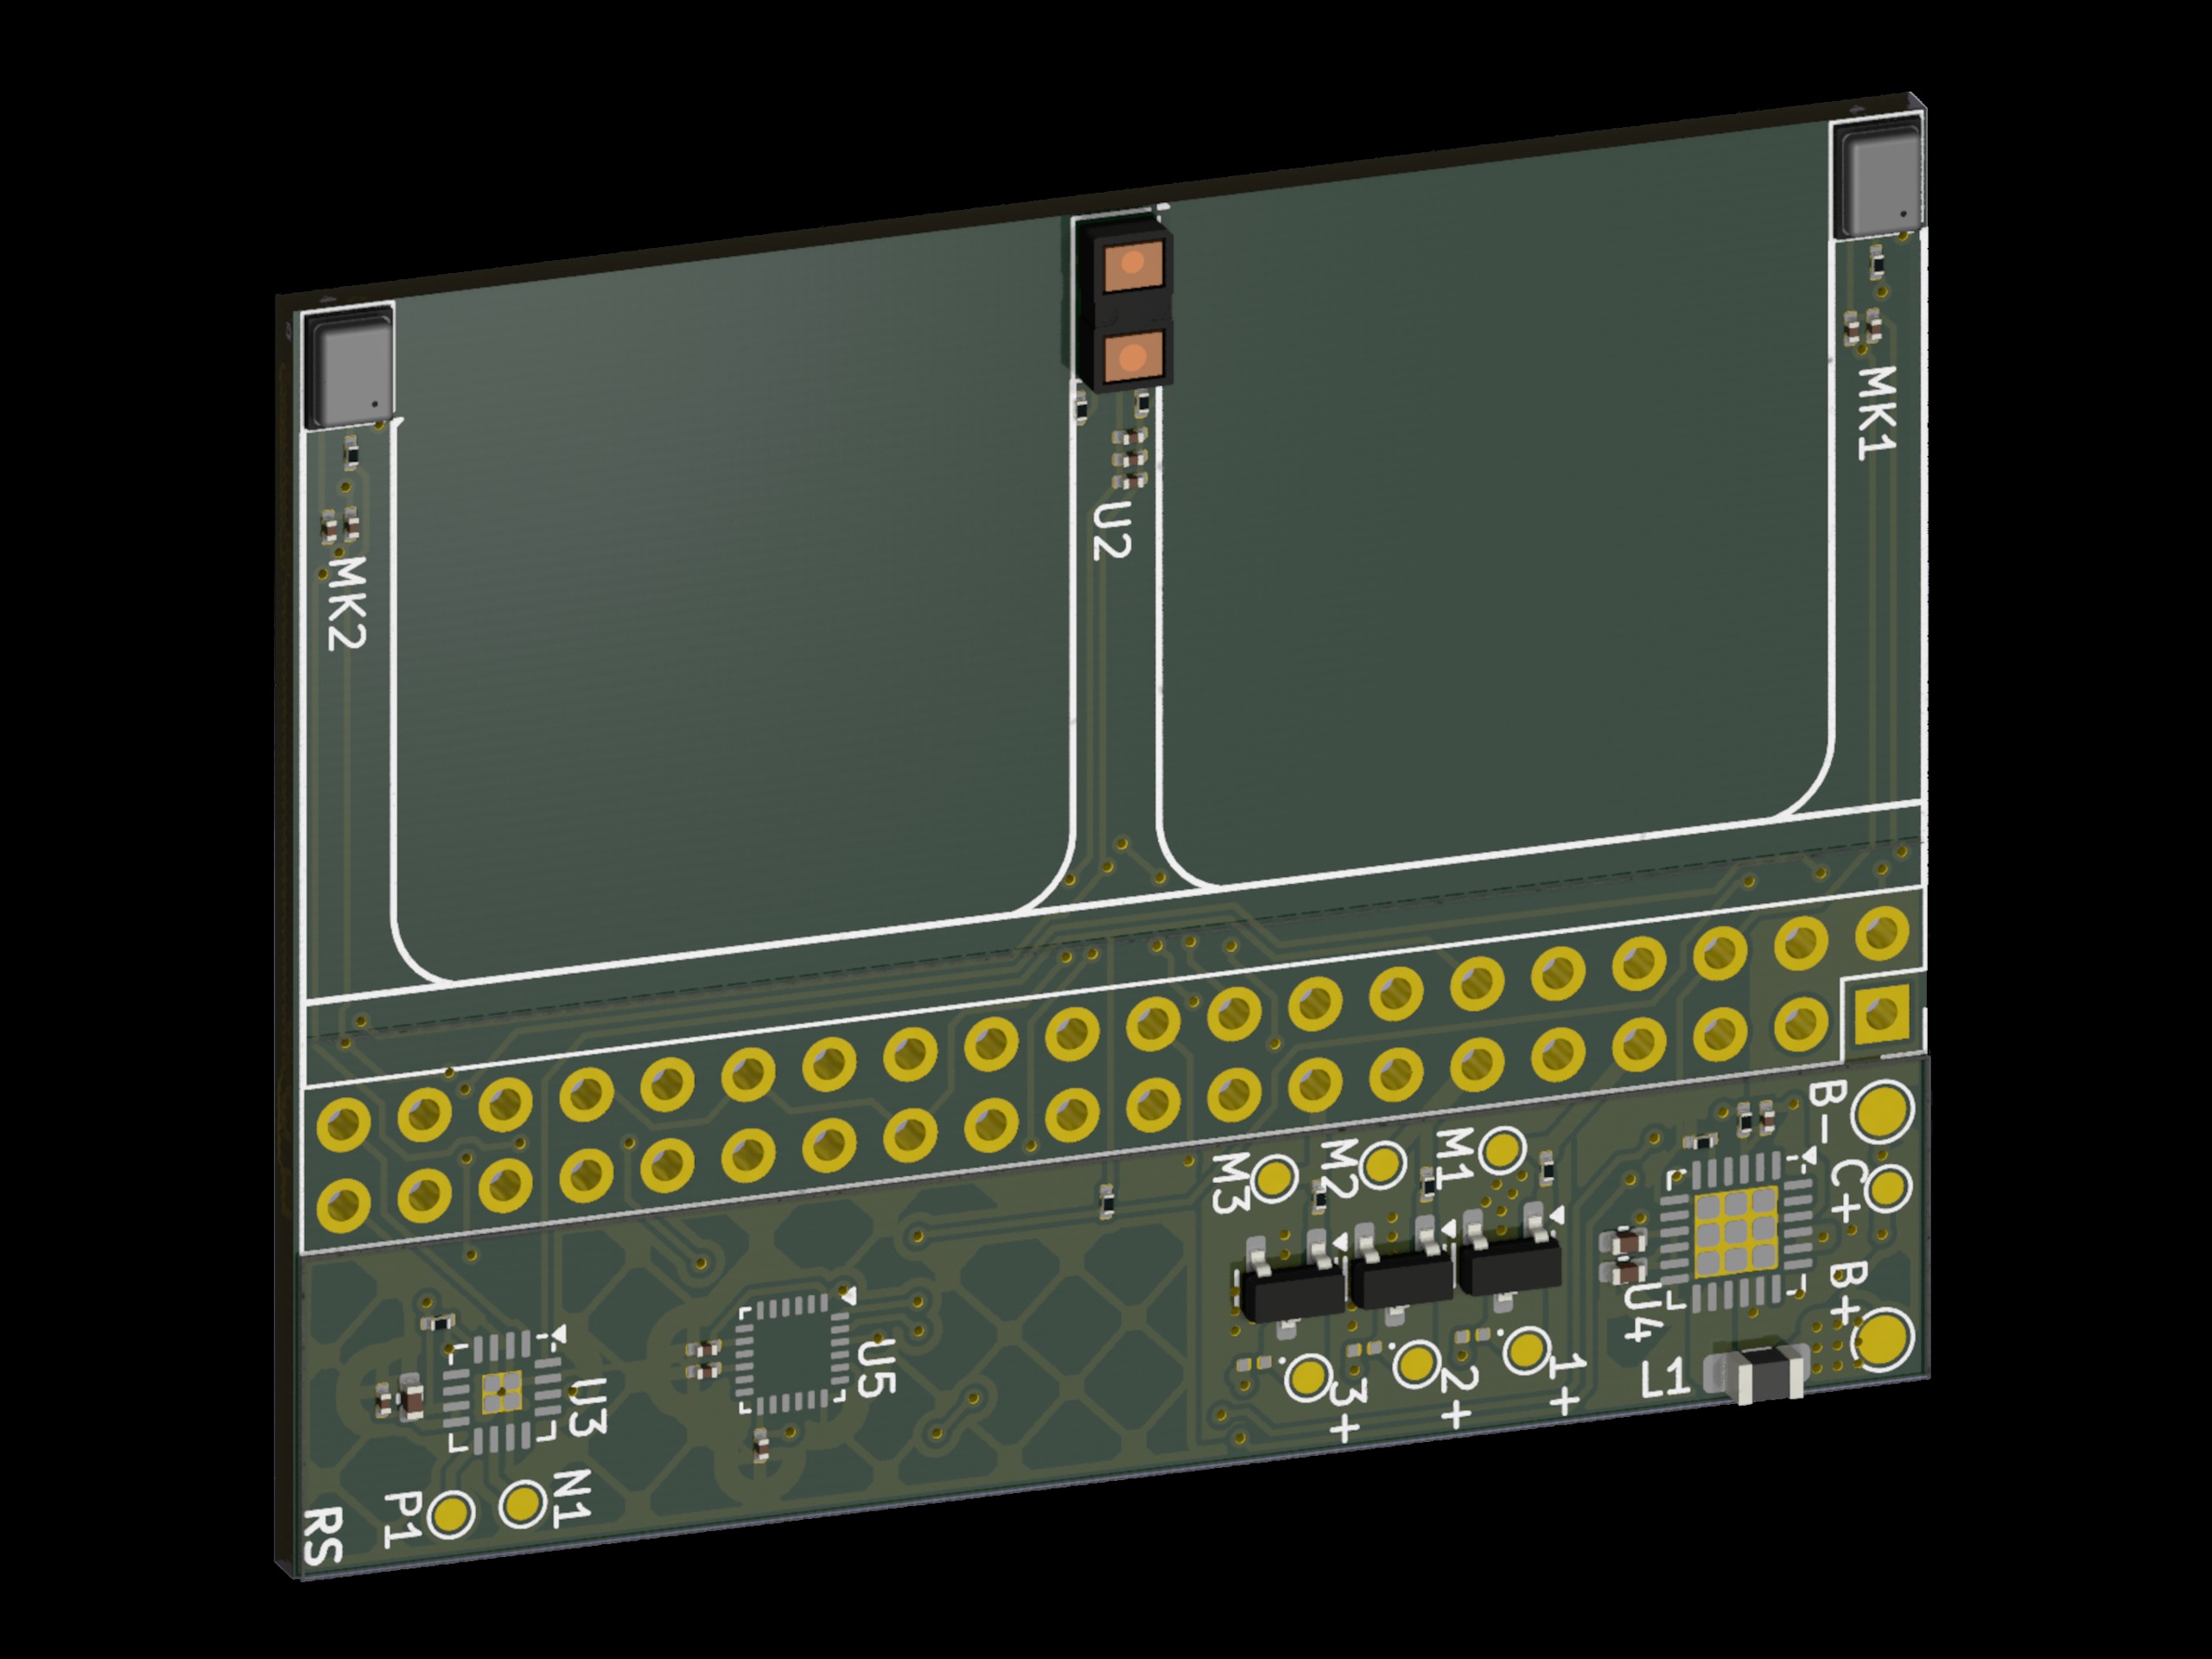
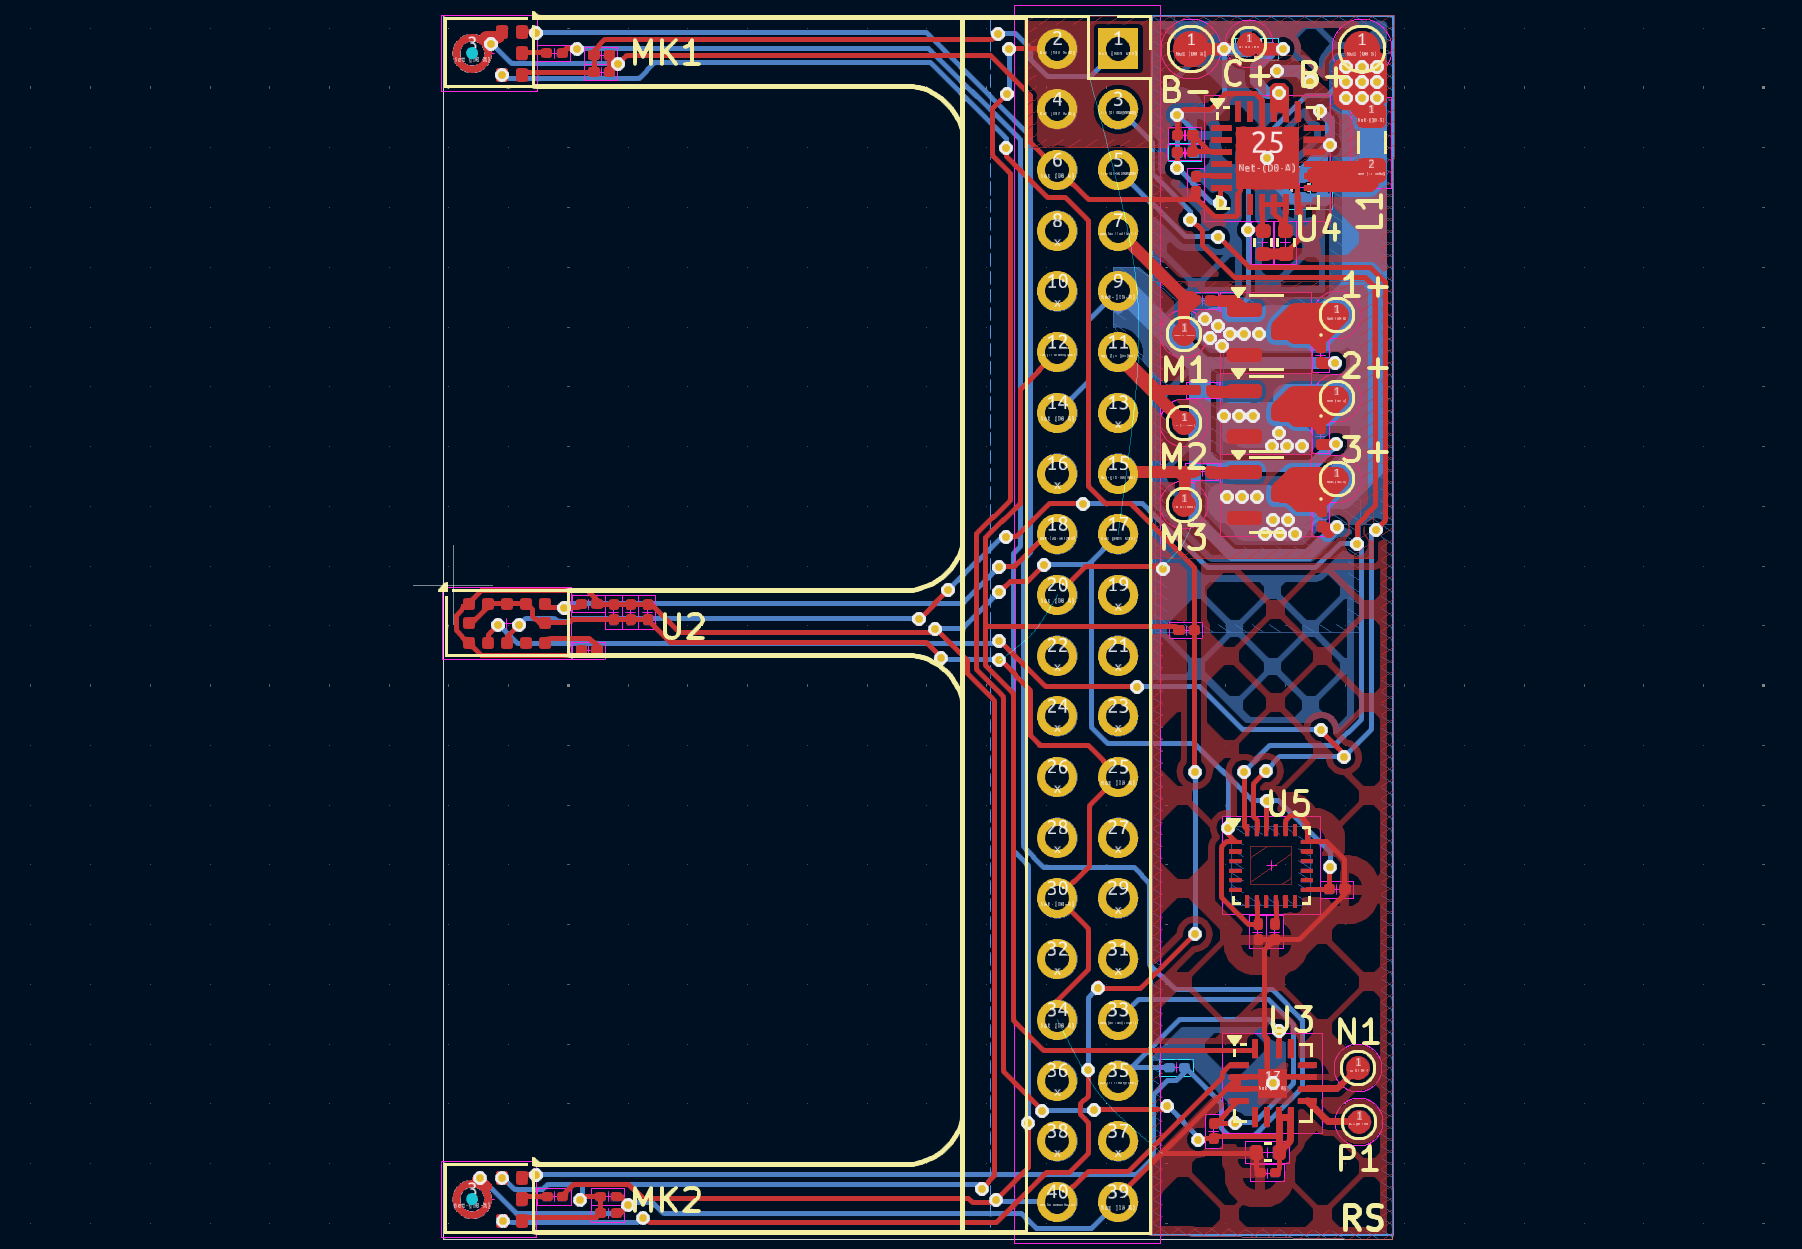
5 Sensors, Power management and motor/speaker output on one tiny board
This is going to a flexible pcb “hat” for my raspberry pi zero that integrates everything the robot needs. I’m using an IP5209 powerbank IC to charge and boost the battery to 5V for the raspberry pi. I put the three mosfets for the motors on this board because I want all the weight at the bottom. I still have 4 more of the flexible LED matrix PCBs so I’ll solder one of those up without the mosfets. This should minimize the amount of wires I need to run and save some weight. The other chips on the board are a MAX98357A for I2S mono audio output and the MPU-9250 for motion data. There is also a vl53l0x TOF sensor and two microphones that I’ll cut out so they can be folded into position. I ordered the board as a full rectangle to make the hot plate soldering easier (these are 0201 components anyway). If I can get all of this working then I’ll move on to designing the full Linux board (likely around the allwinner A33).
Redesigned Circuit from Before Thanksgiving
I thought about wiring boards together like last time but decided it would be too heavy
I didn’t want to make the same mistake I made with the V1 (which was heavy) so I went straight for the PCB instead of building this. The raspberry pi zero adds some weight of course but I’ll remove the ports to minimize this. Eventually I want to try my hand at designing a linux board to replace this raspberry pi but it will be difficult to beat its efficiency and software support.
Why use a Balloon?
Helium is hard to get and hydrogen is dangerous but I feel this is the best route
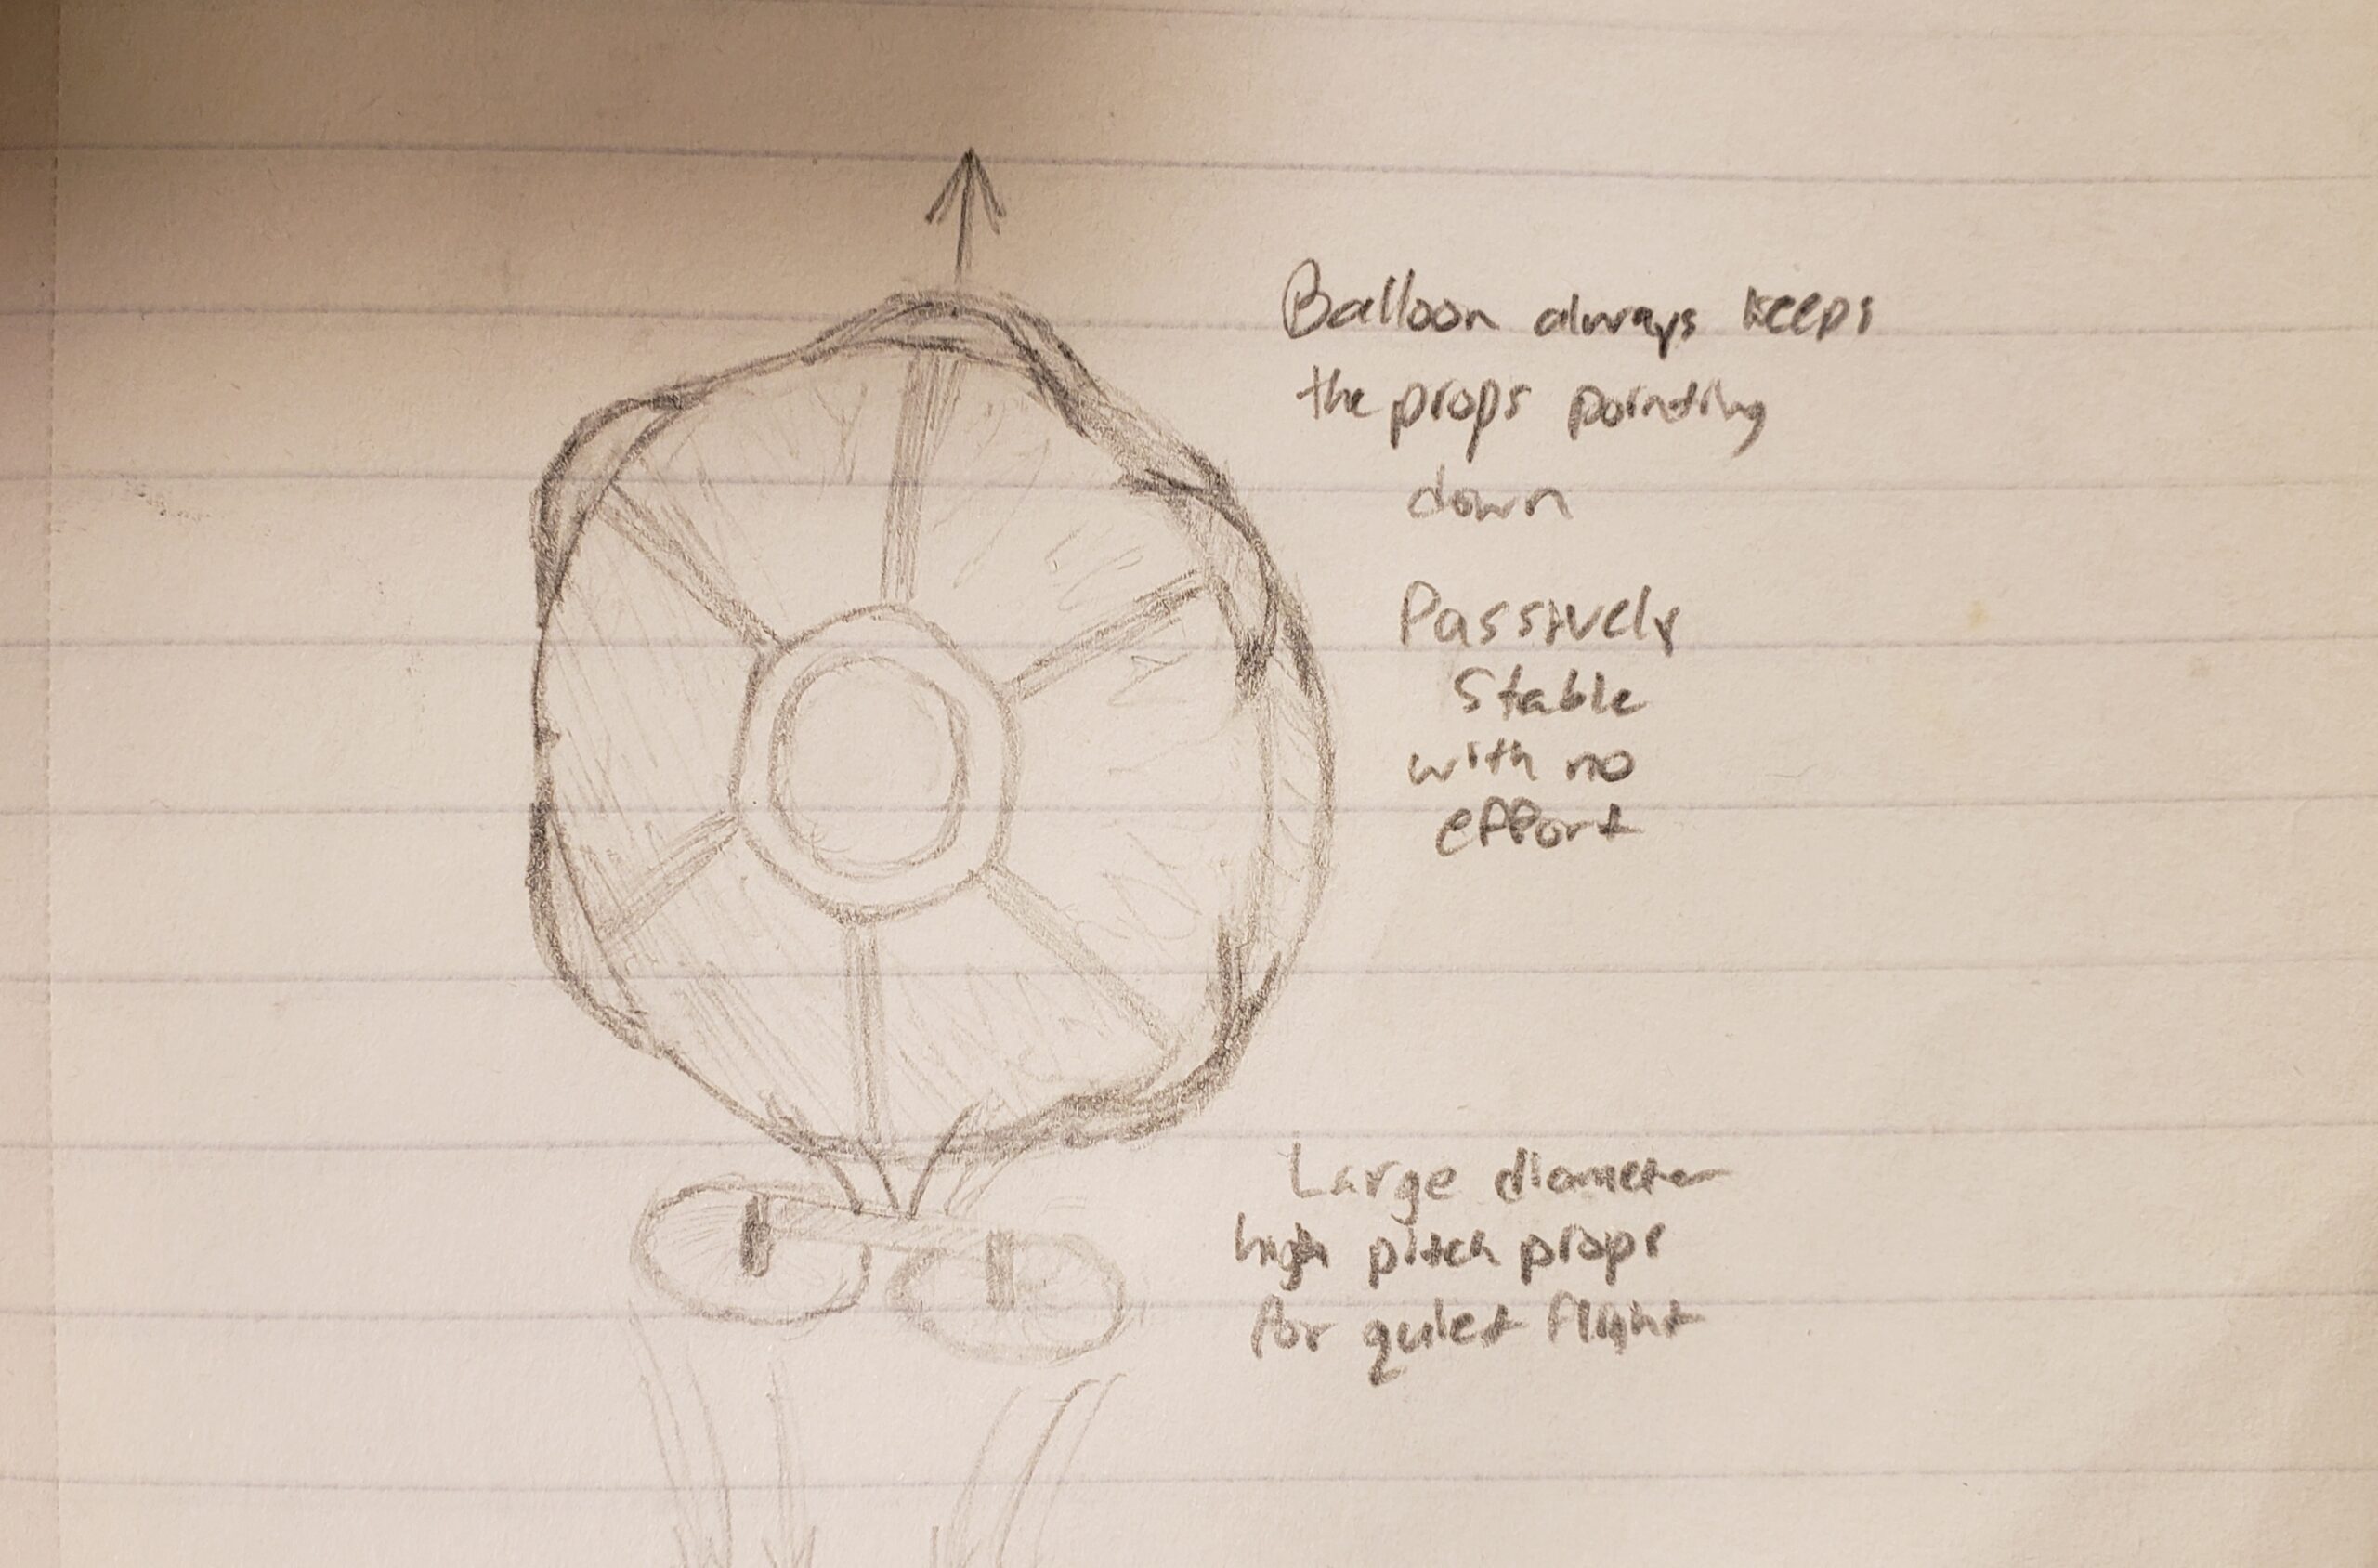
Using a lifting gas is a hassle but I need the main body of the robot to be contributing something. The balloon allows me to keep the look of the V1 while contributing to stability. The balloon makes flight much easier because it ensures that the robot is always upright. It is passively stable and self correcting which will help in an indoor environment around people. Using 4 rotors will increase power consumption and noise while also making the robot less appealing/visible. I really want to keep my original form factor because it just looks better in a picture. I want to build something that people are comfortable talking to and I’m not sure the humanoid robots or traditional drones are going to do that.
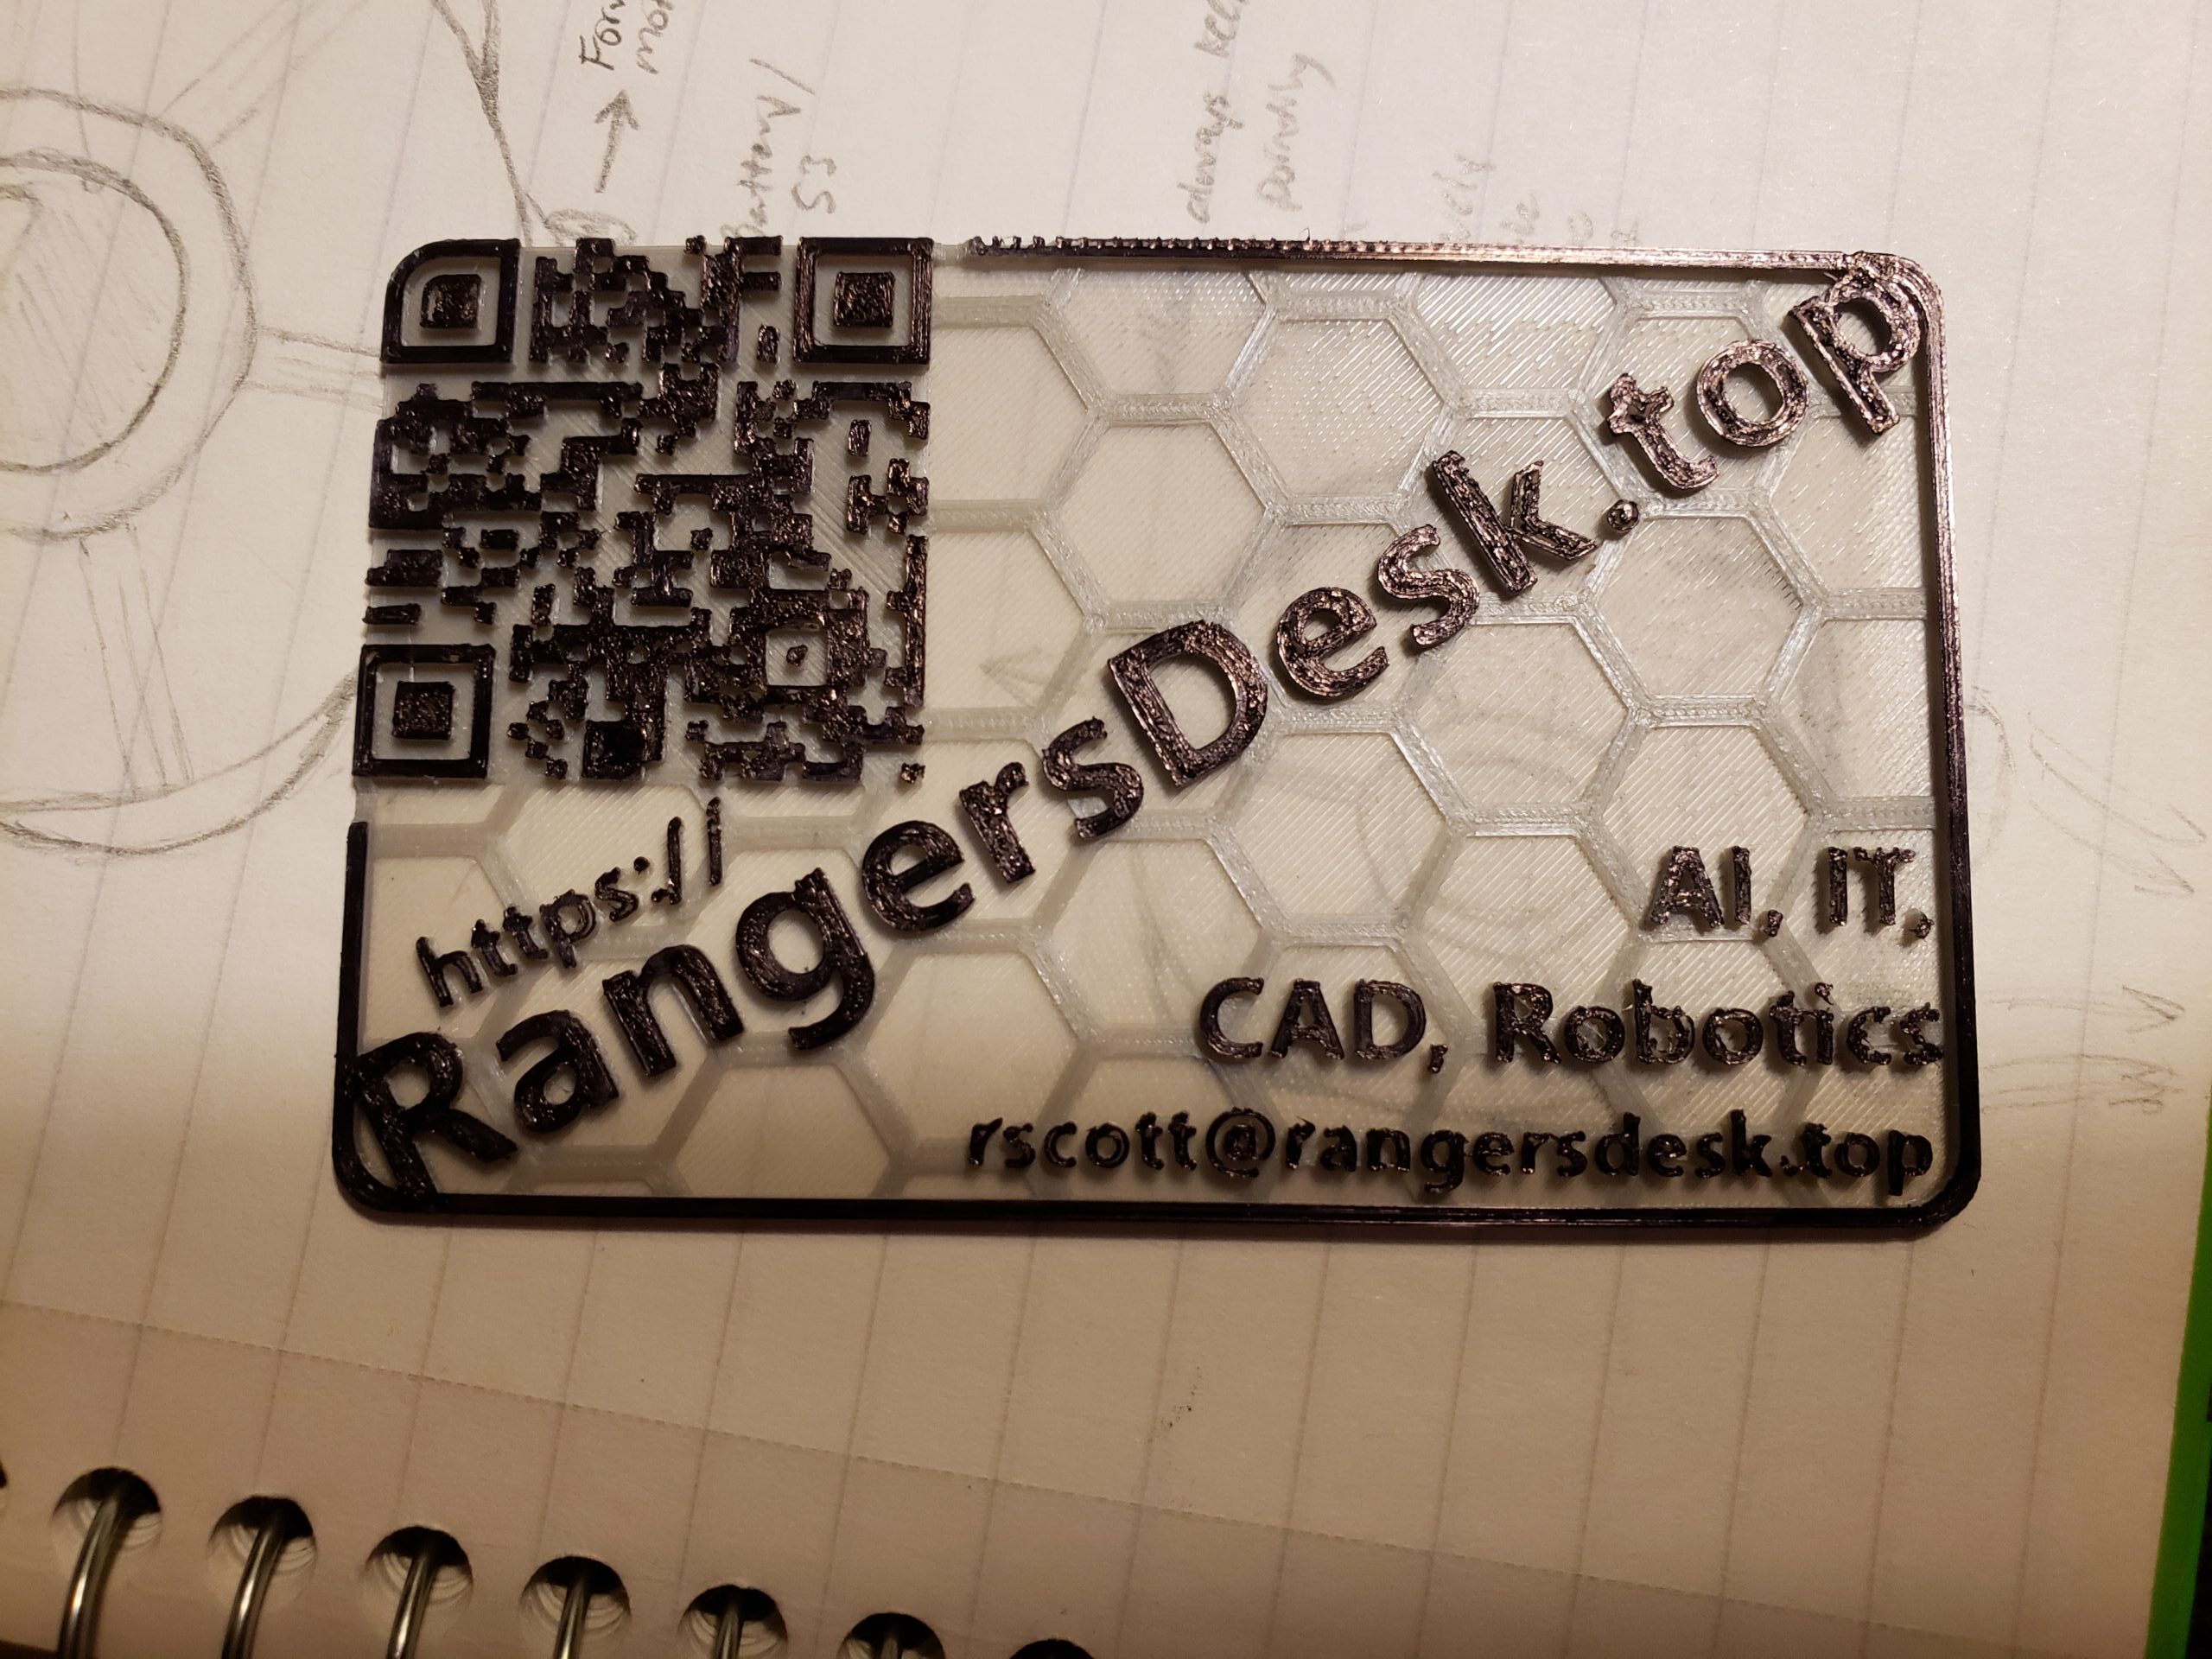
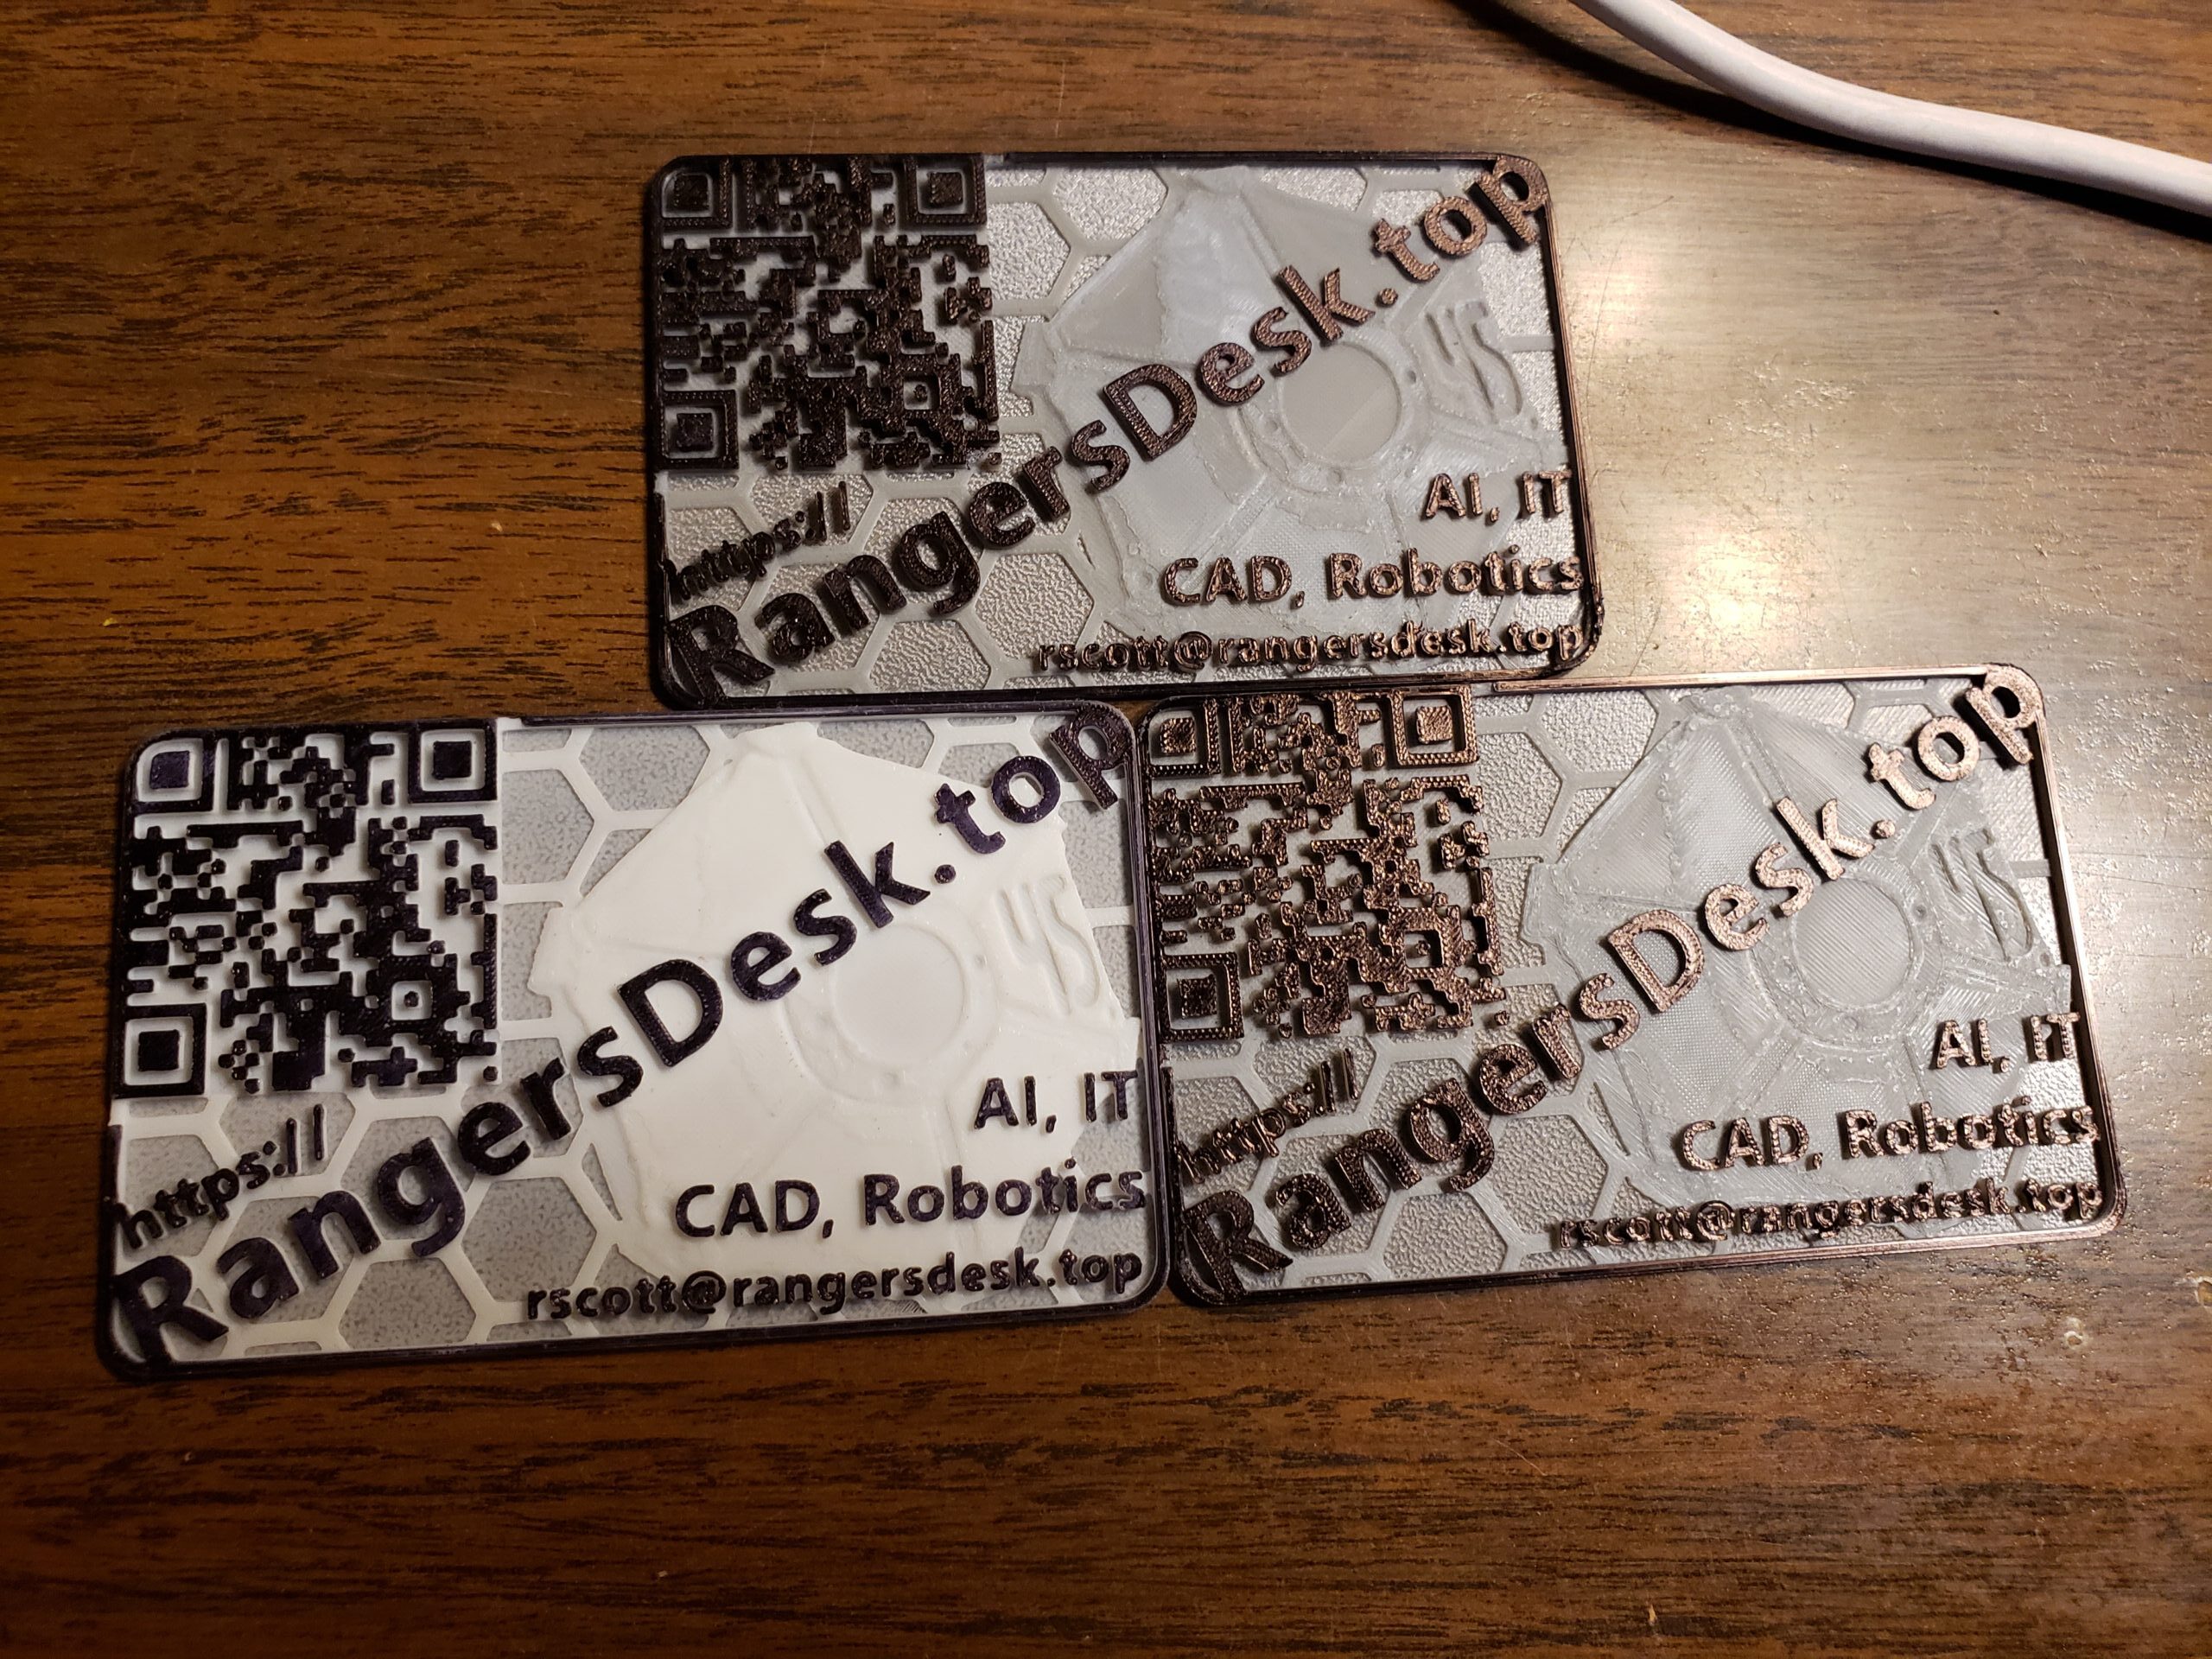
Website Cards Side Project
It’s a distraction but I think it was worth it
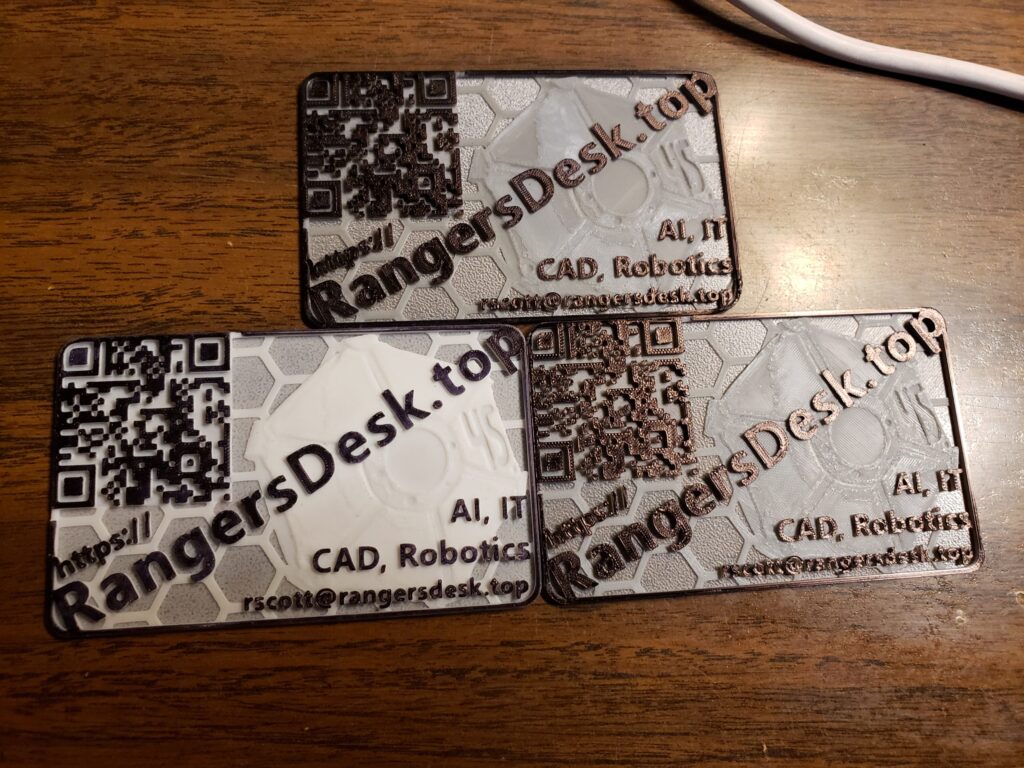
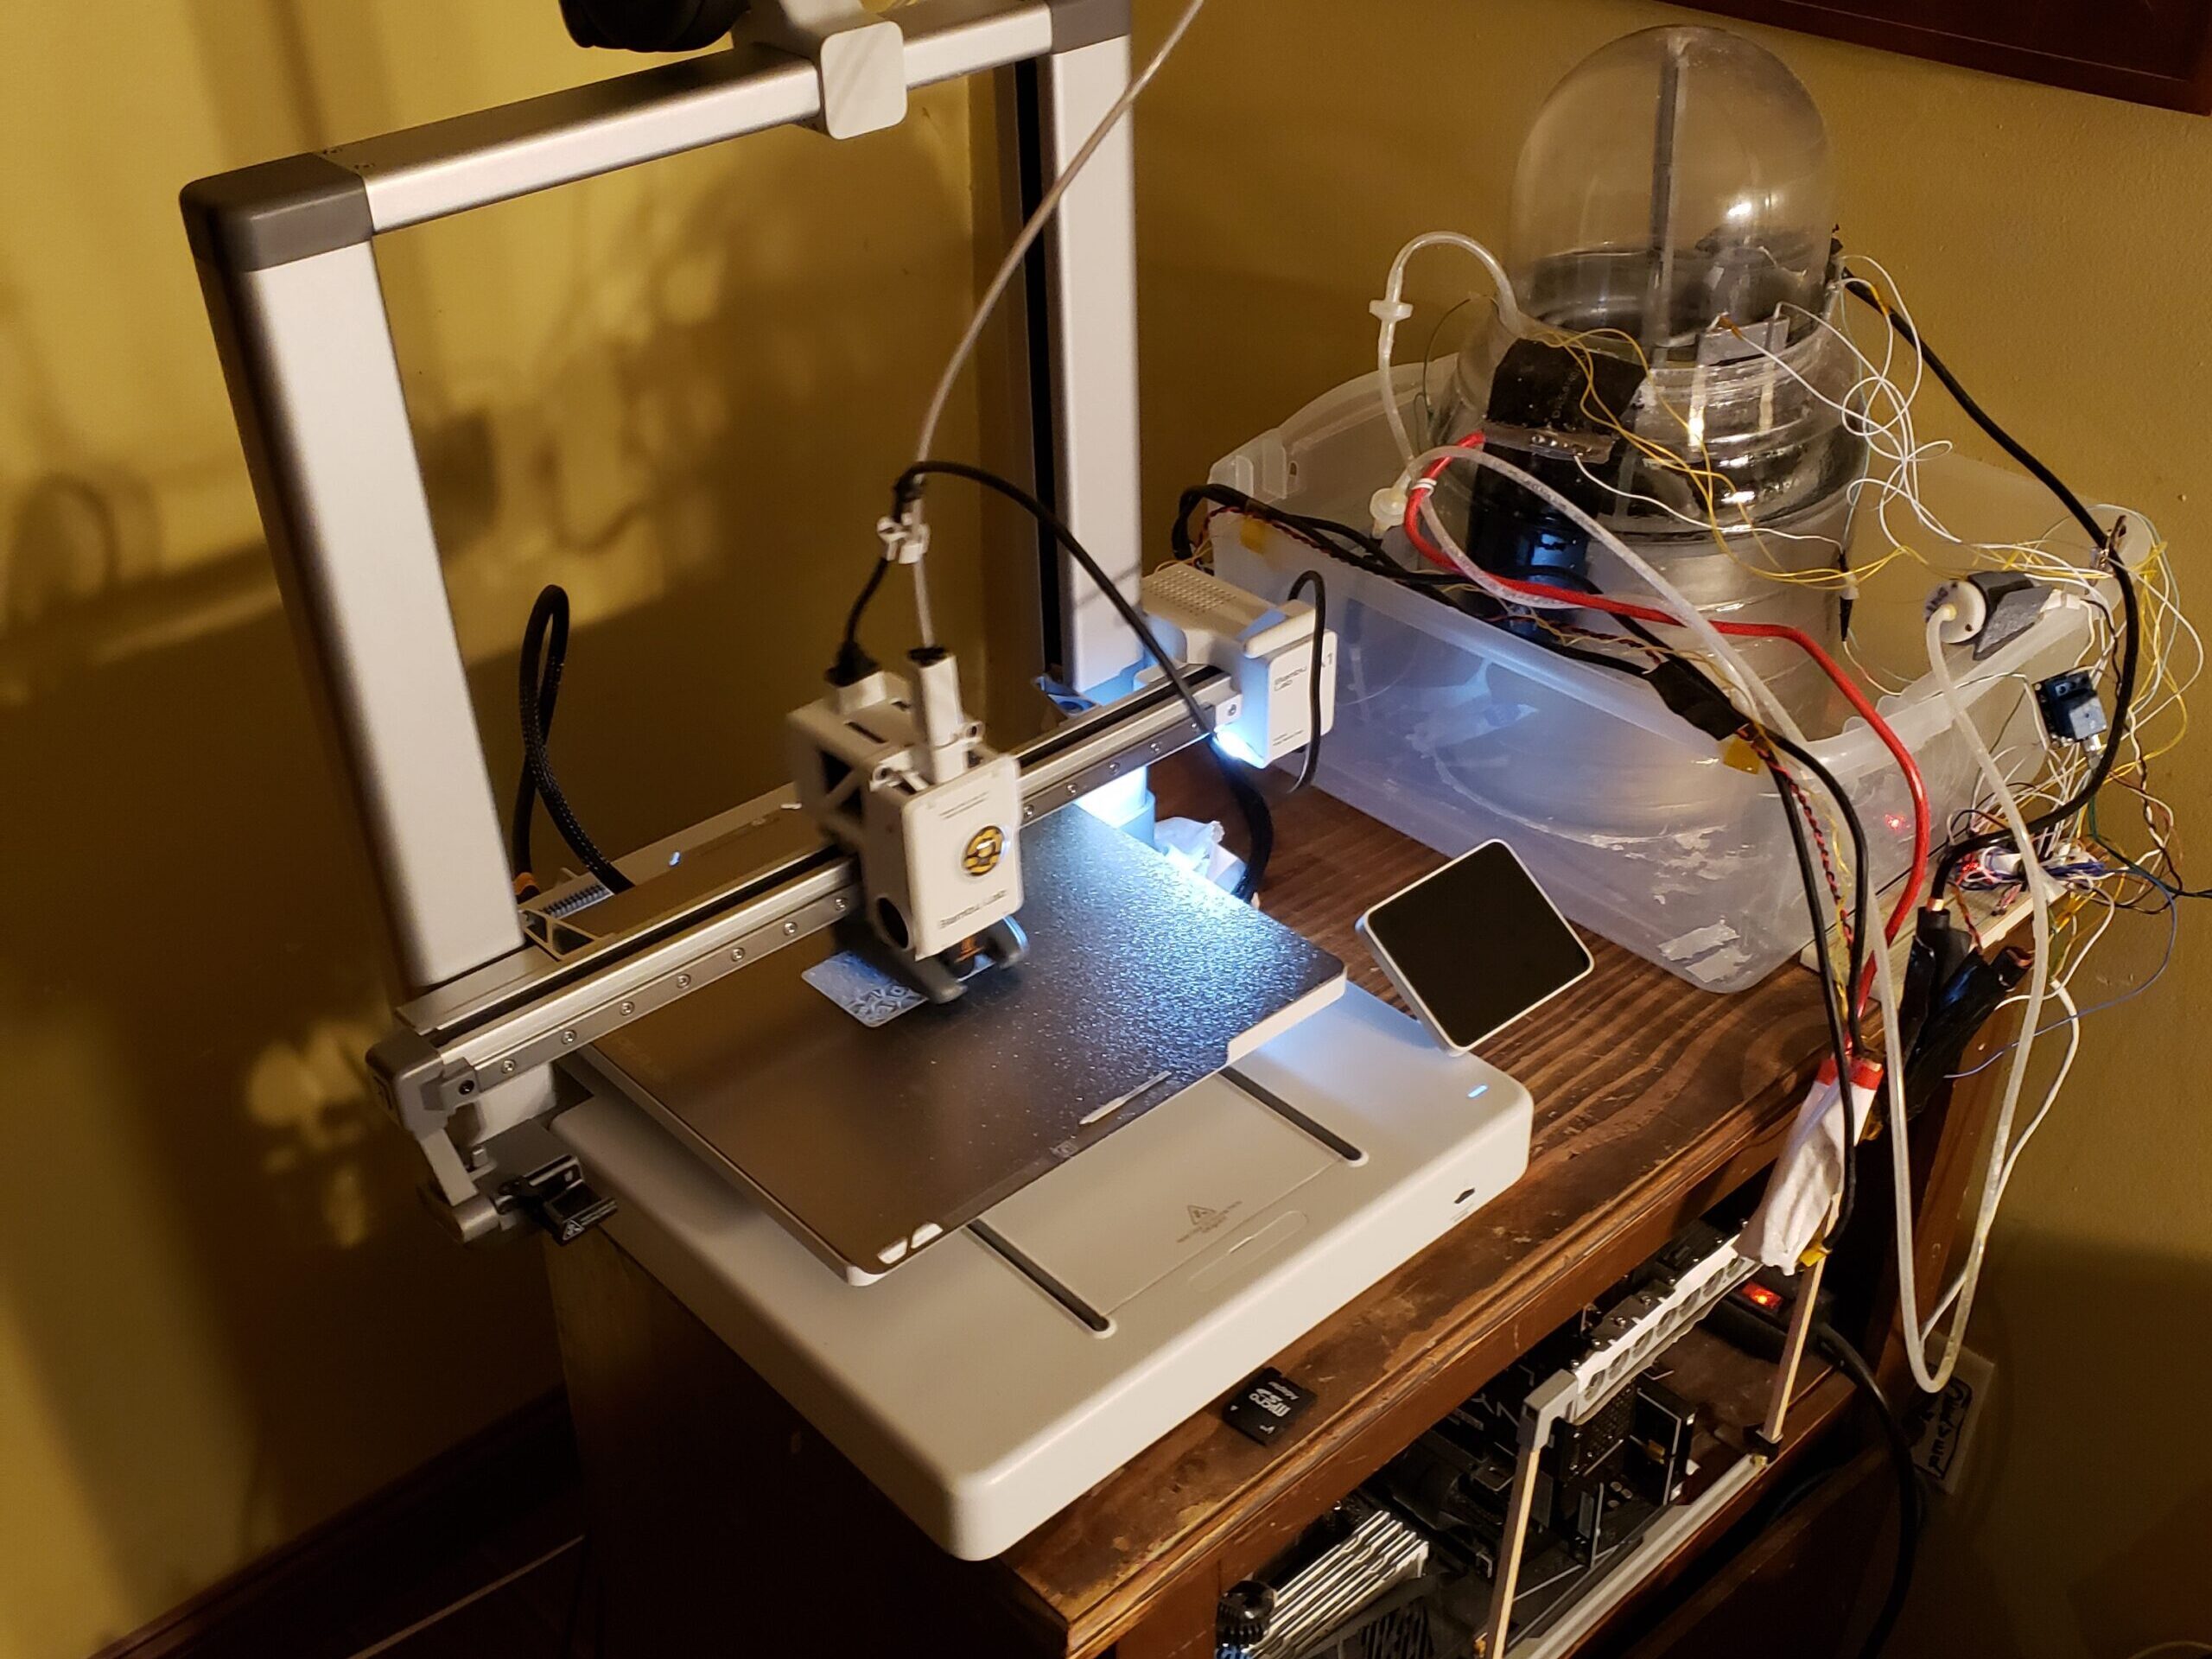
I do feel bad that I haven’t been making much progress on Tv2. Thanksgiving and now finals week have been cutting into my time. I had to spend most of my time this week working on my 1 axis solar tracker using an AT Tiny 13A (picture in the gallery). As soon as finals end I’ll have all the time in the world to design the propeller and build the circuit but for now my hands are tied. I 3d print these cards with a 0.2mm nozzle on my Bambu A1. I color them in with a sharpie to increase the contrast.
This Week's Gallery:
ATtiny solar adjustment
Plans For Next Week:
Survive Finals and then get to work!
Once I get through finals I should have ample time to make some progress but for now things will remain slow. I’m waiting on the circuit to ship but I have a lot of propeller designing to do in the mean time.