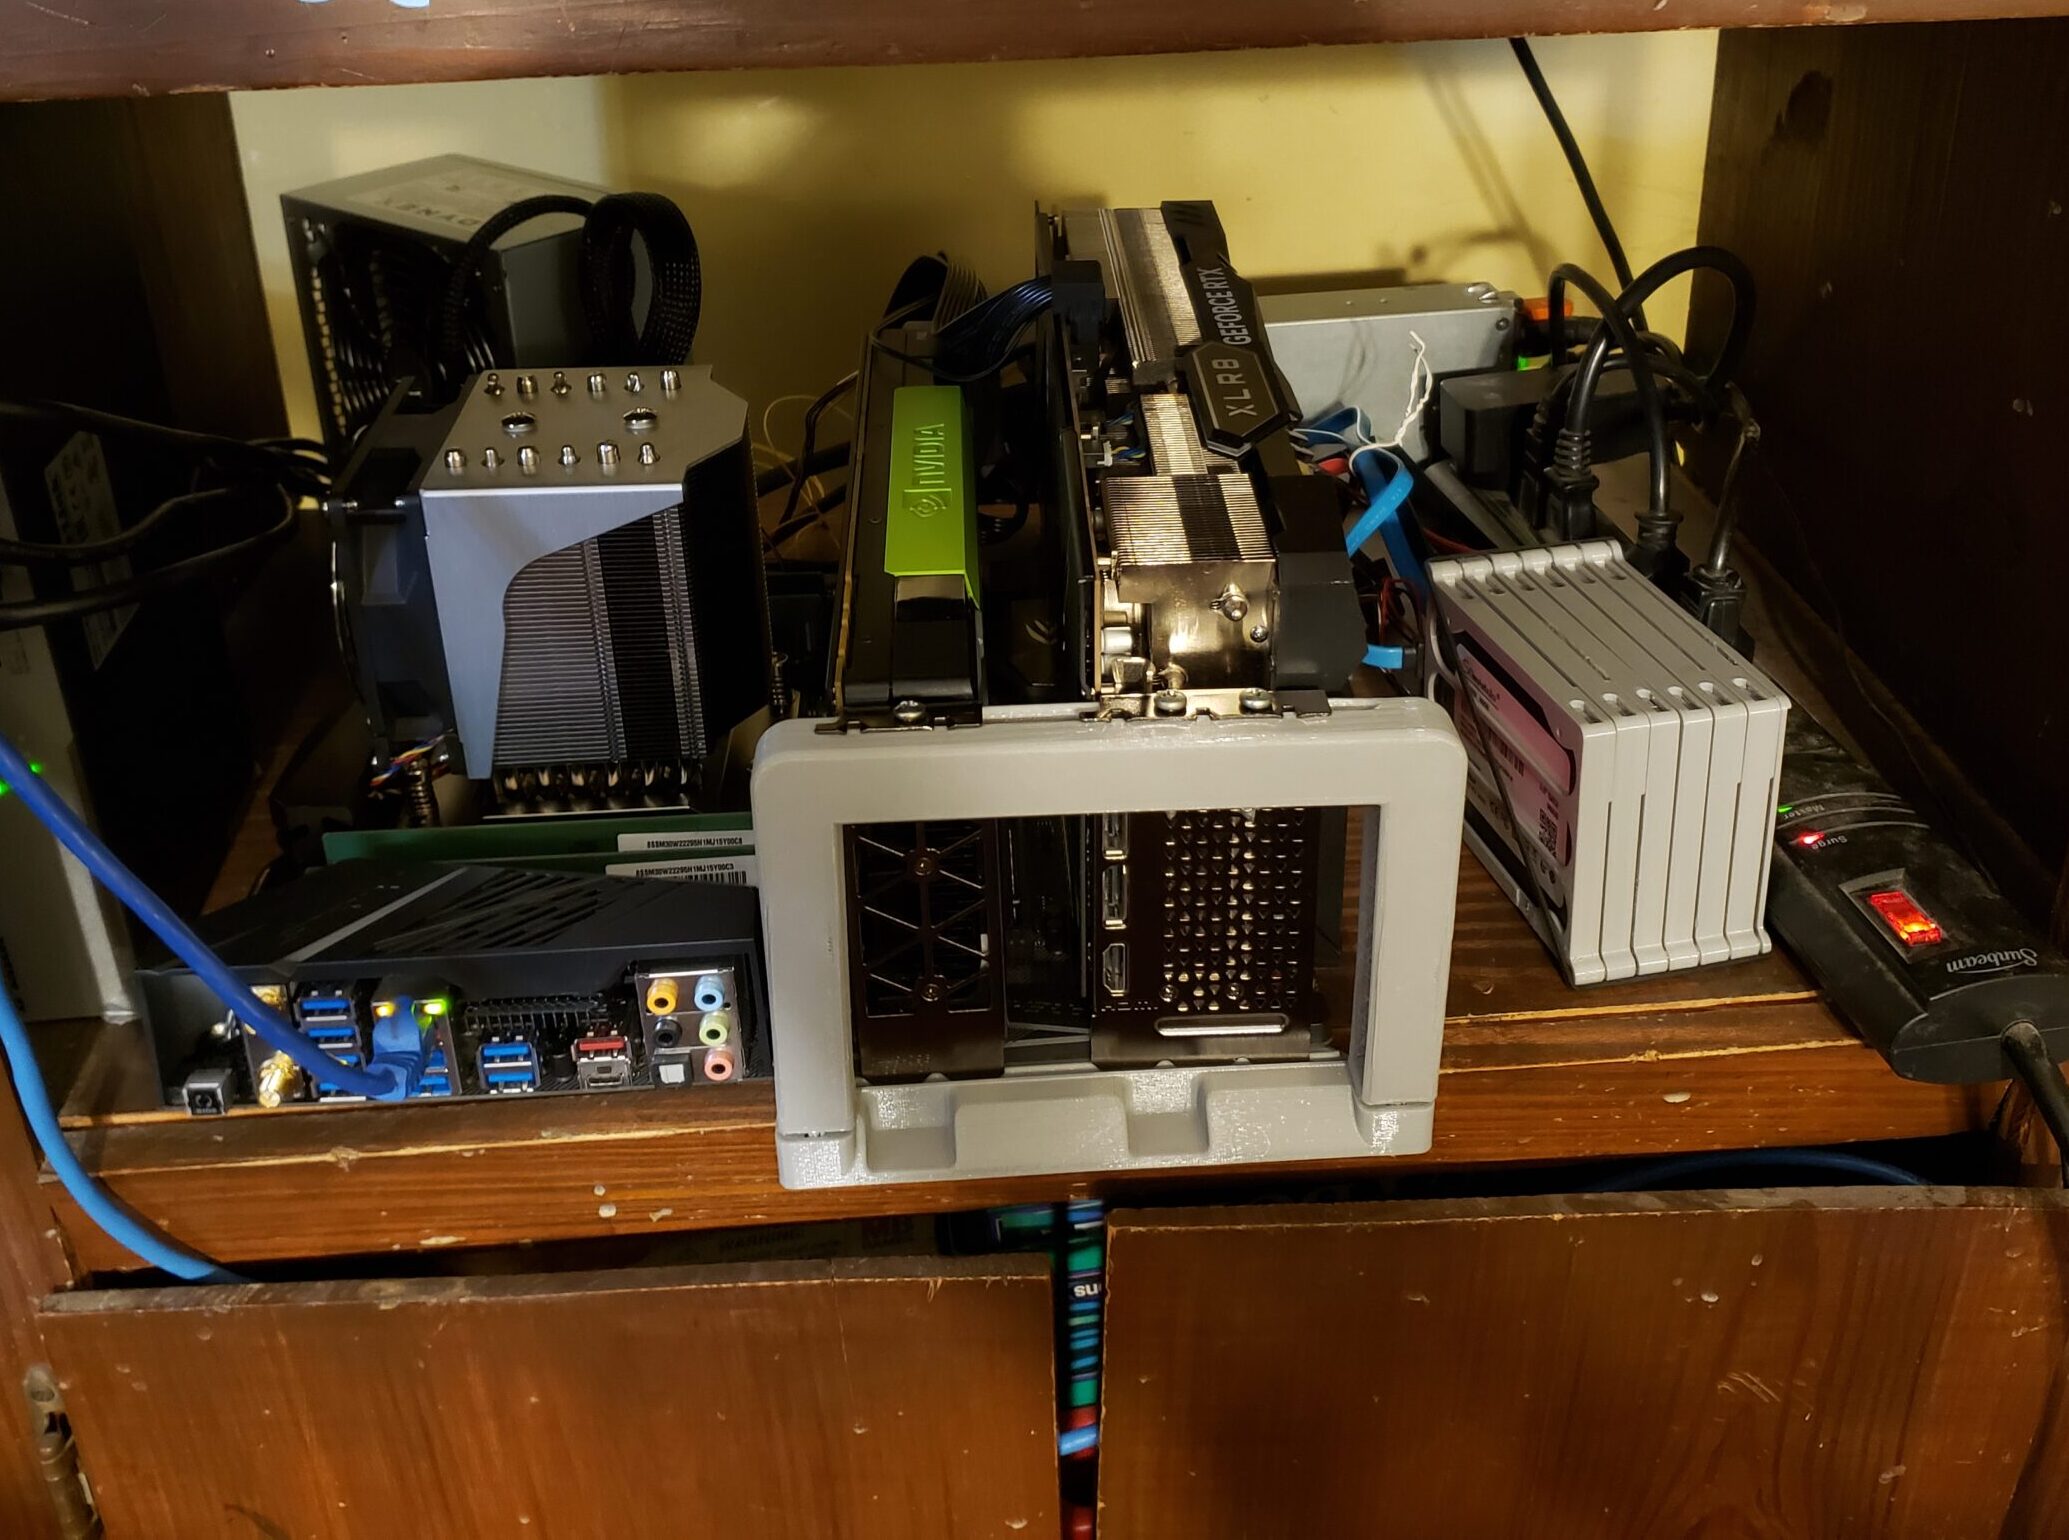
The website was down for most of the week while I got the new server built
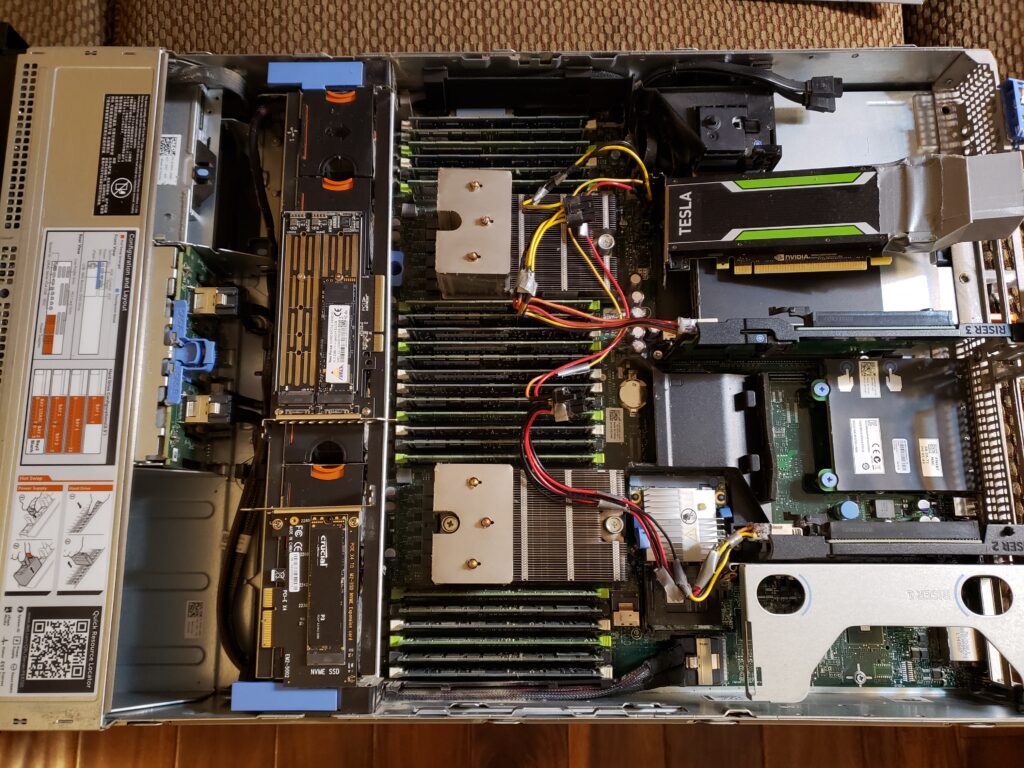
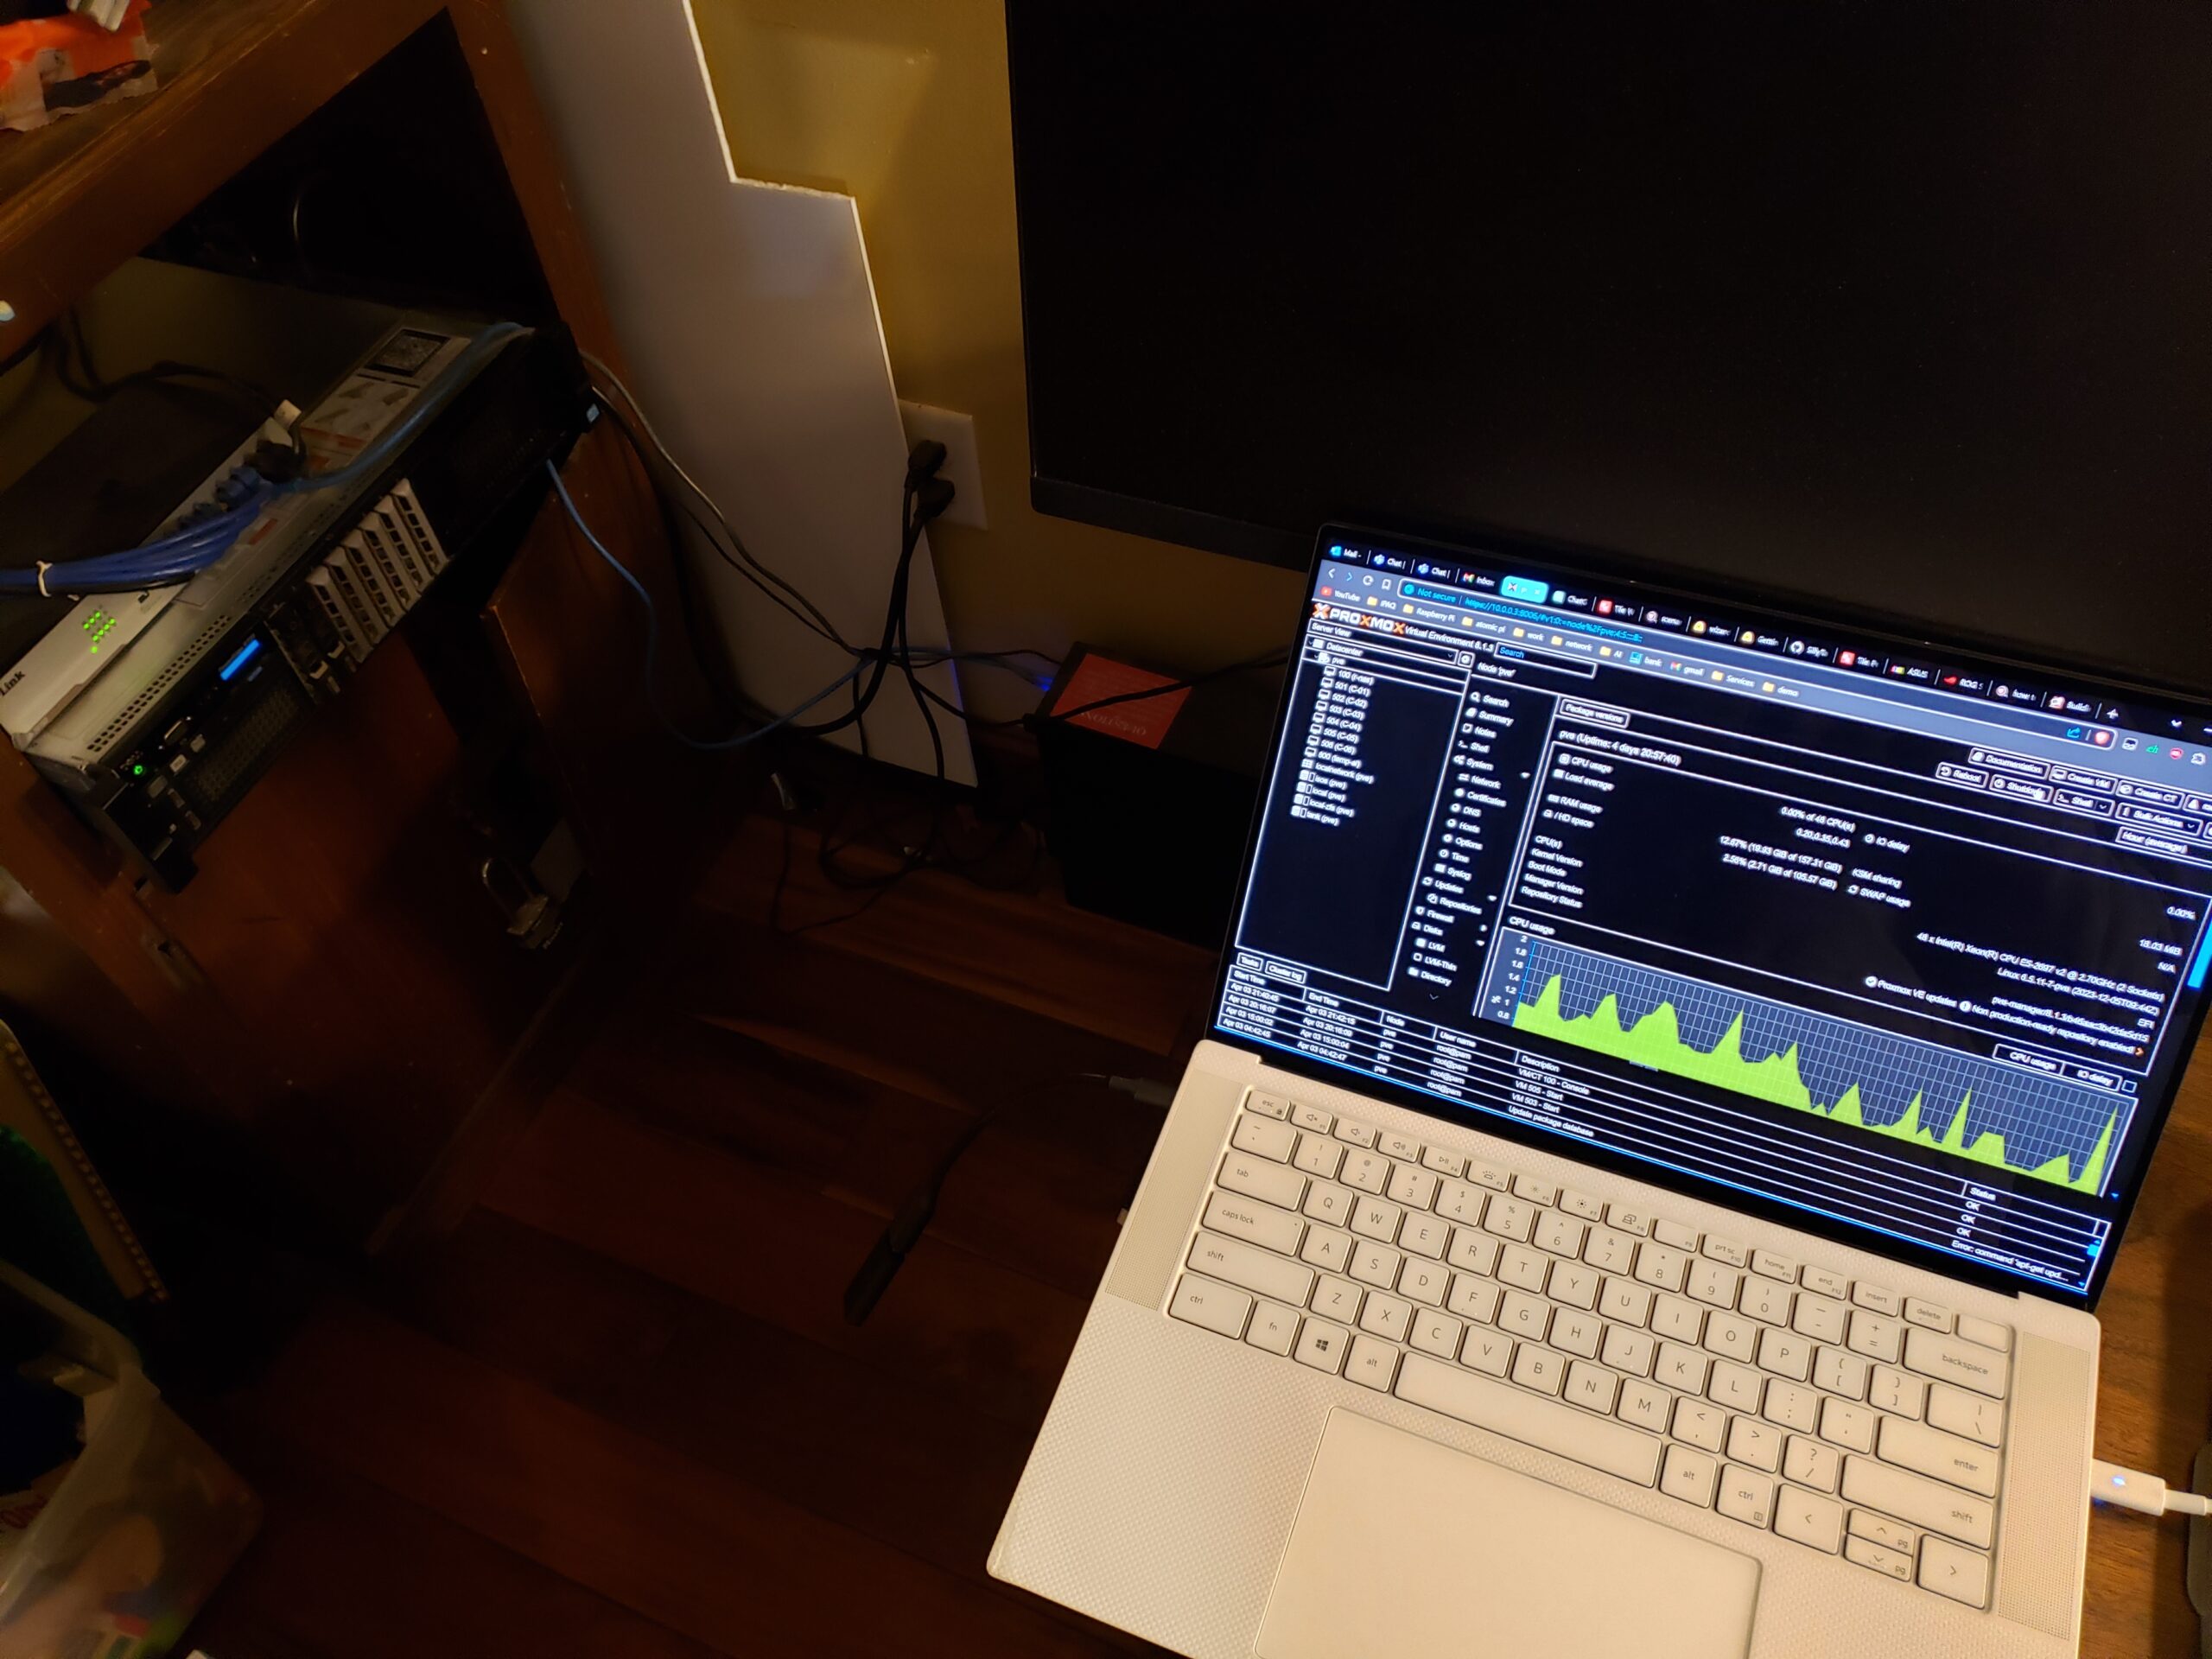
My last server downtime was over spring break and I was able to get it back up that same day. The recent downtime was much longer as I needed to build a whole new server to replace the R720. It was heartbreaking to shutdown that server for the last time.
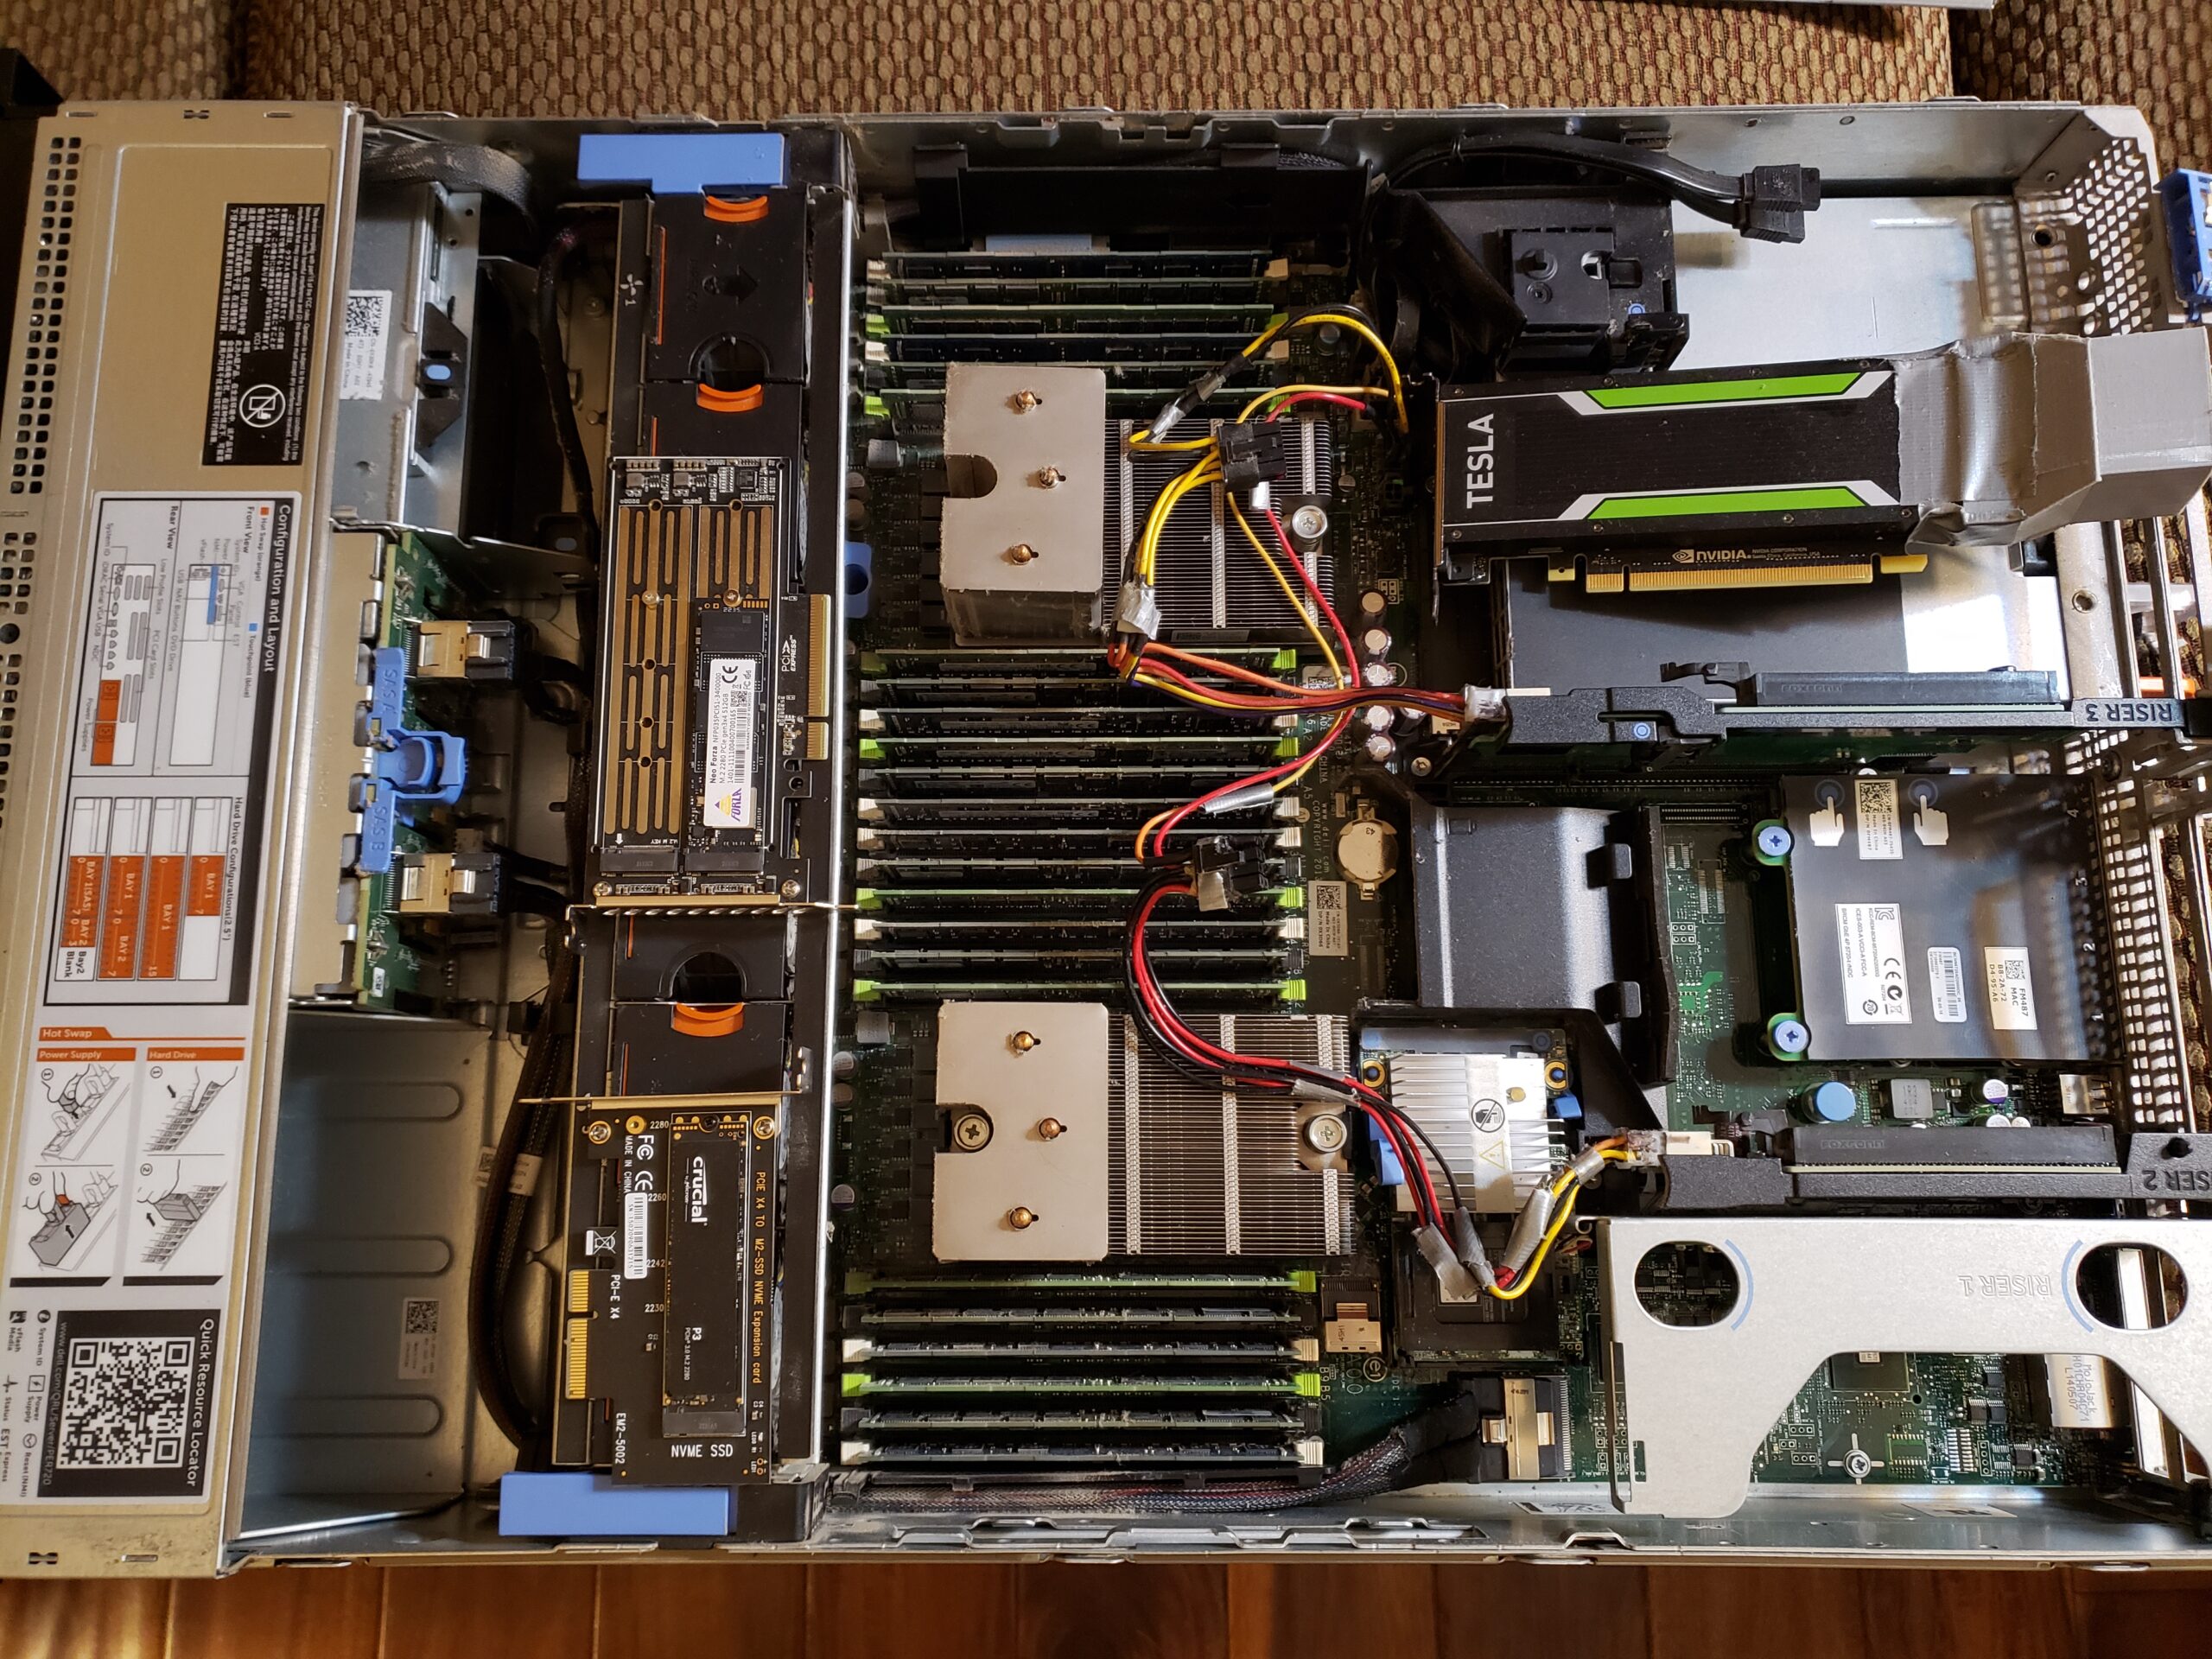
Decommissioning my R720 : (
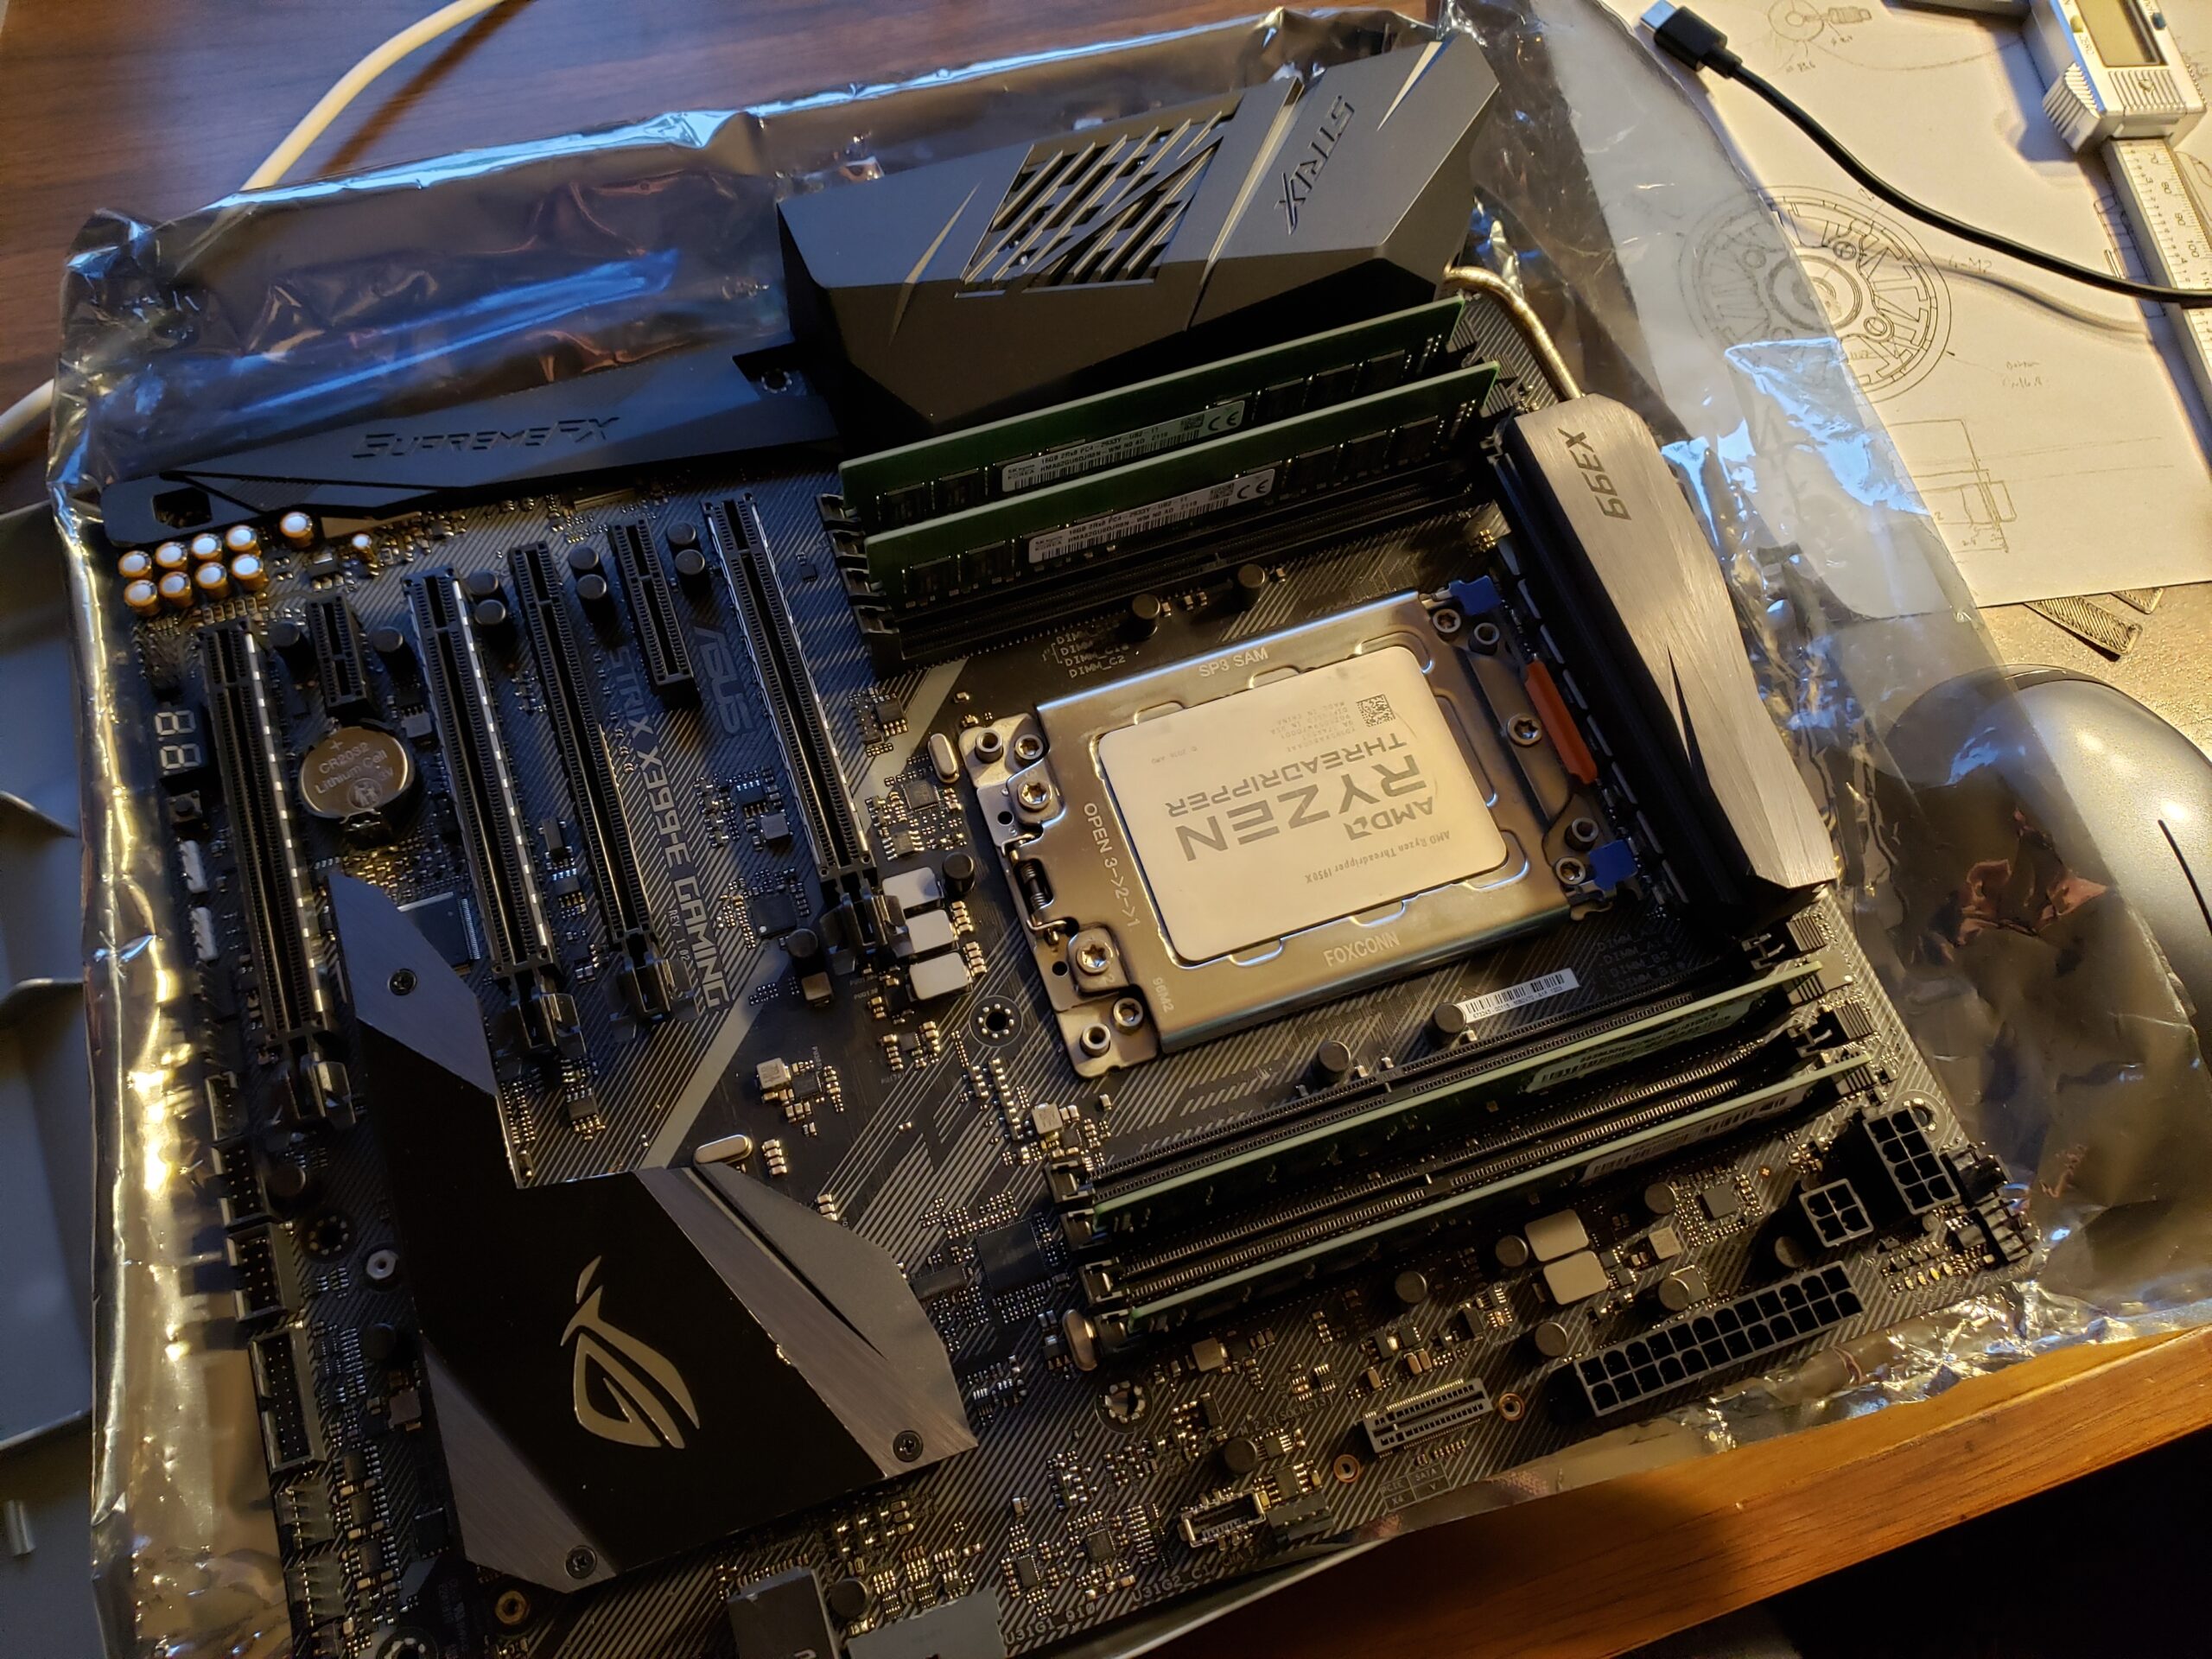
I learned a lot from the R720 but it is time to move on. I did miss the 200W of space heating it provided in the living room. The new server is much faster (and double the price so it better be!). This website is now running on the new hardware so hopefully it feels faster. The Threadripper CPU in my new server has more then enough expandability to replace what the R720 did for me.
All the Power
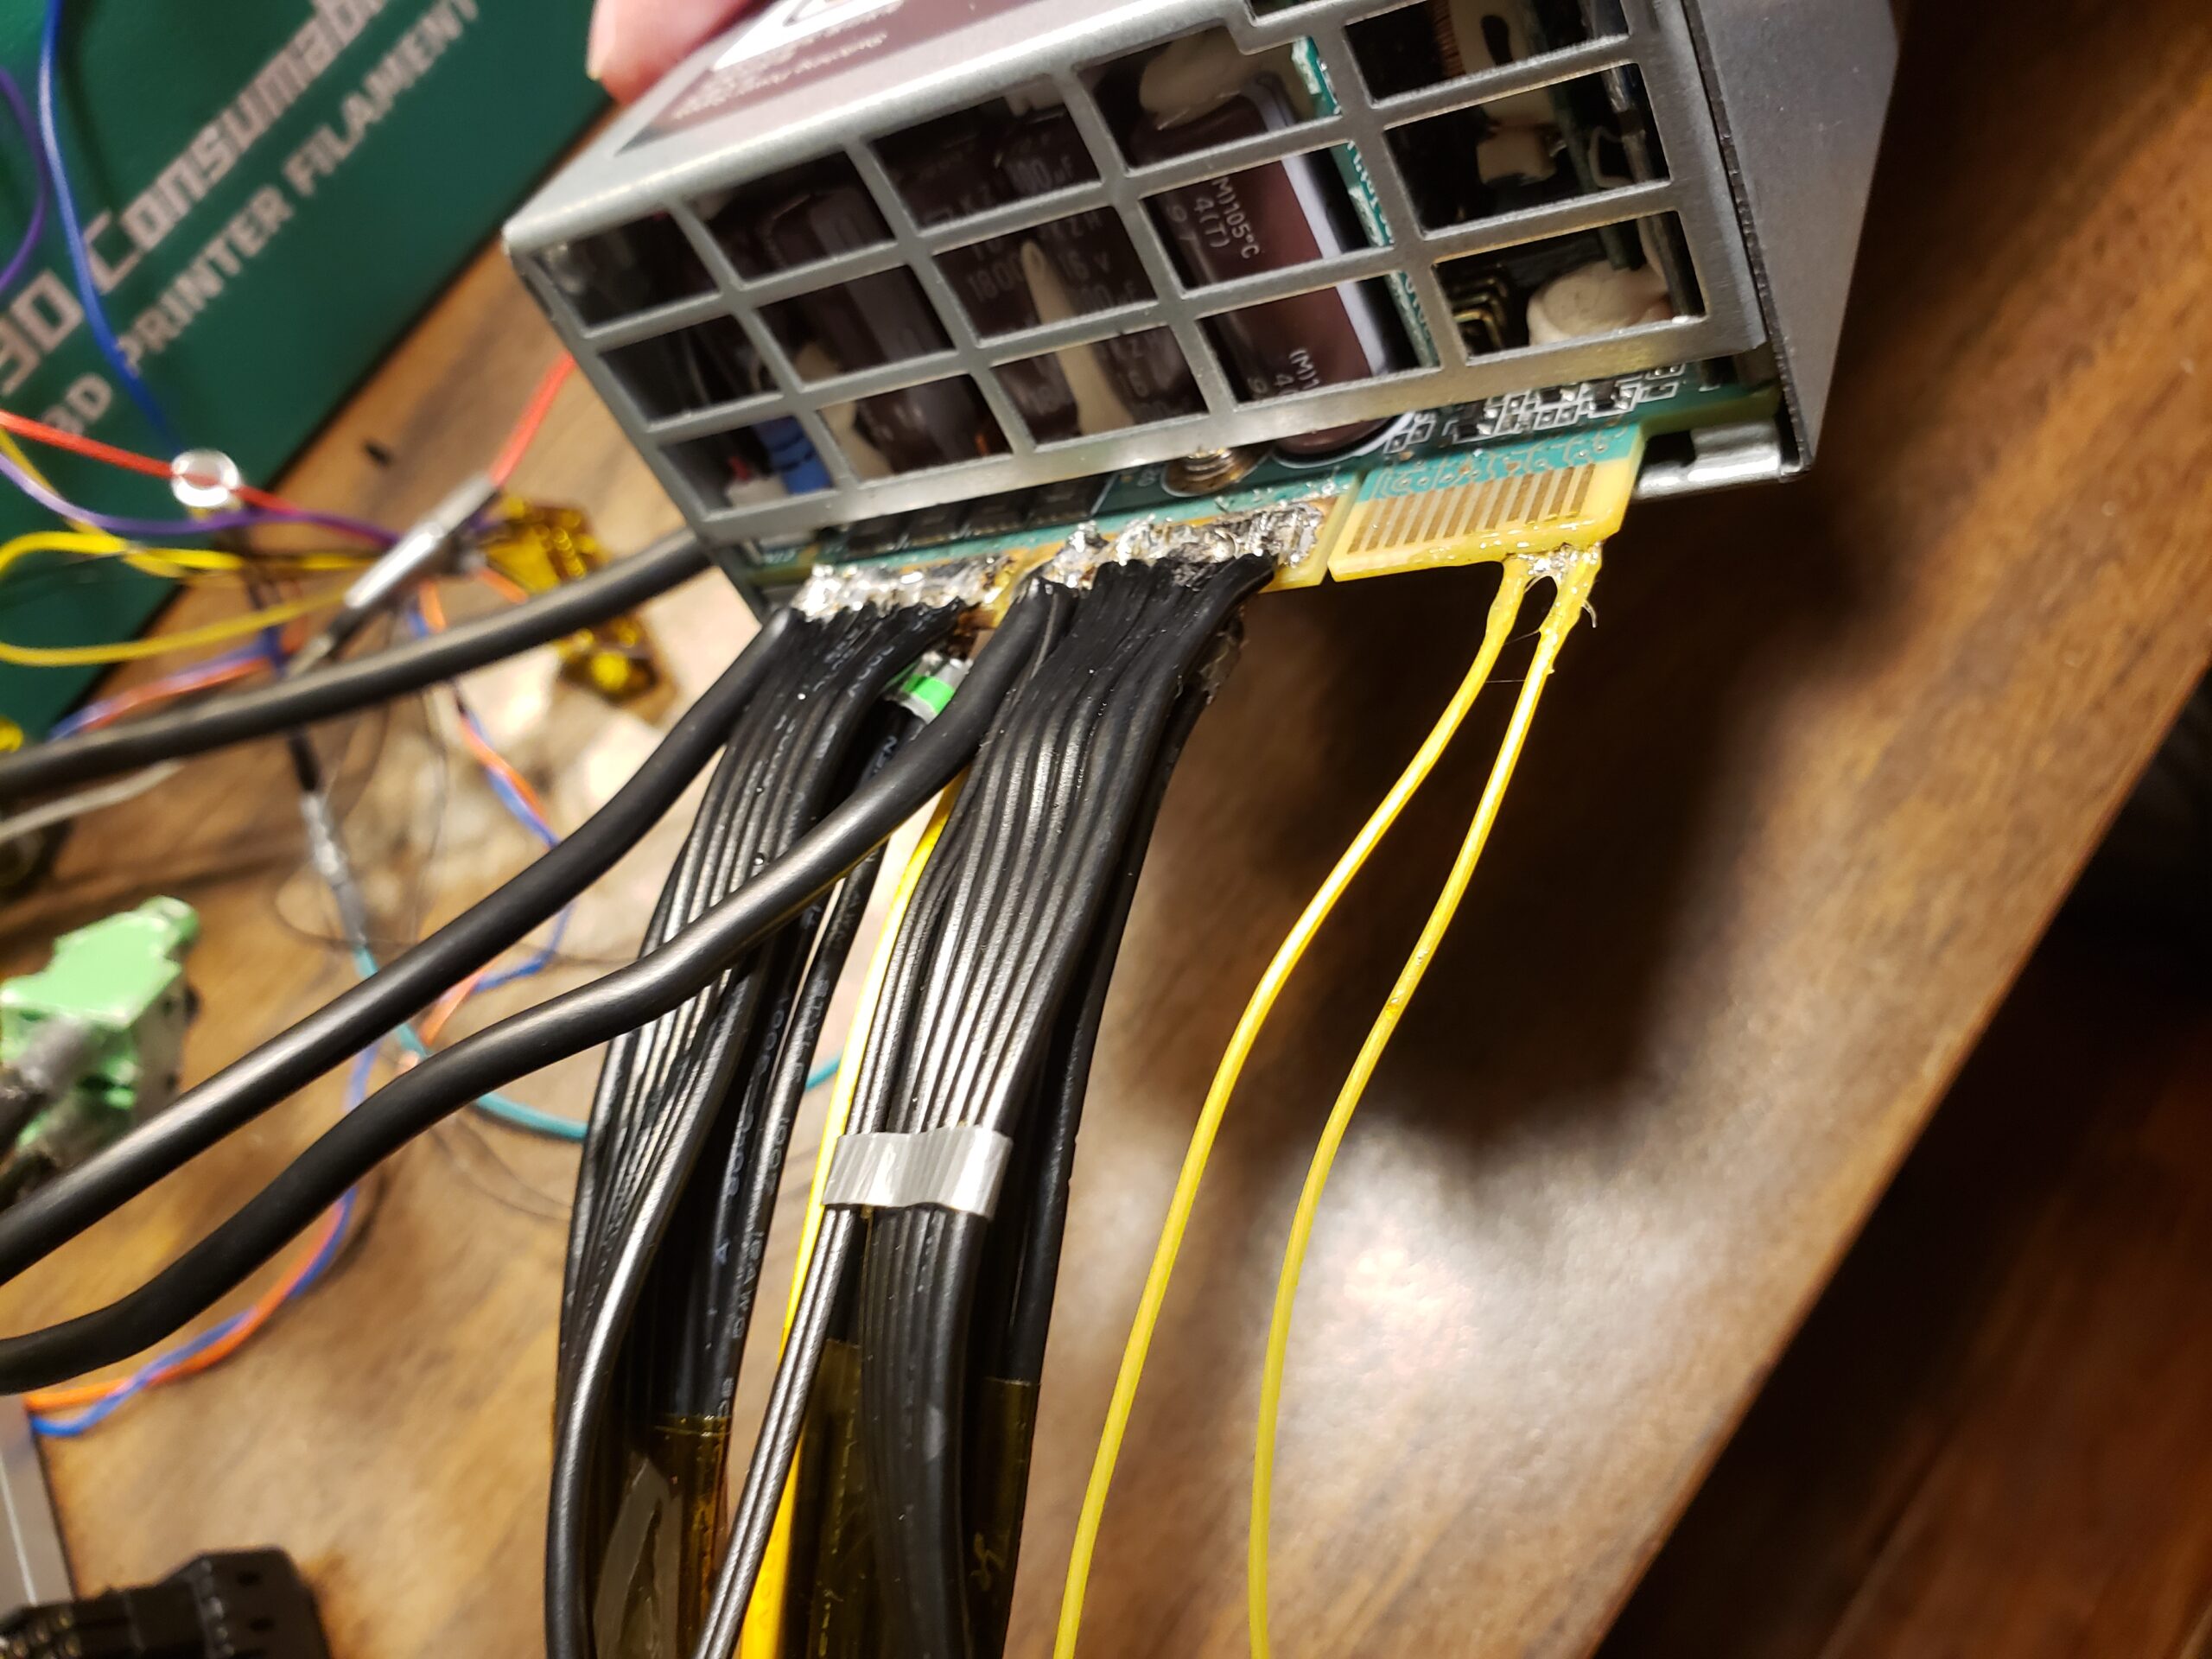
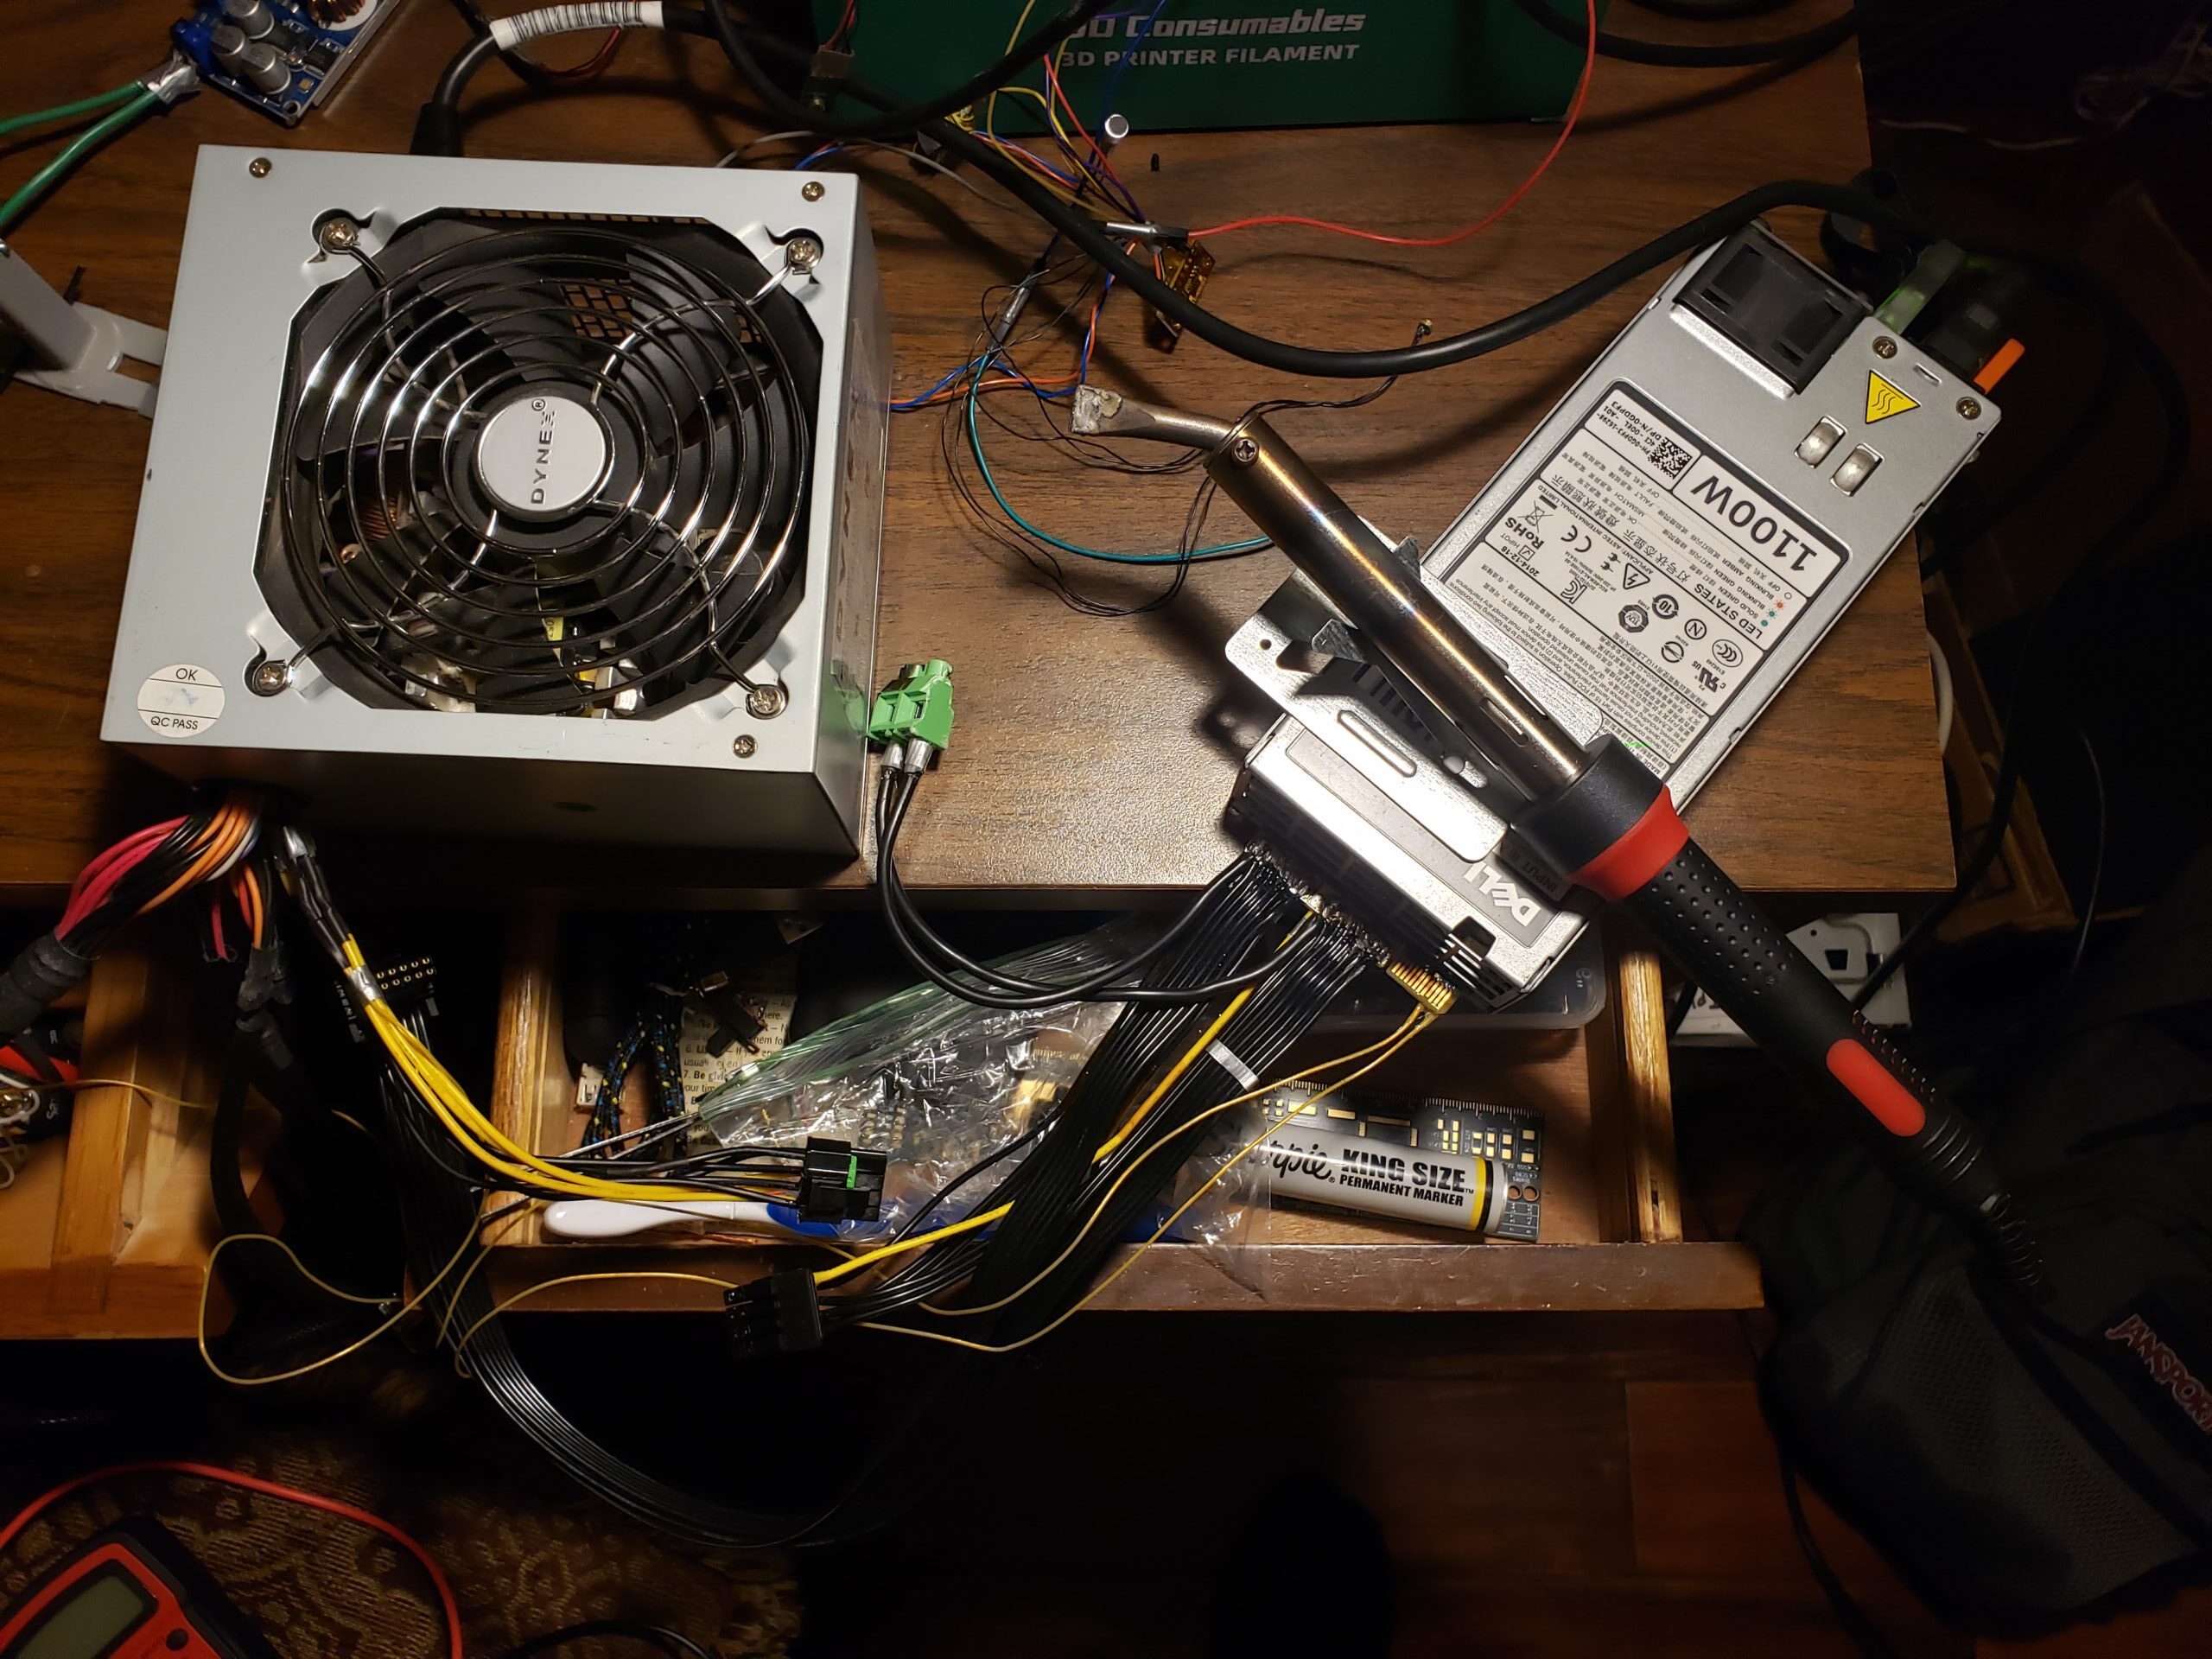
The 100W solder iron made great connections a breeze
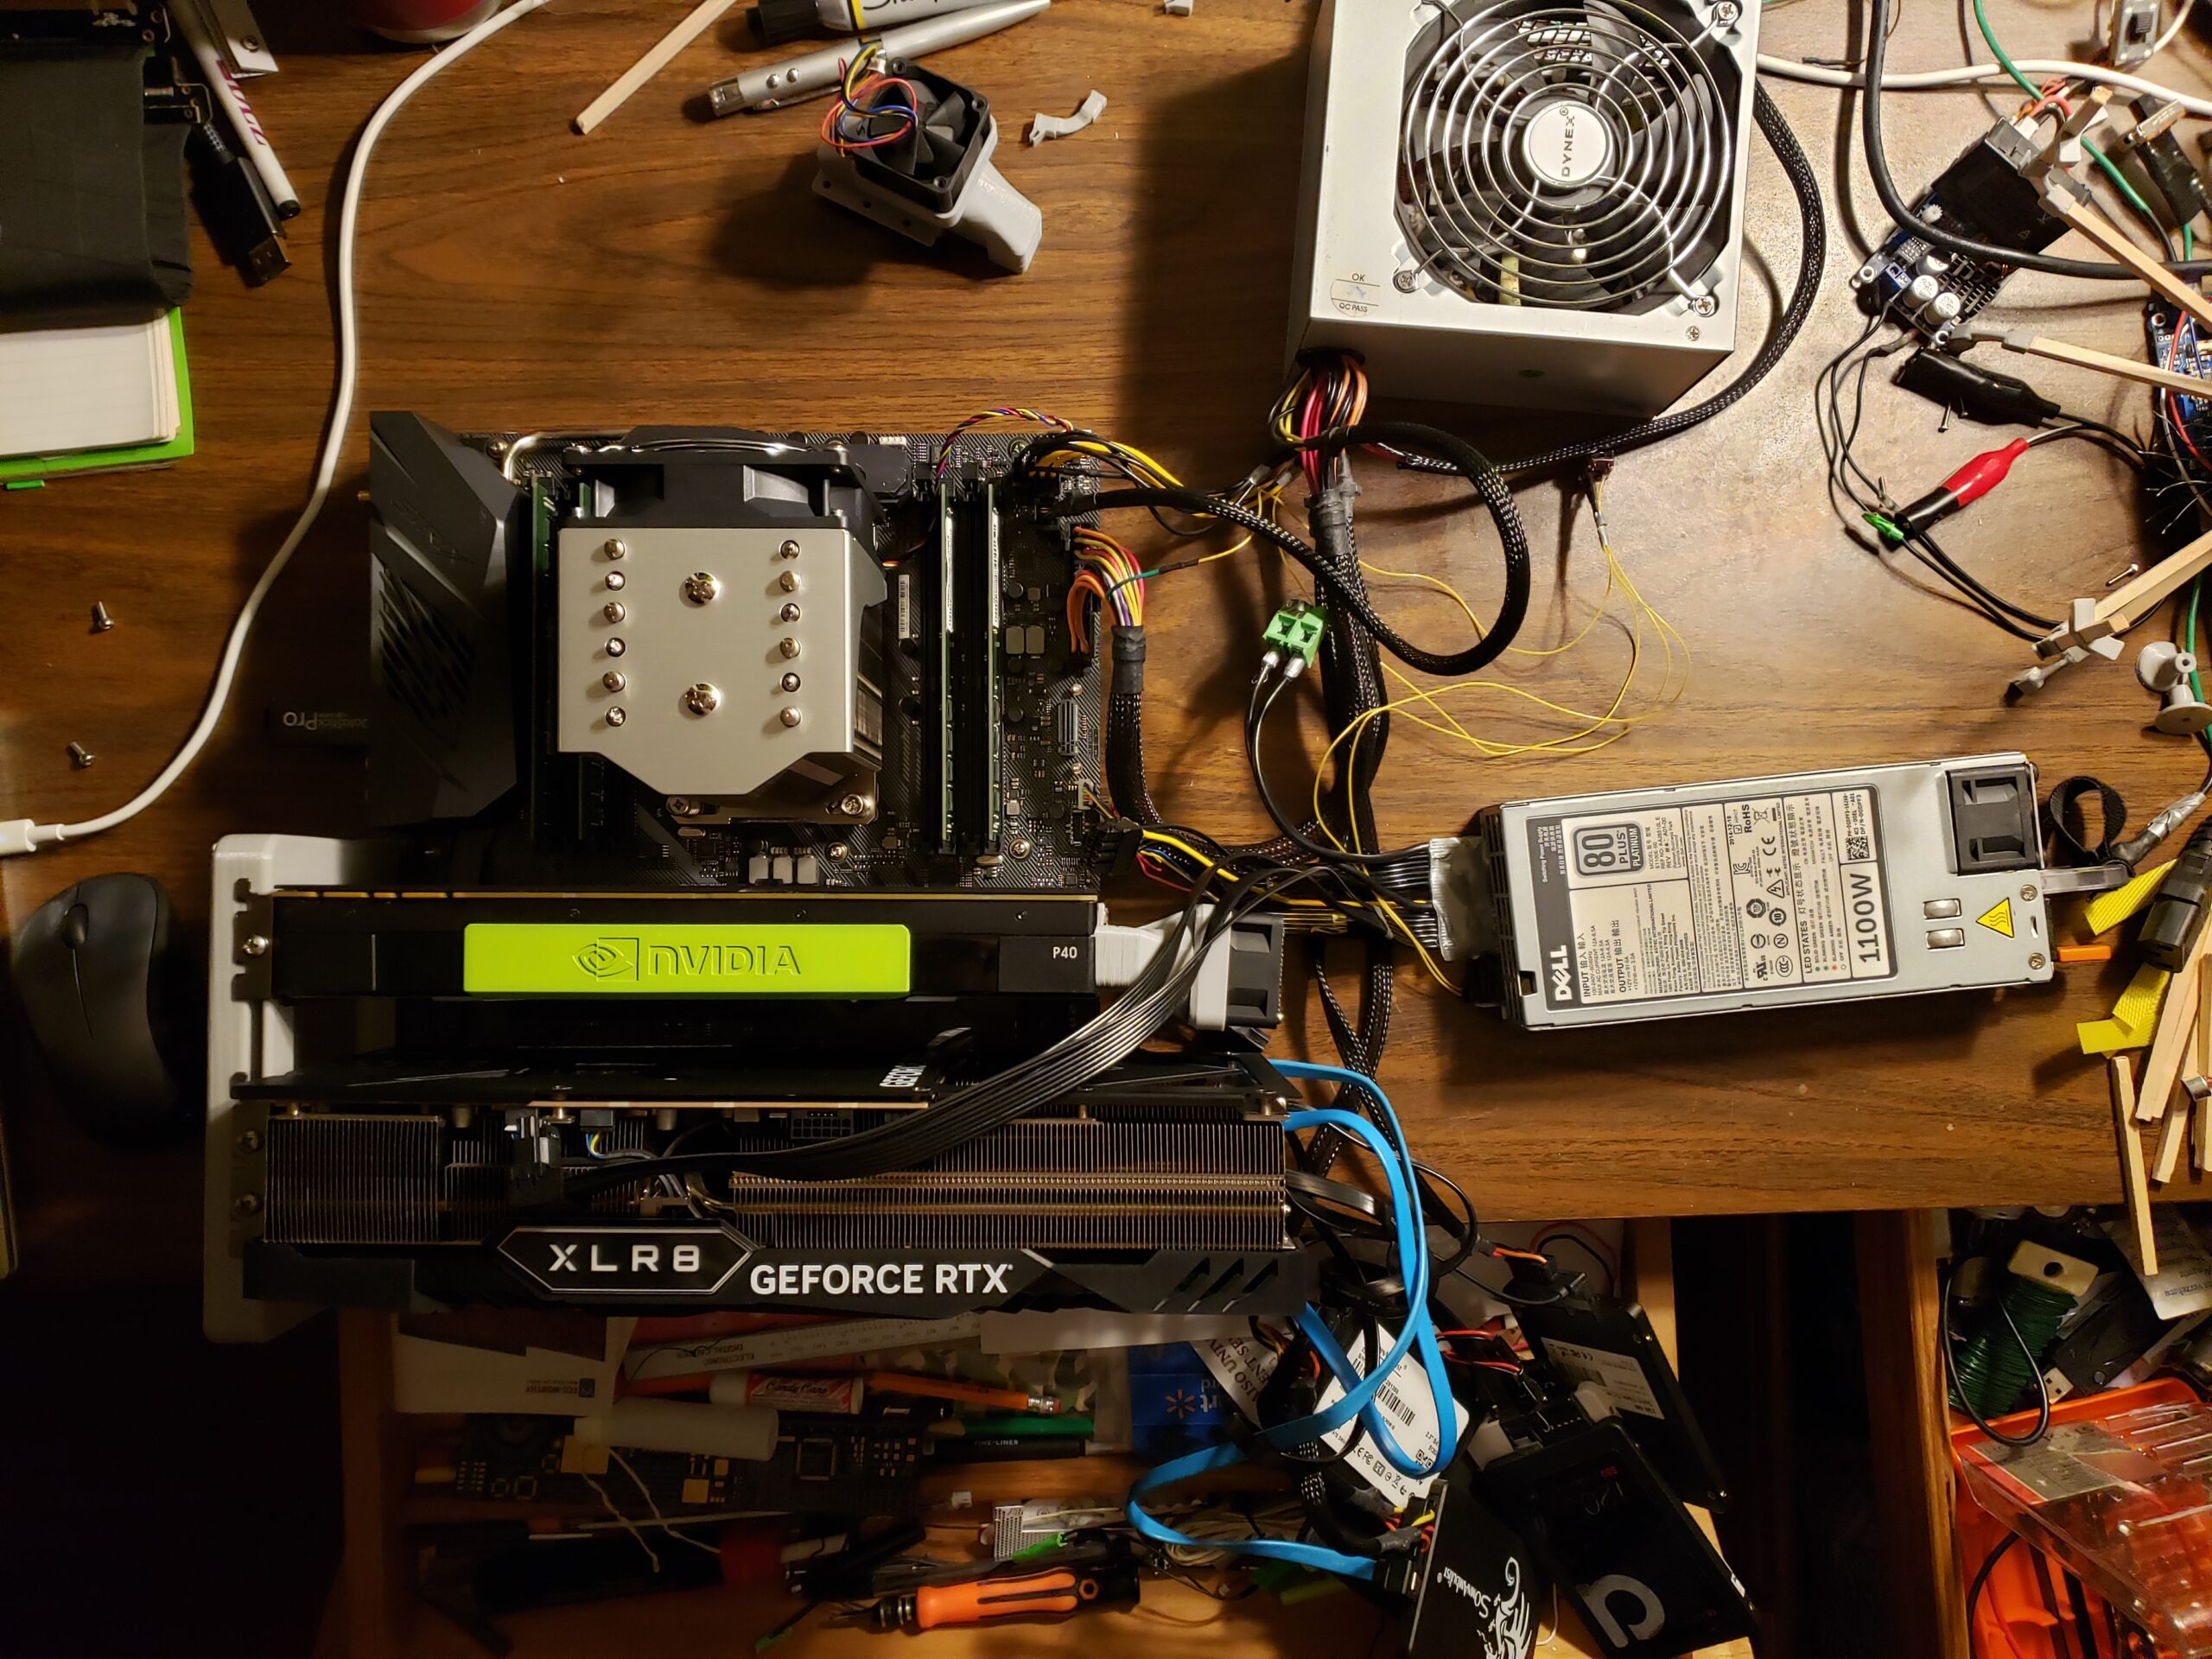
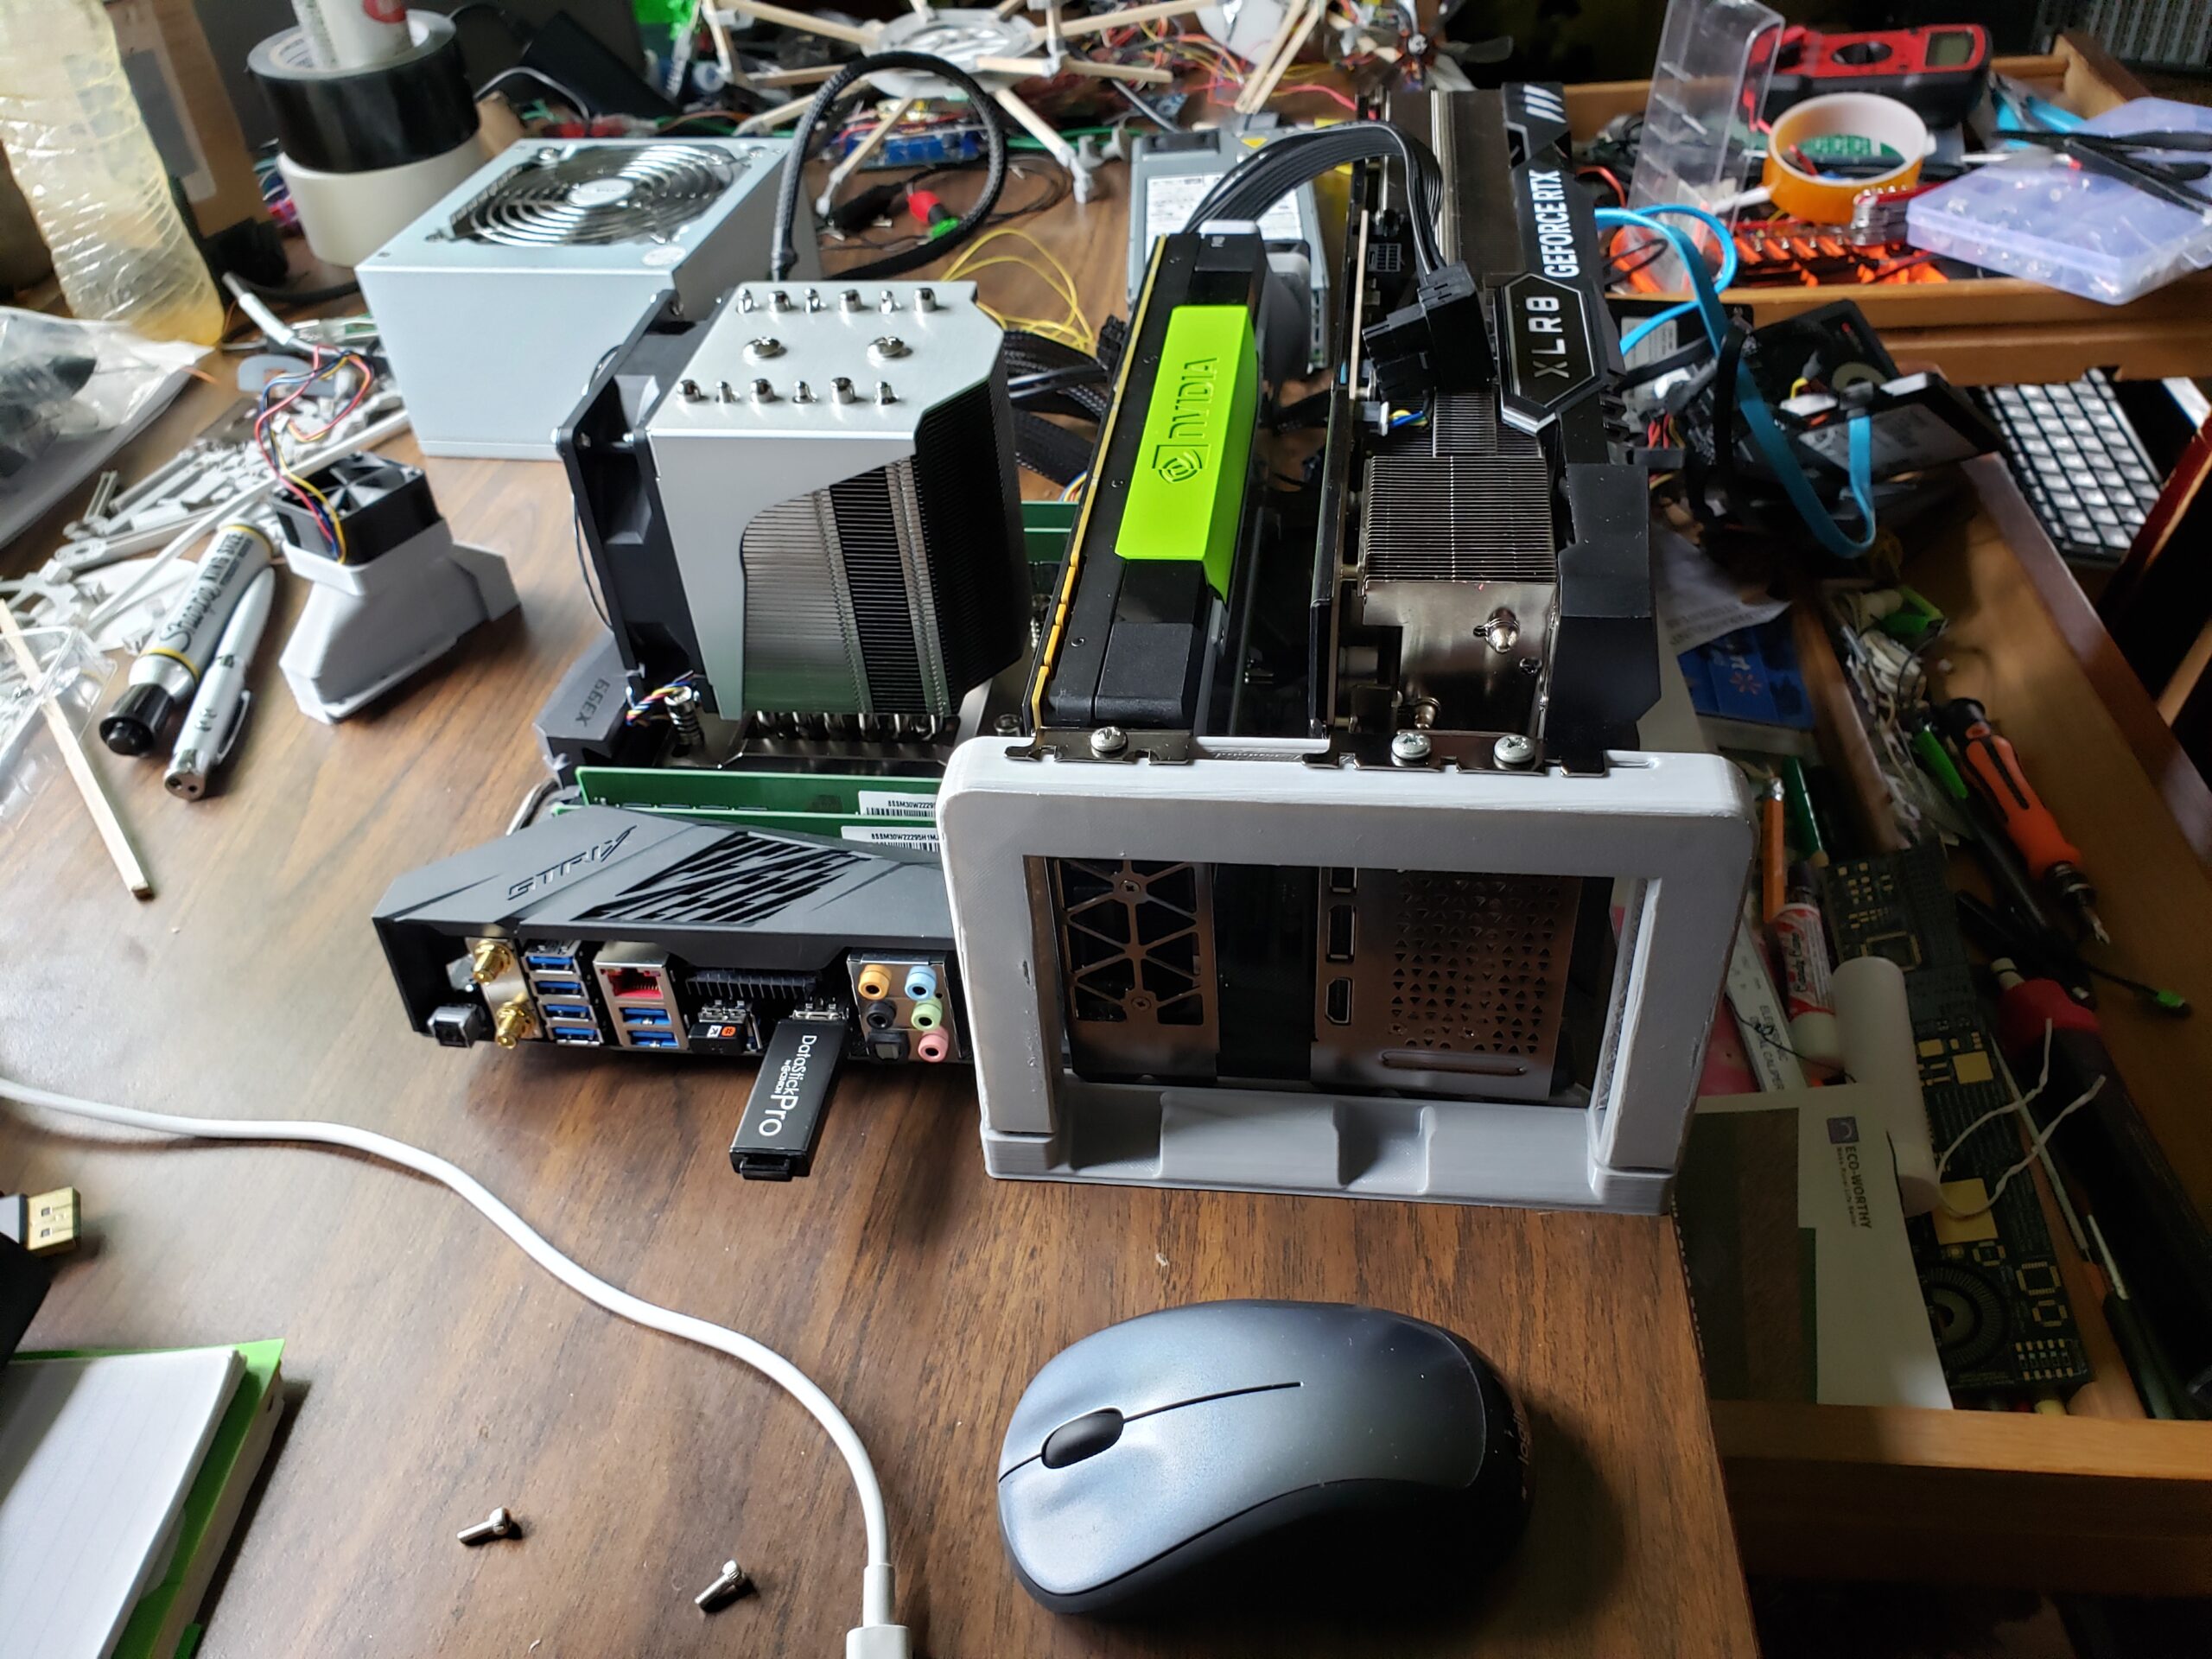
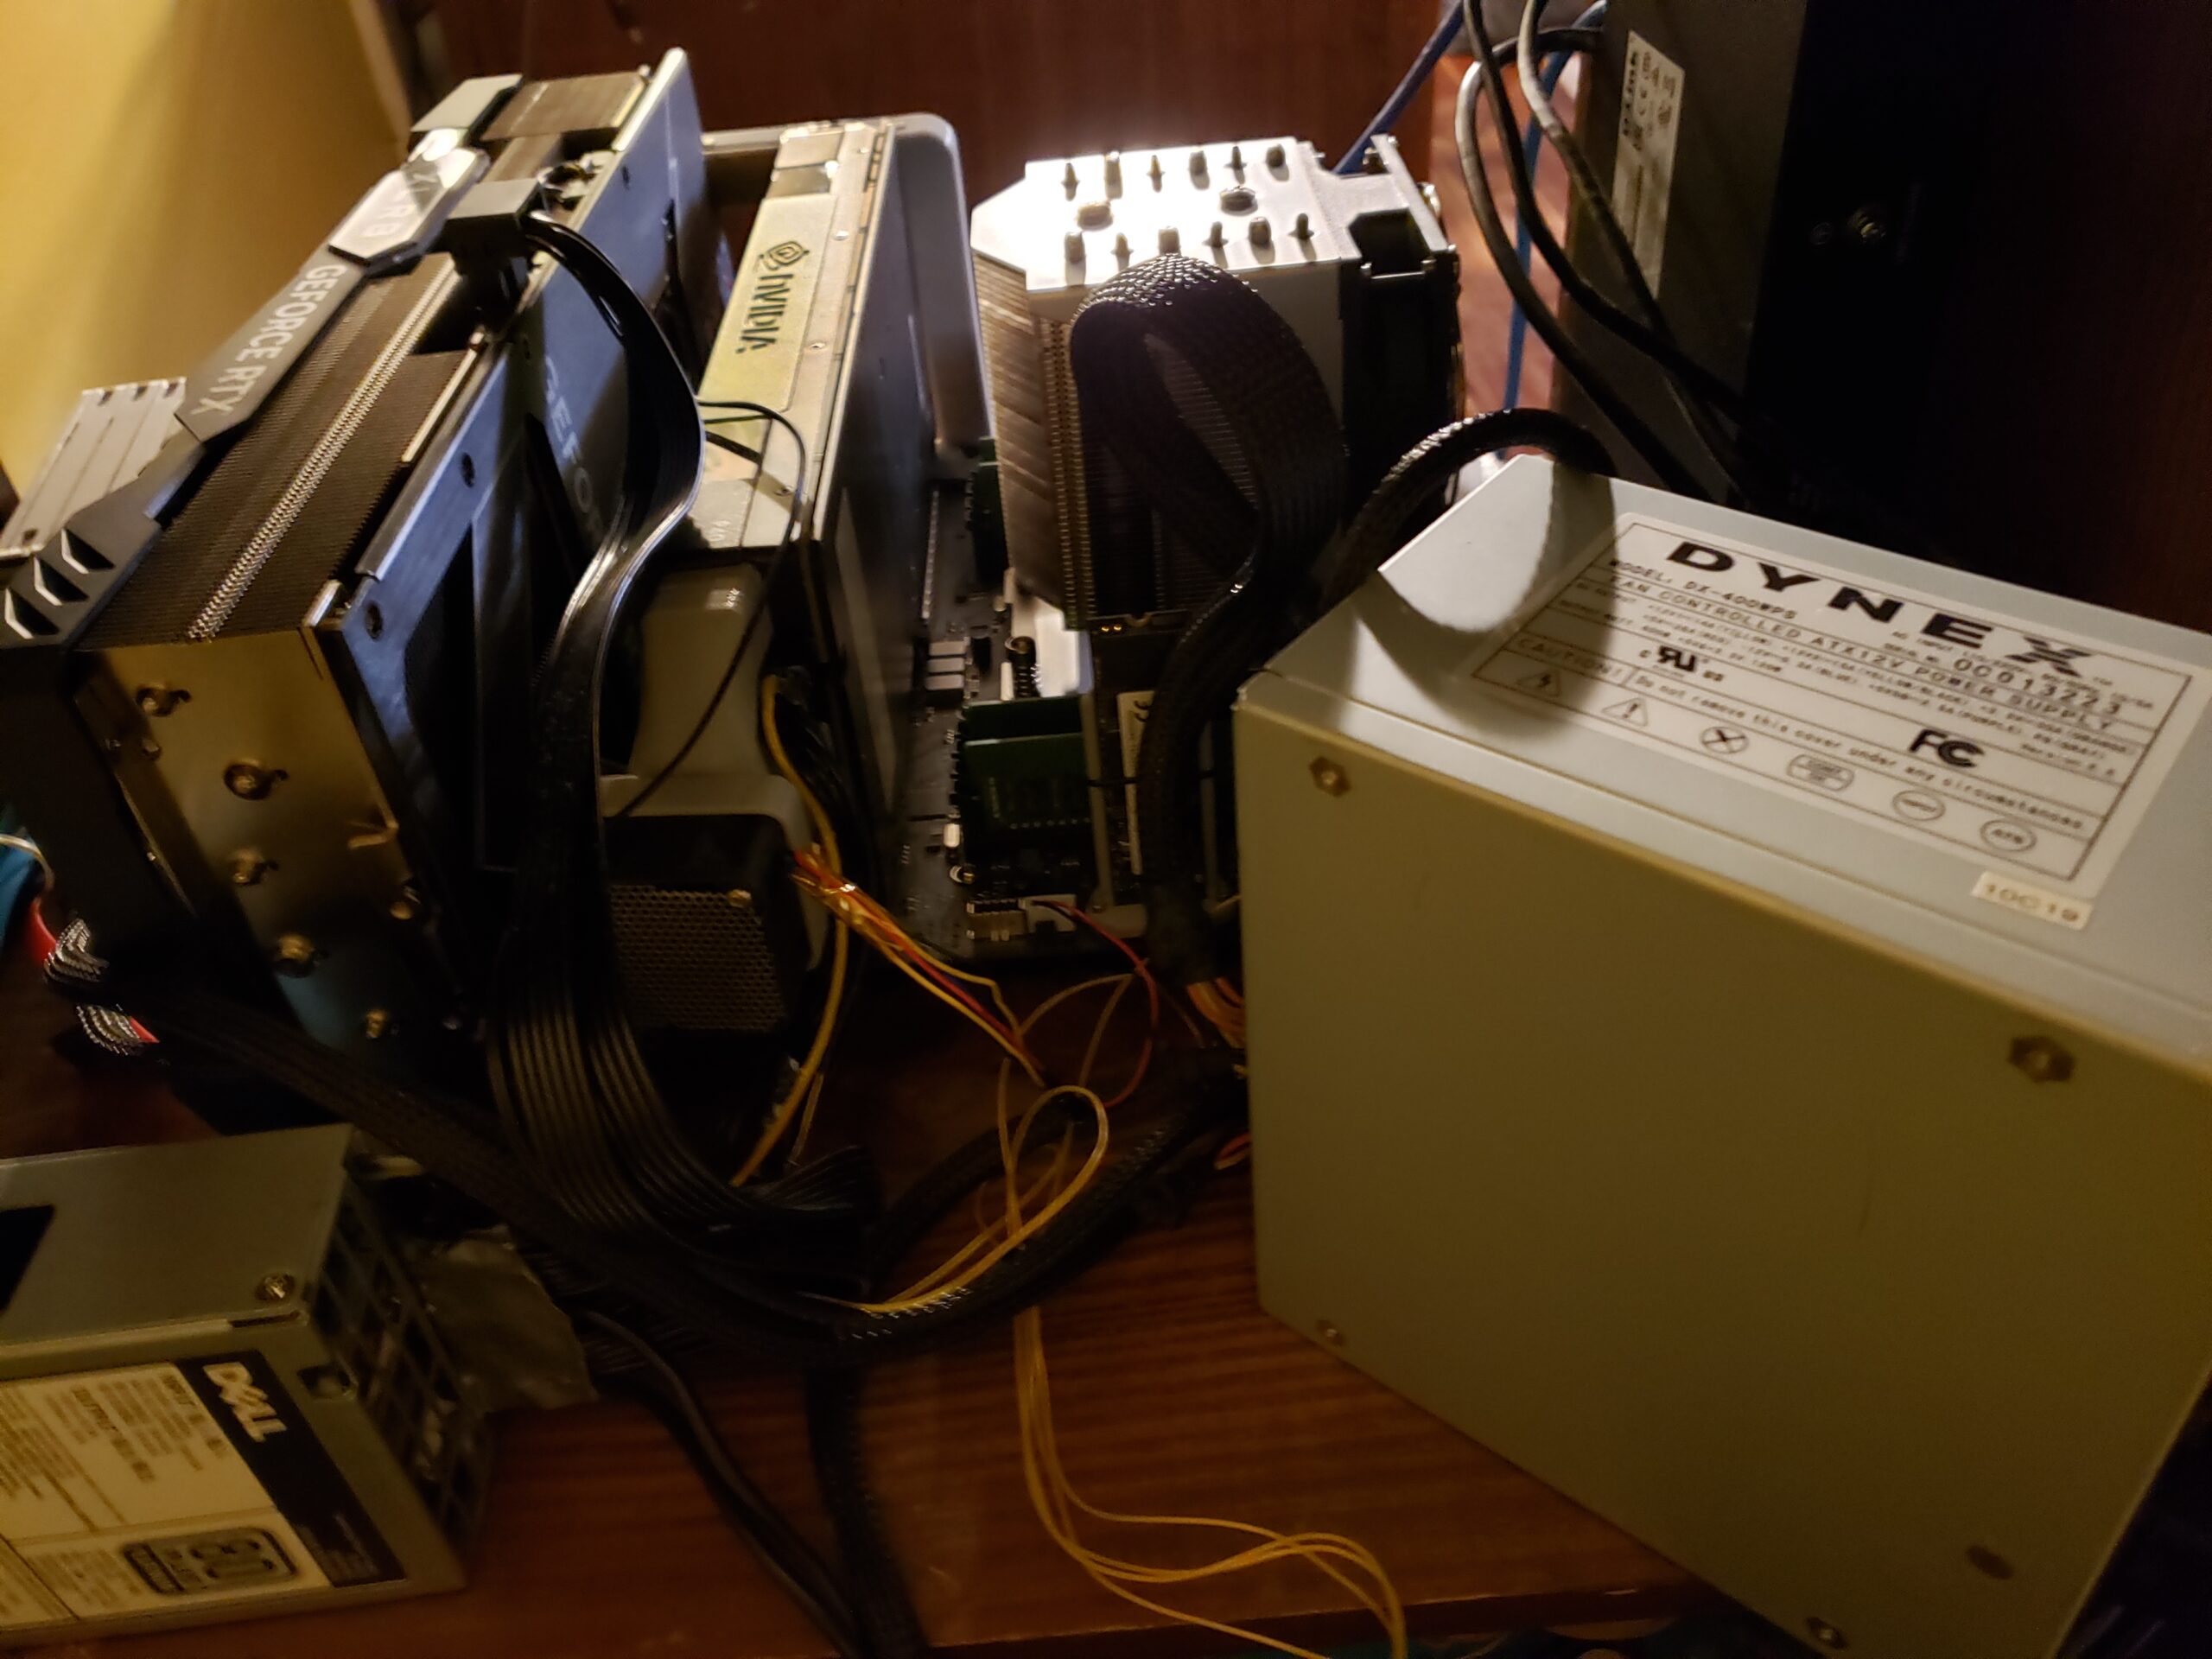
This power supply is rated for 1100W but I’ll be using 820W at max. That is still a lot of power so I made sure to use plenty of solder on the wires. This is currently powering the 4080 and one of the P40s. I want to get the second P40 in there at some point but I couldn’t get it to fit in this initial build. I ordered some short PCIe risers and I’m going to put all three GPUs on a rack above the motherboard to fit everything properly.
I couldn't fit the last P40 in this build but it was going to be for VDI so I can leave it out for the demo
Server Power Up Reaction
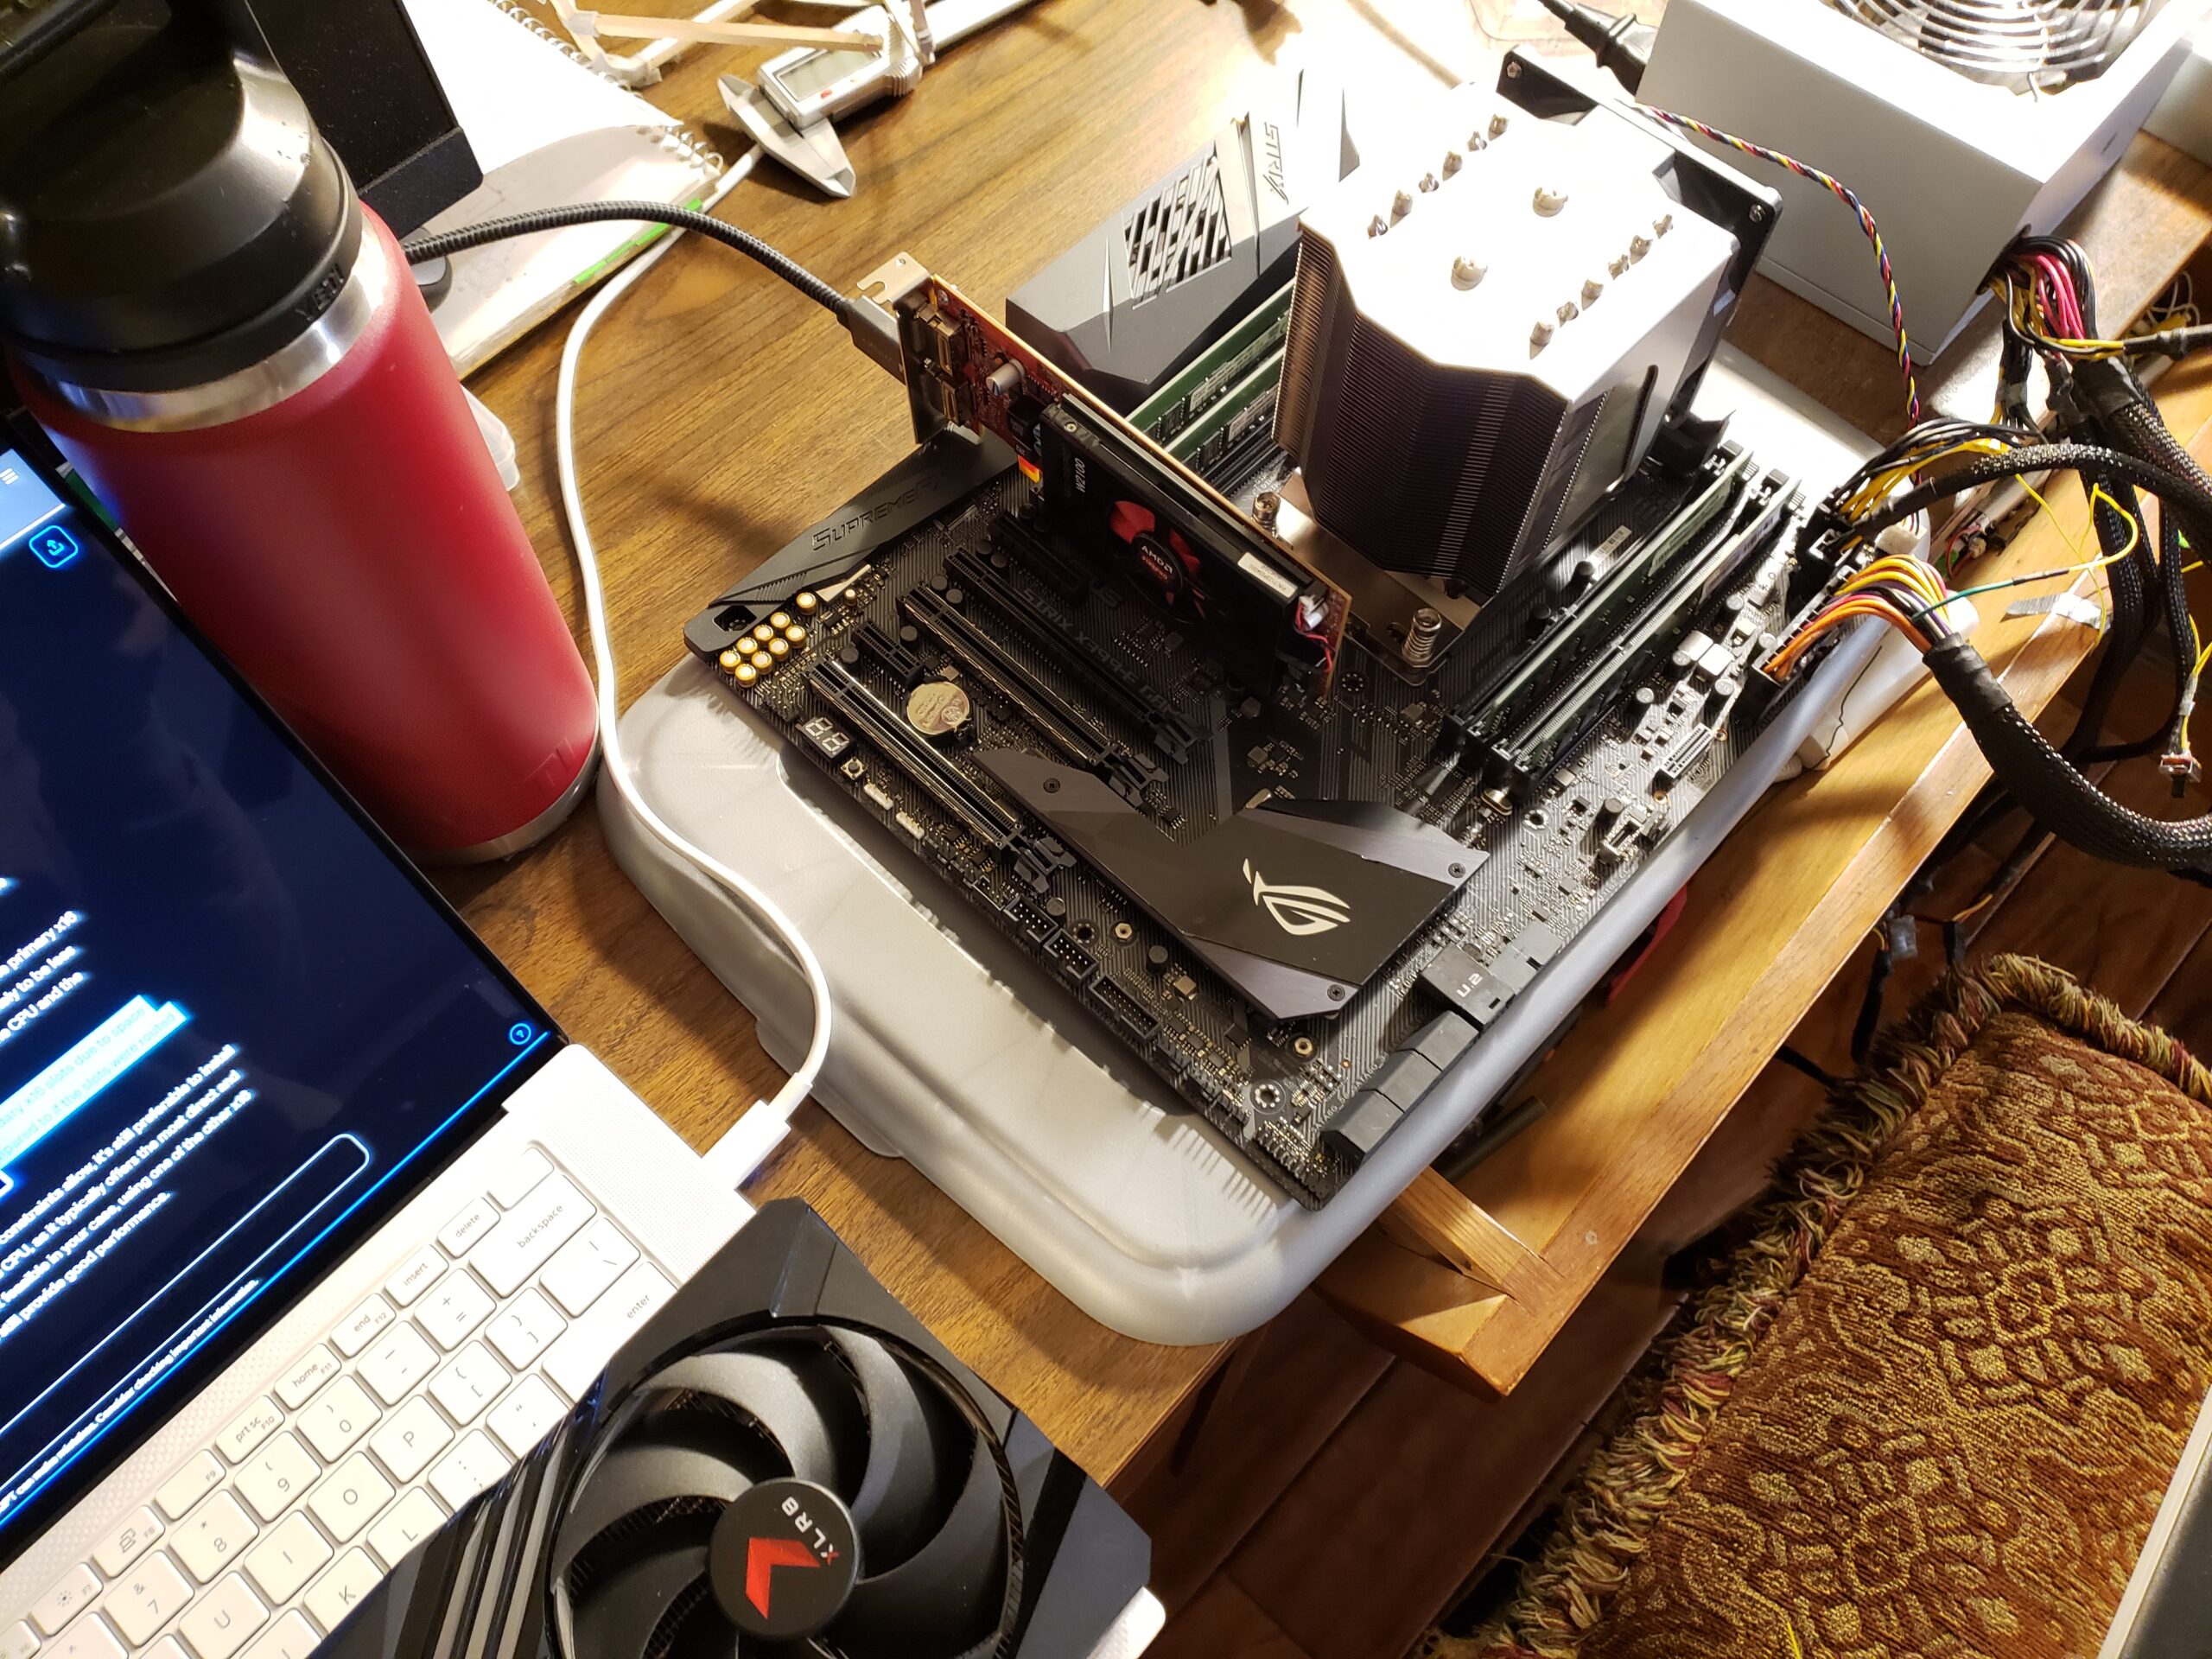
I recorded the first power up of the server just in case something went up in smoke (Sorry for my excitement)
This is when the server posted for the first time. Flicking the switch was mostly uneventful so this is the recording where it finally worked. I was eventually able to disable the RGB on the GPU by unplugging a header on the board. I also made the P40’s 40mm fan quieter by connecting the sense and tachometer wires together through a resistor.
Wow It Is Fast!
I did some quick testing with the new 4080 and it can really multiply matrixes!
If you look at my first post you will see that the R720 with dual P40s could push 22 t/s. Later I was able to get this up to around 30 t/s using GGUF models (a different type of compression). This single 4080 has more then double their combined performance! This should allow for nearly instant speech-to-speech if 45 can send and receive the audio quick enough. I likely won’t get to the programming next week but I’ve got 4.5 posts left to make (presentation is on Wednesday, May 8th) so I’m on a good pace.
This Week's Gallery
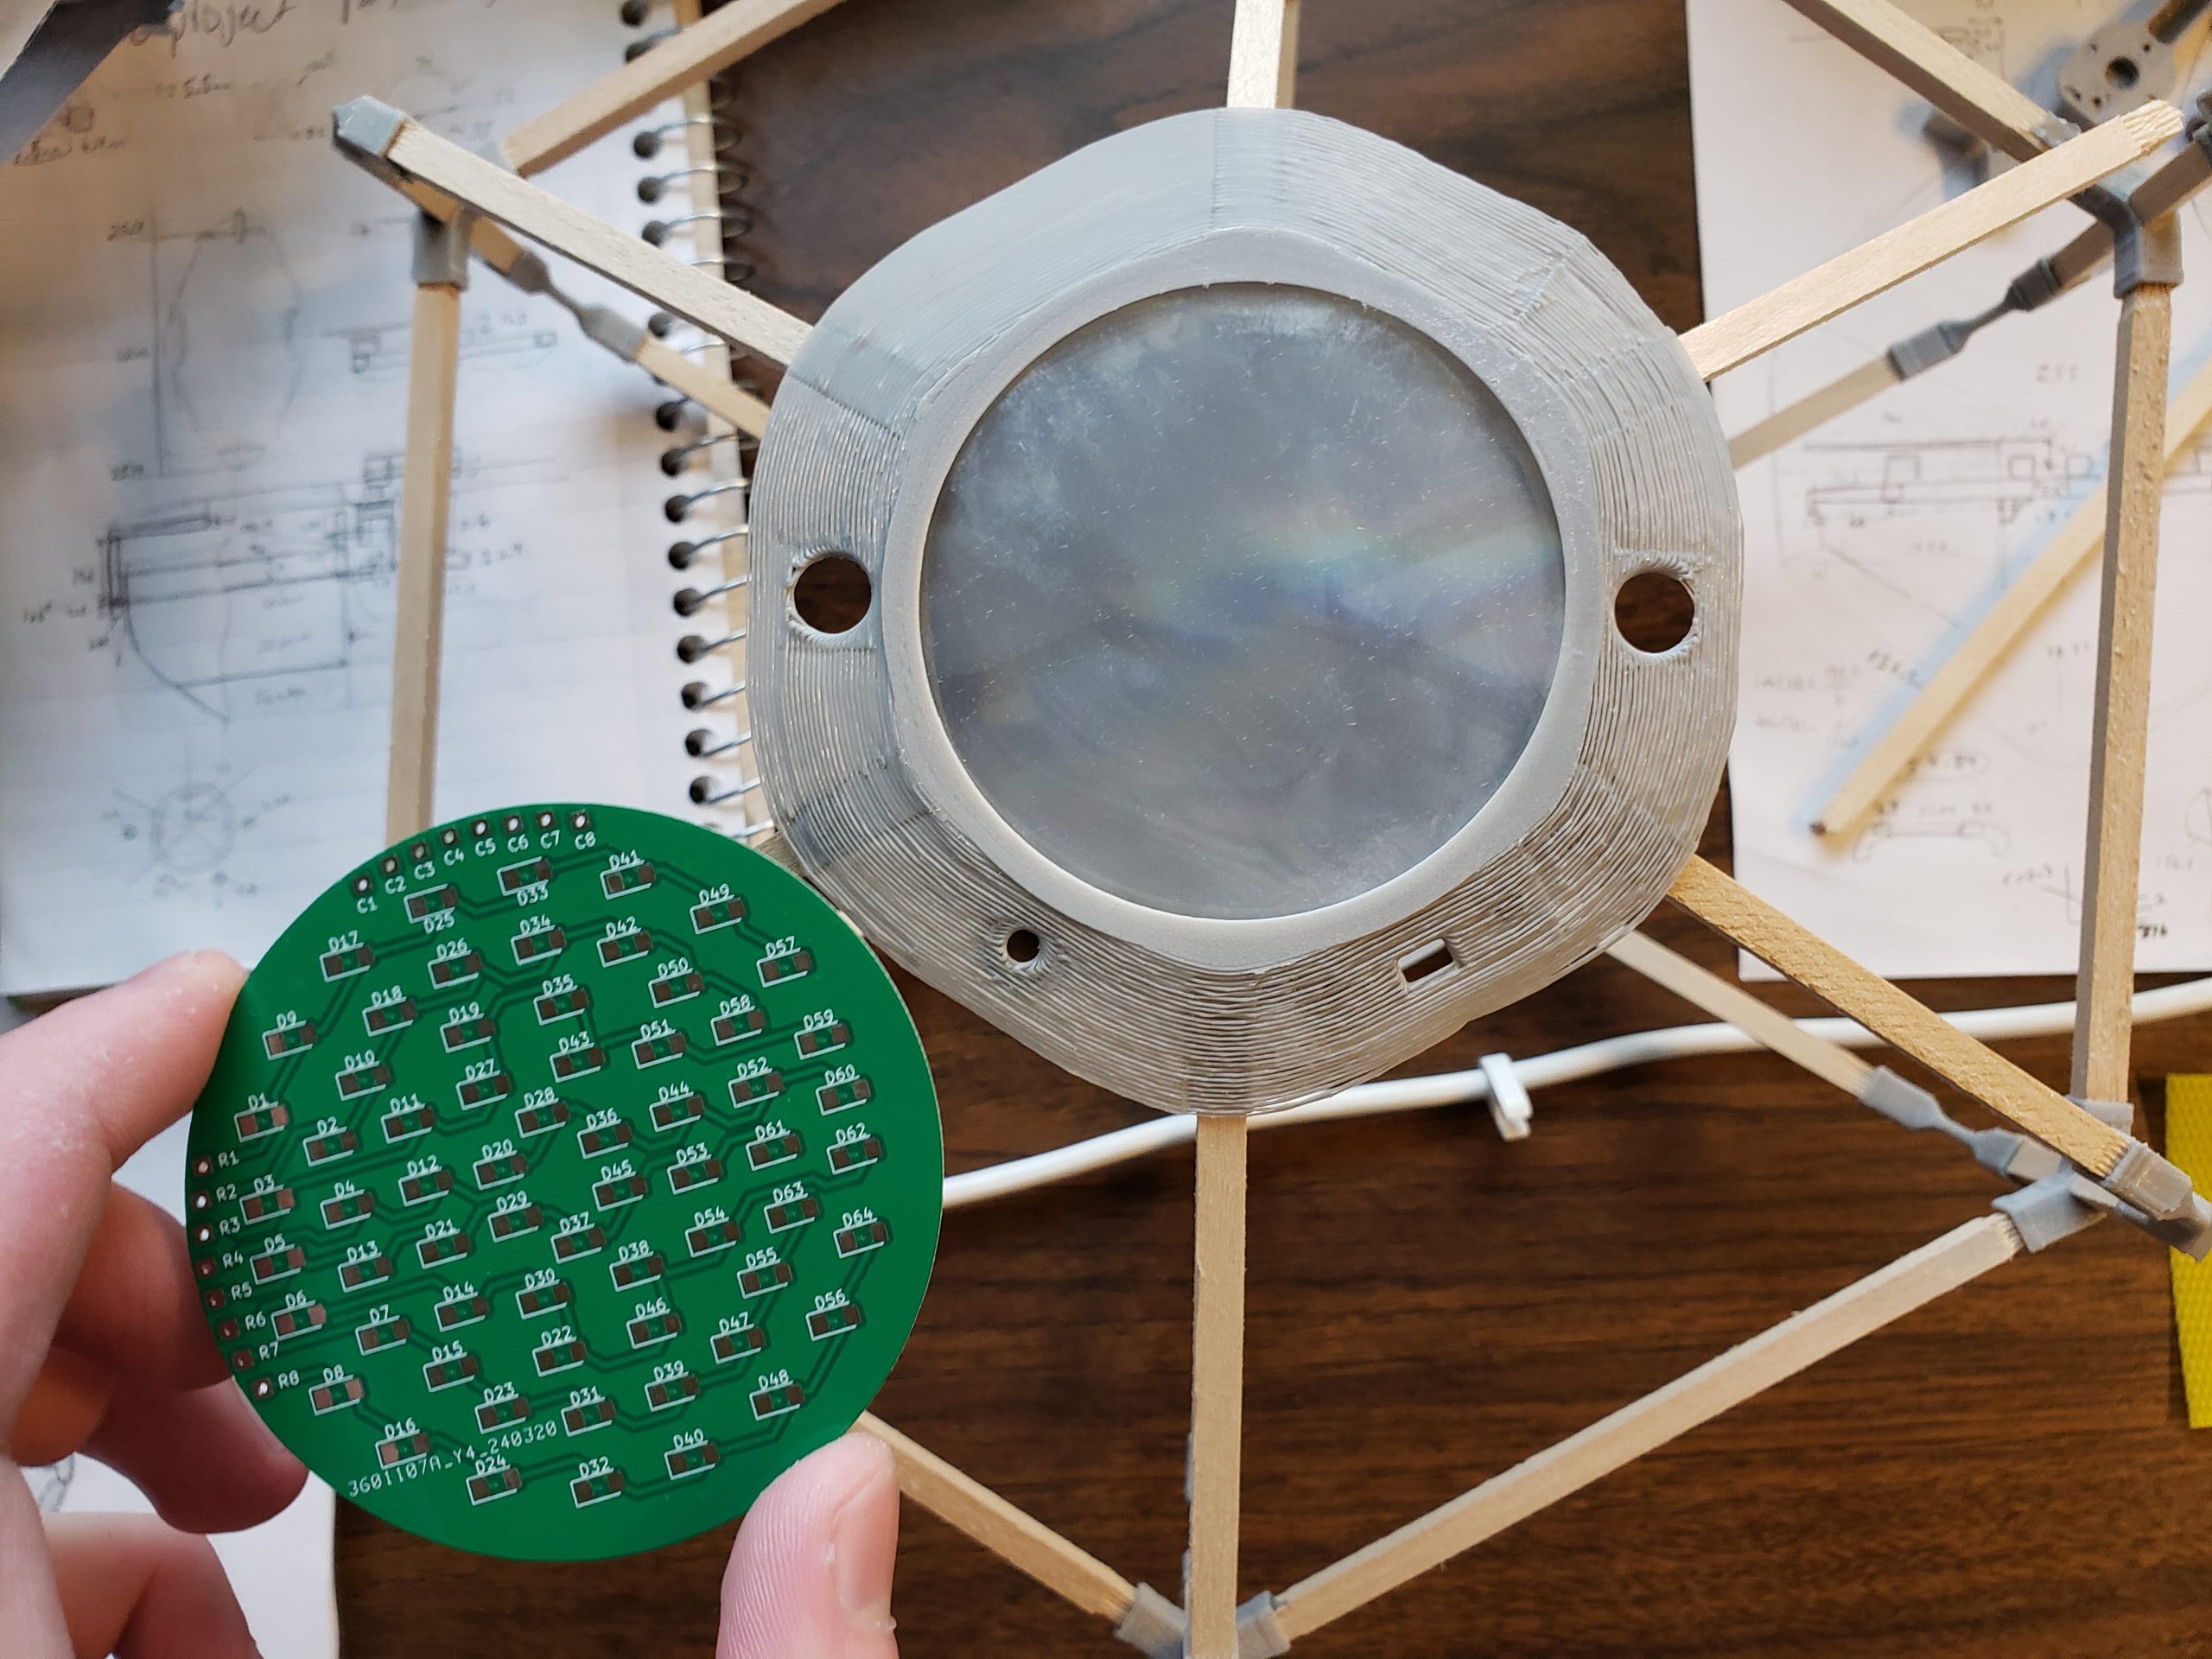
Getting the PCB in
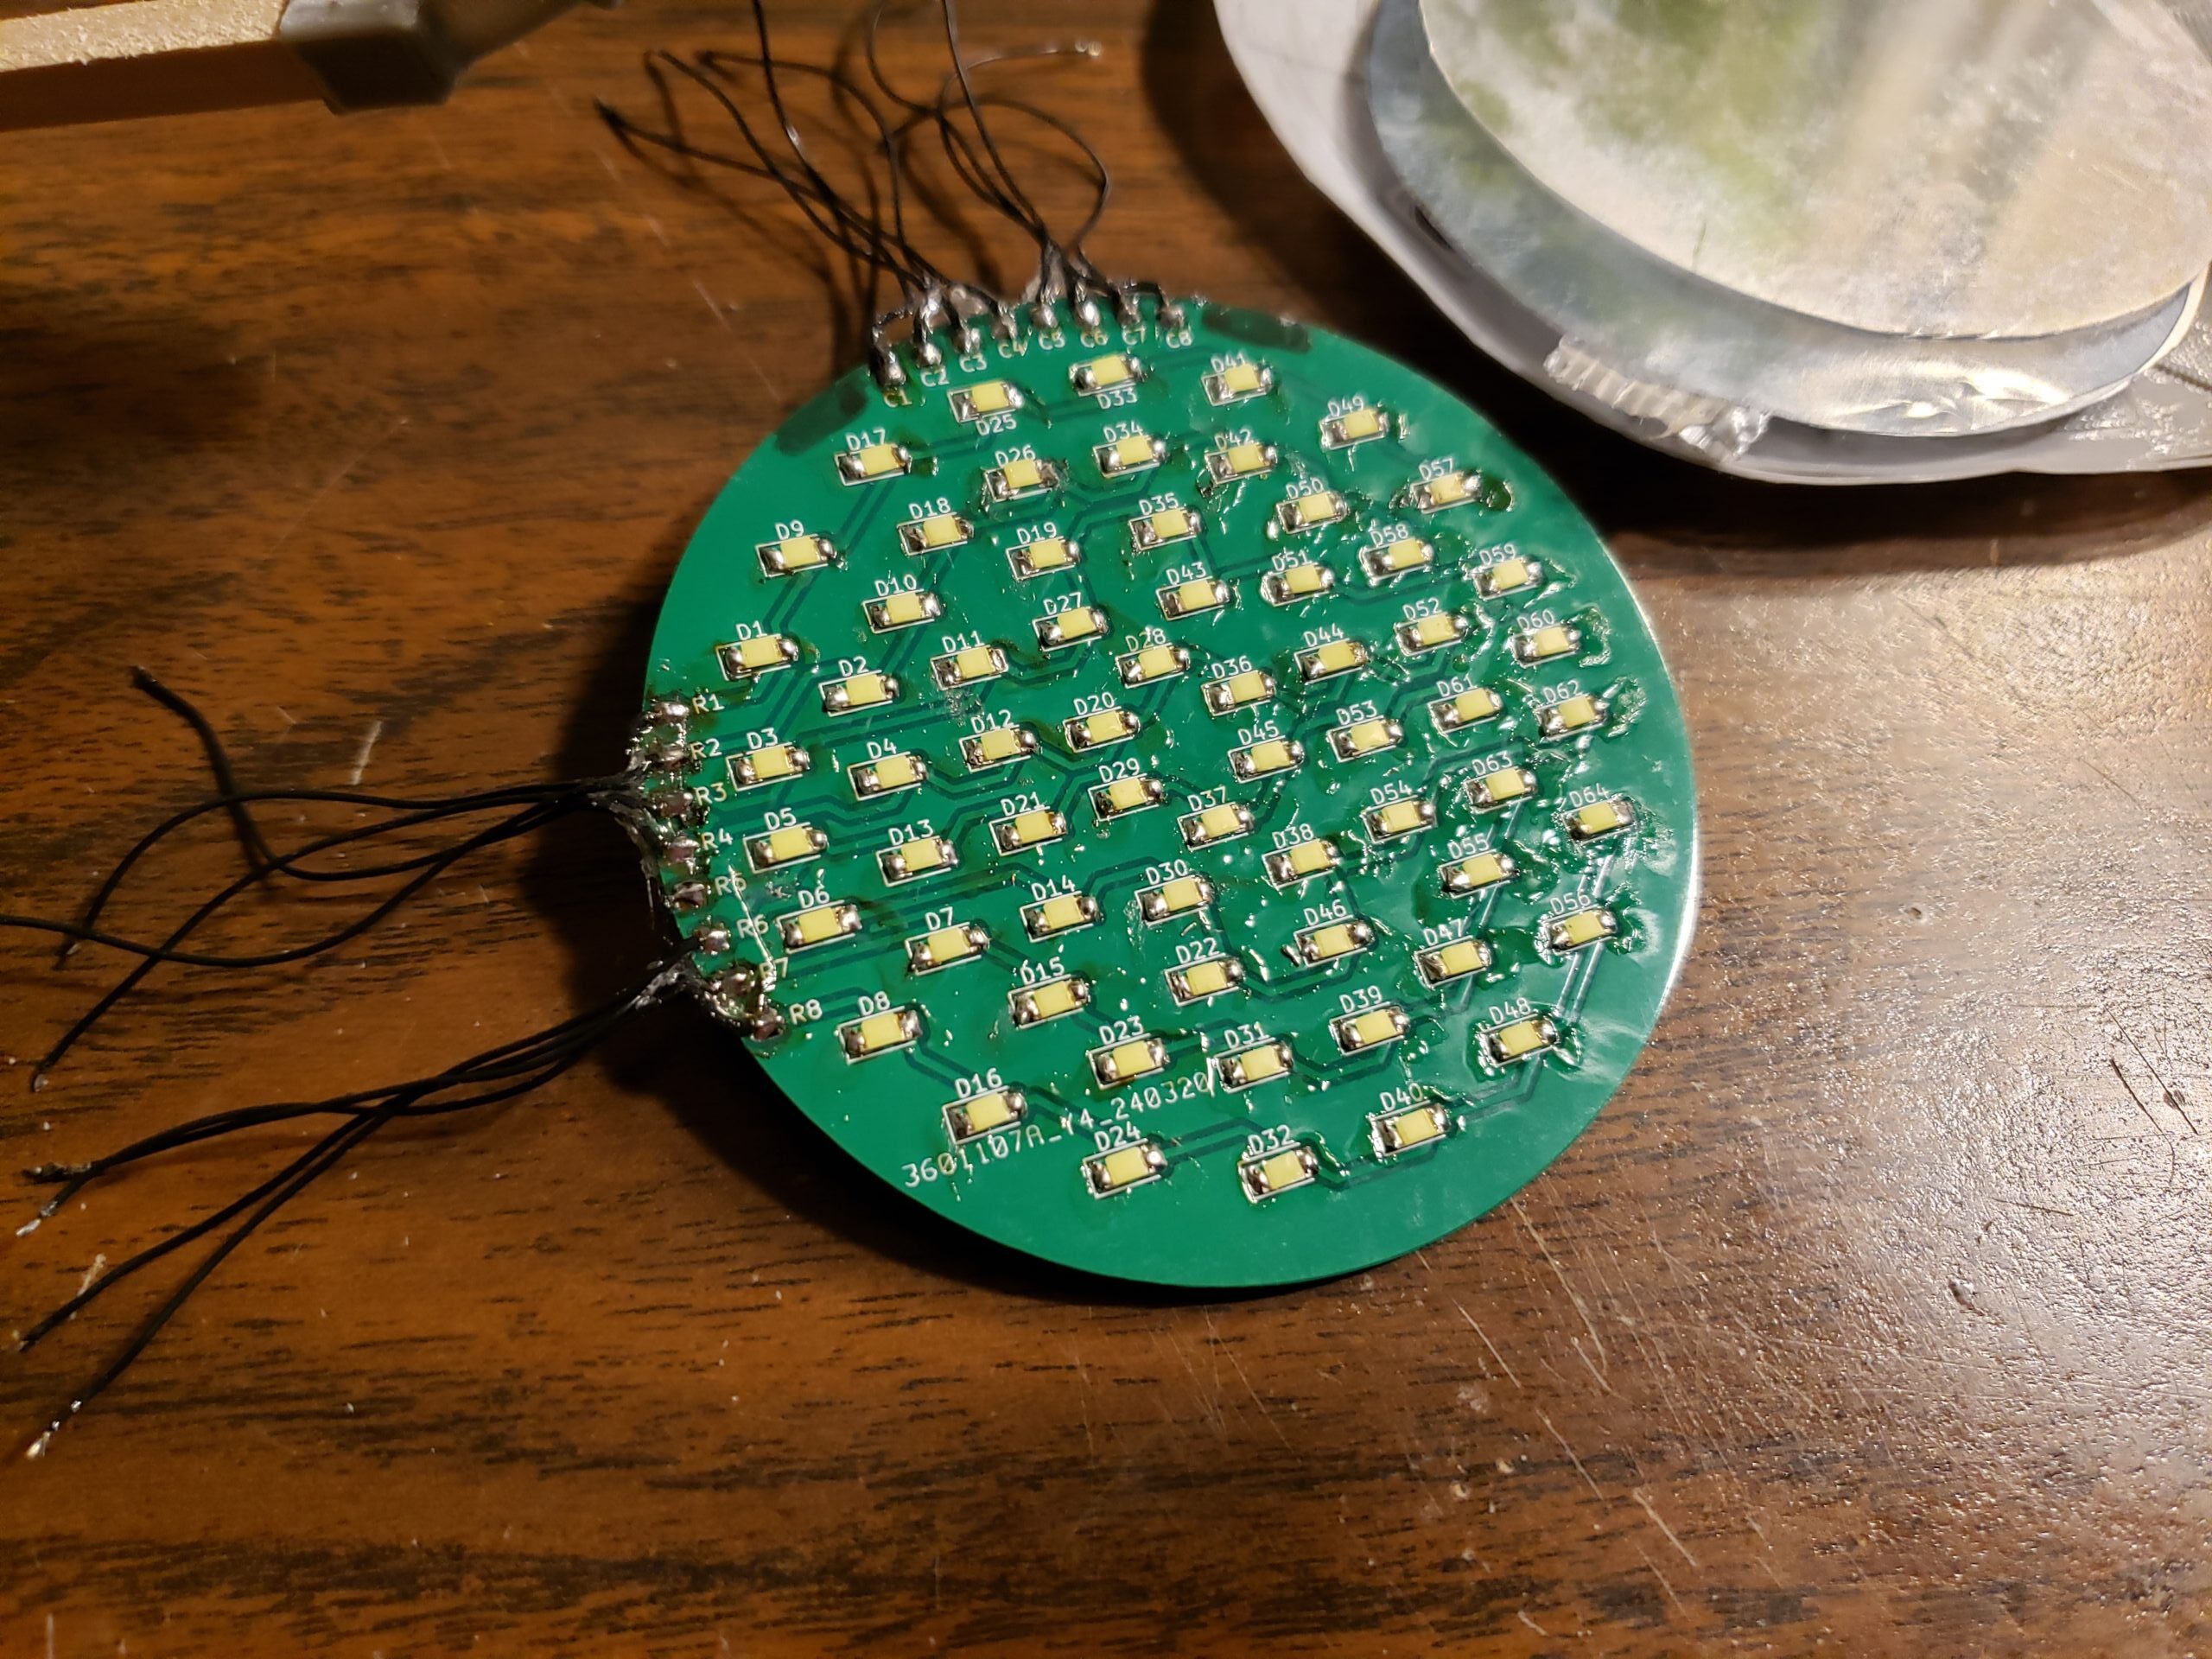
Hand soldering the LEDs
Completed emotion matrix assembly
Corrected and reinforced elbow
Breaking out the 100W soldering iron
That's some power right there!
Installing the new CPU
Post test with smaller GPU
R720 Final moments
Removing parts from the R720
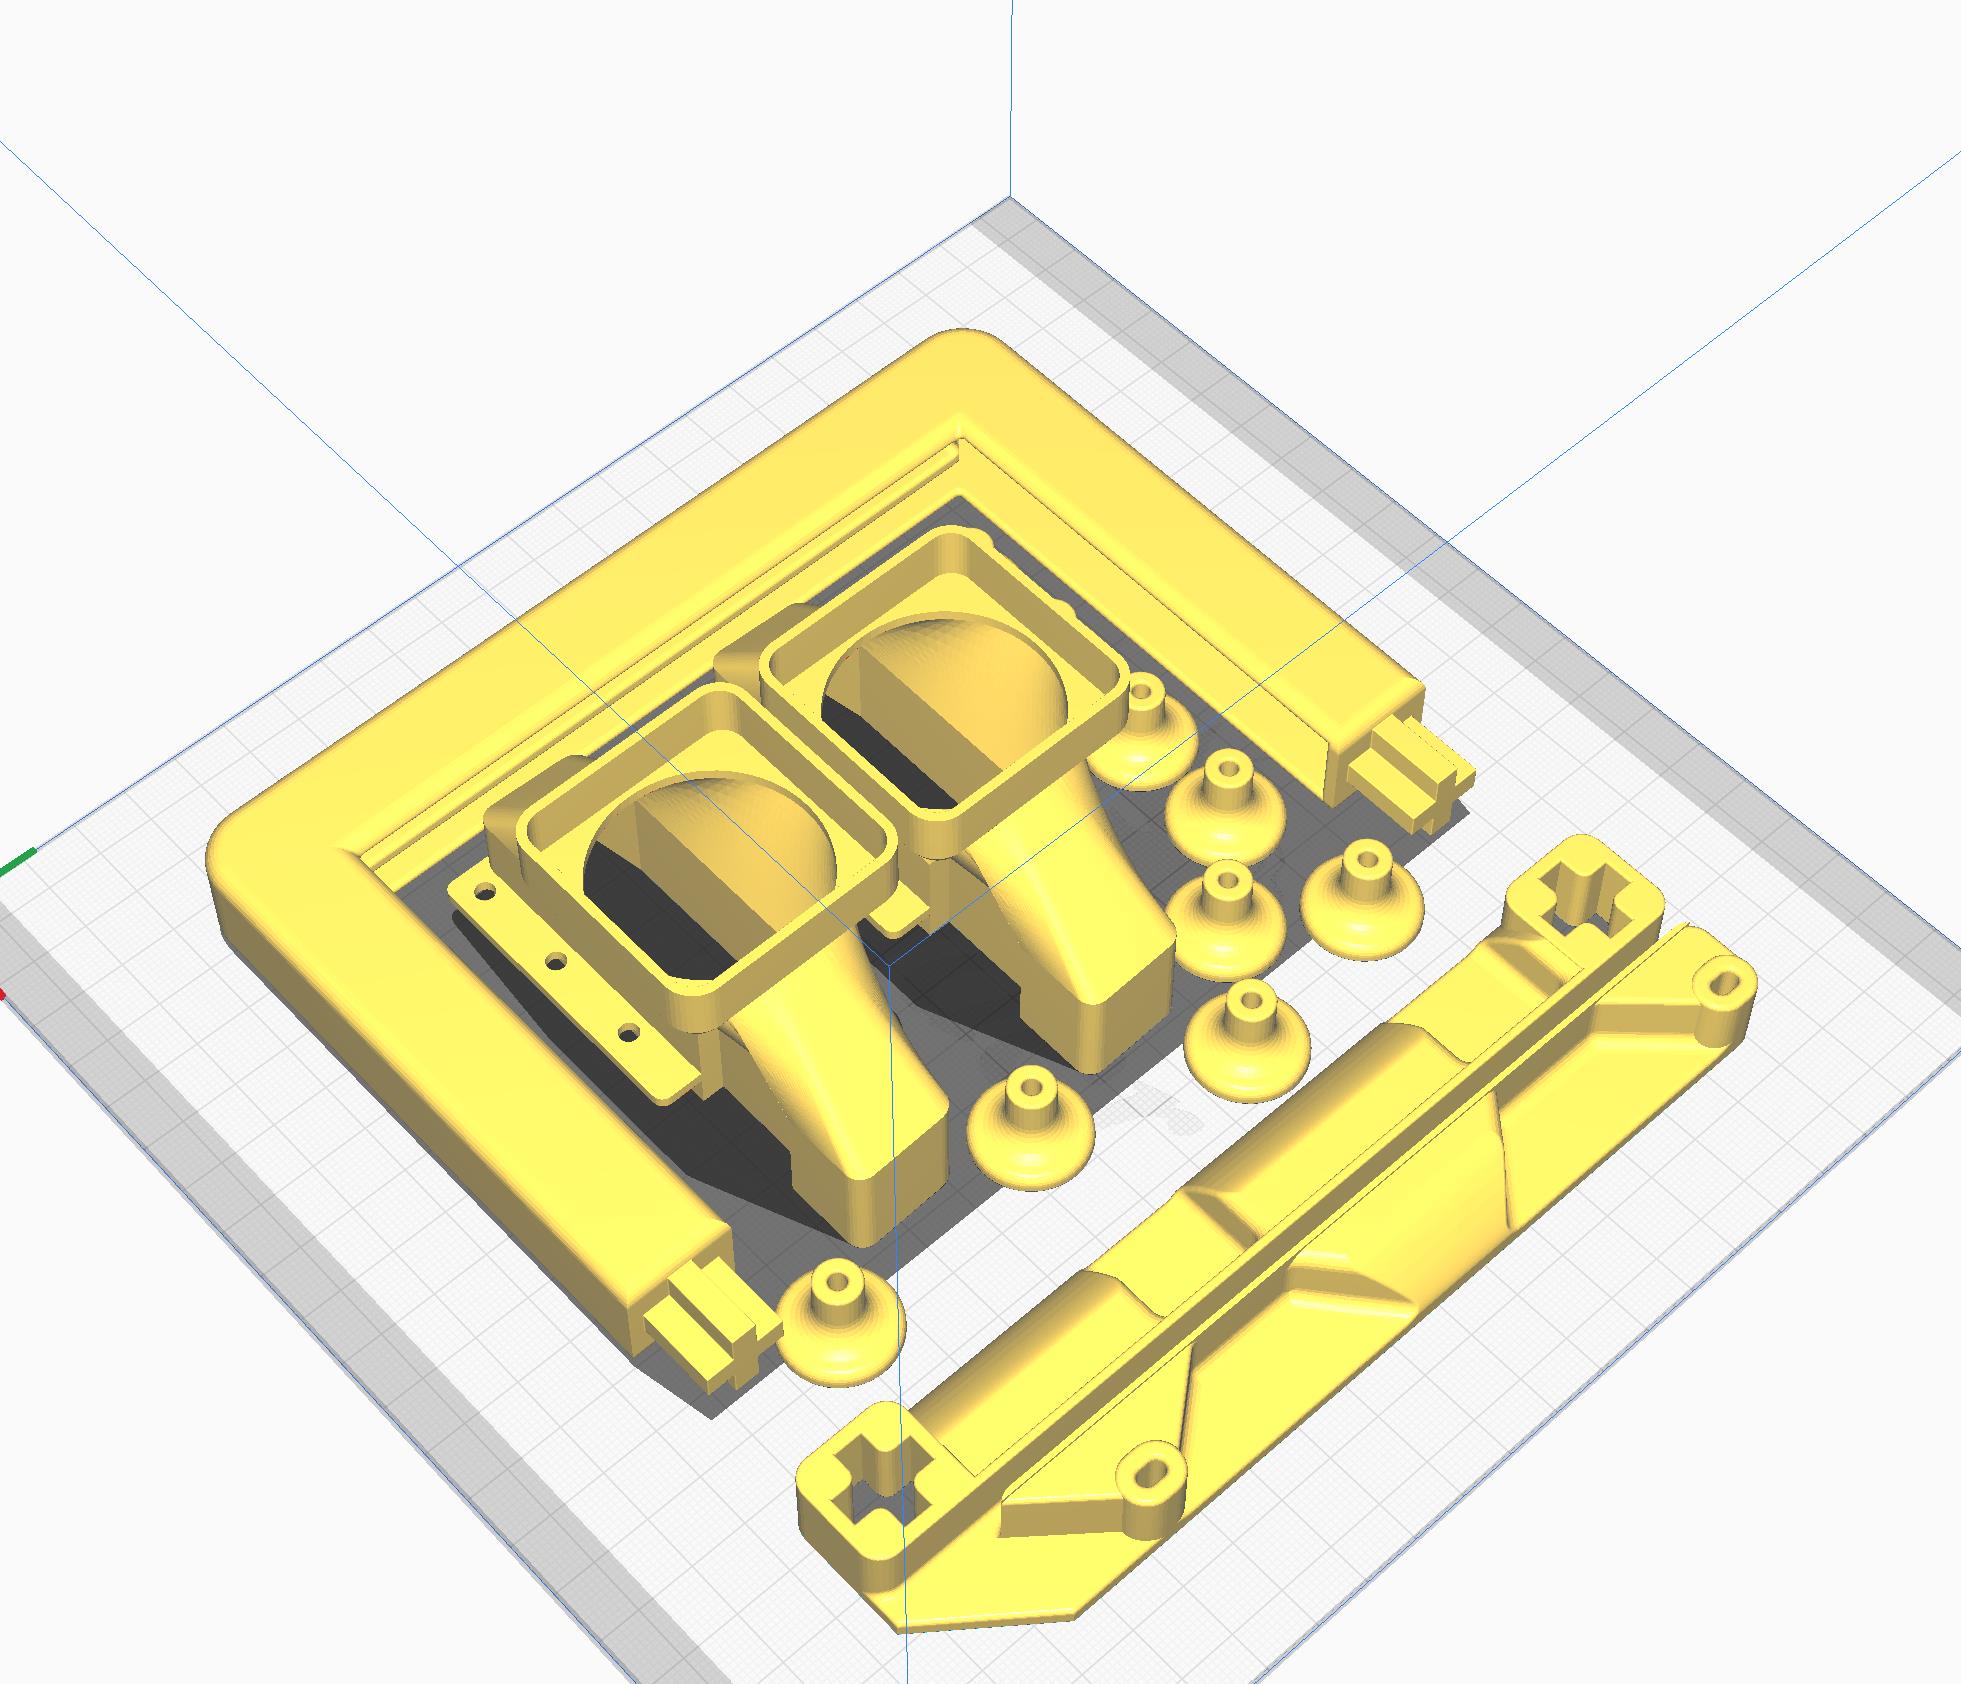
All models needed for the new server
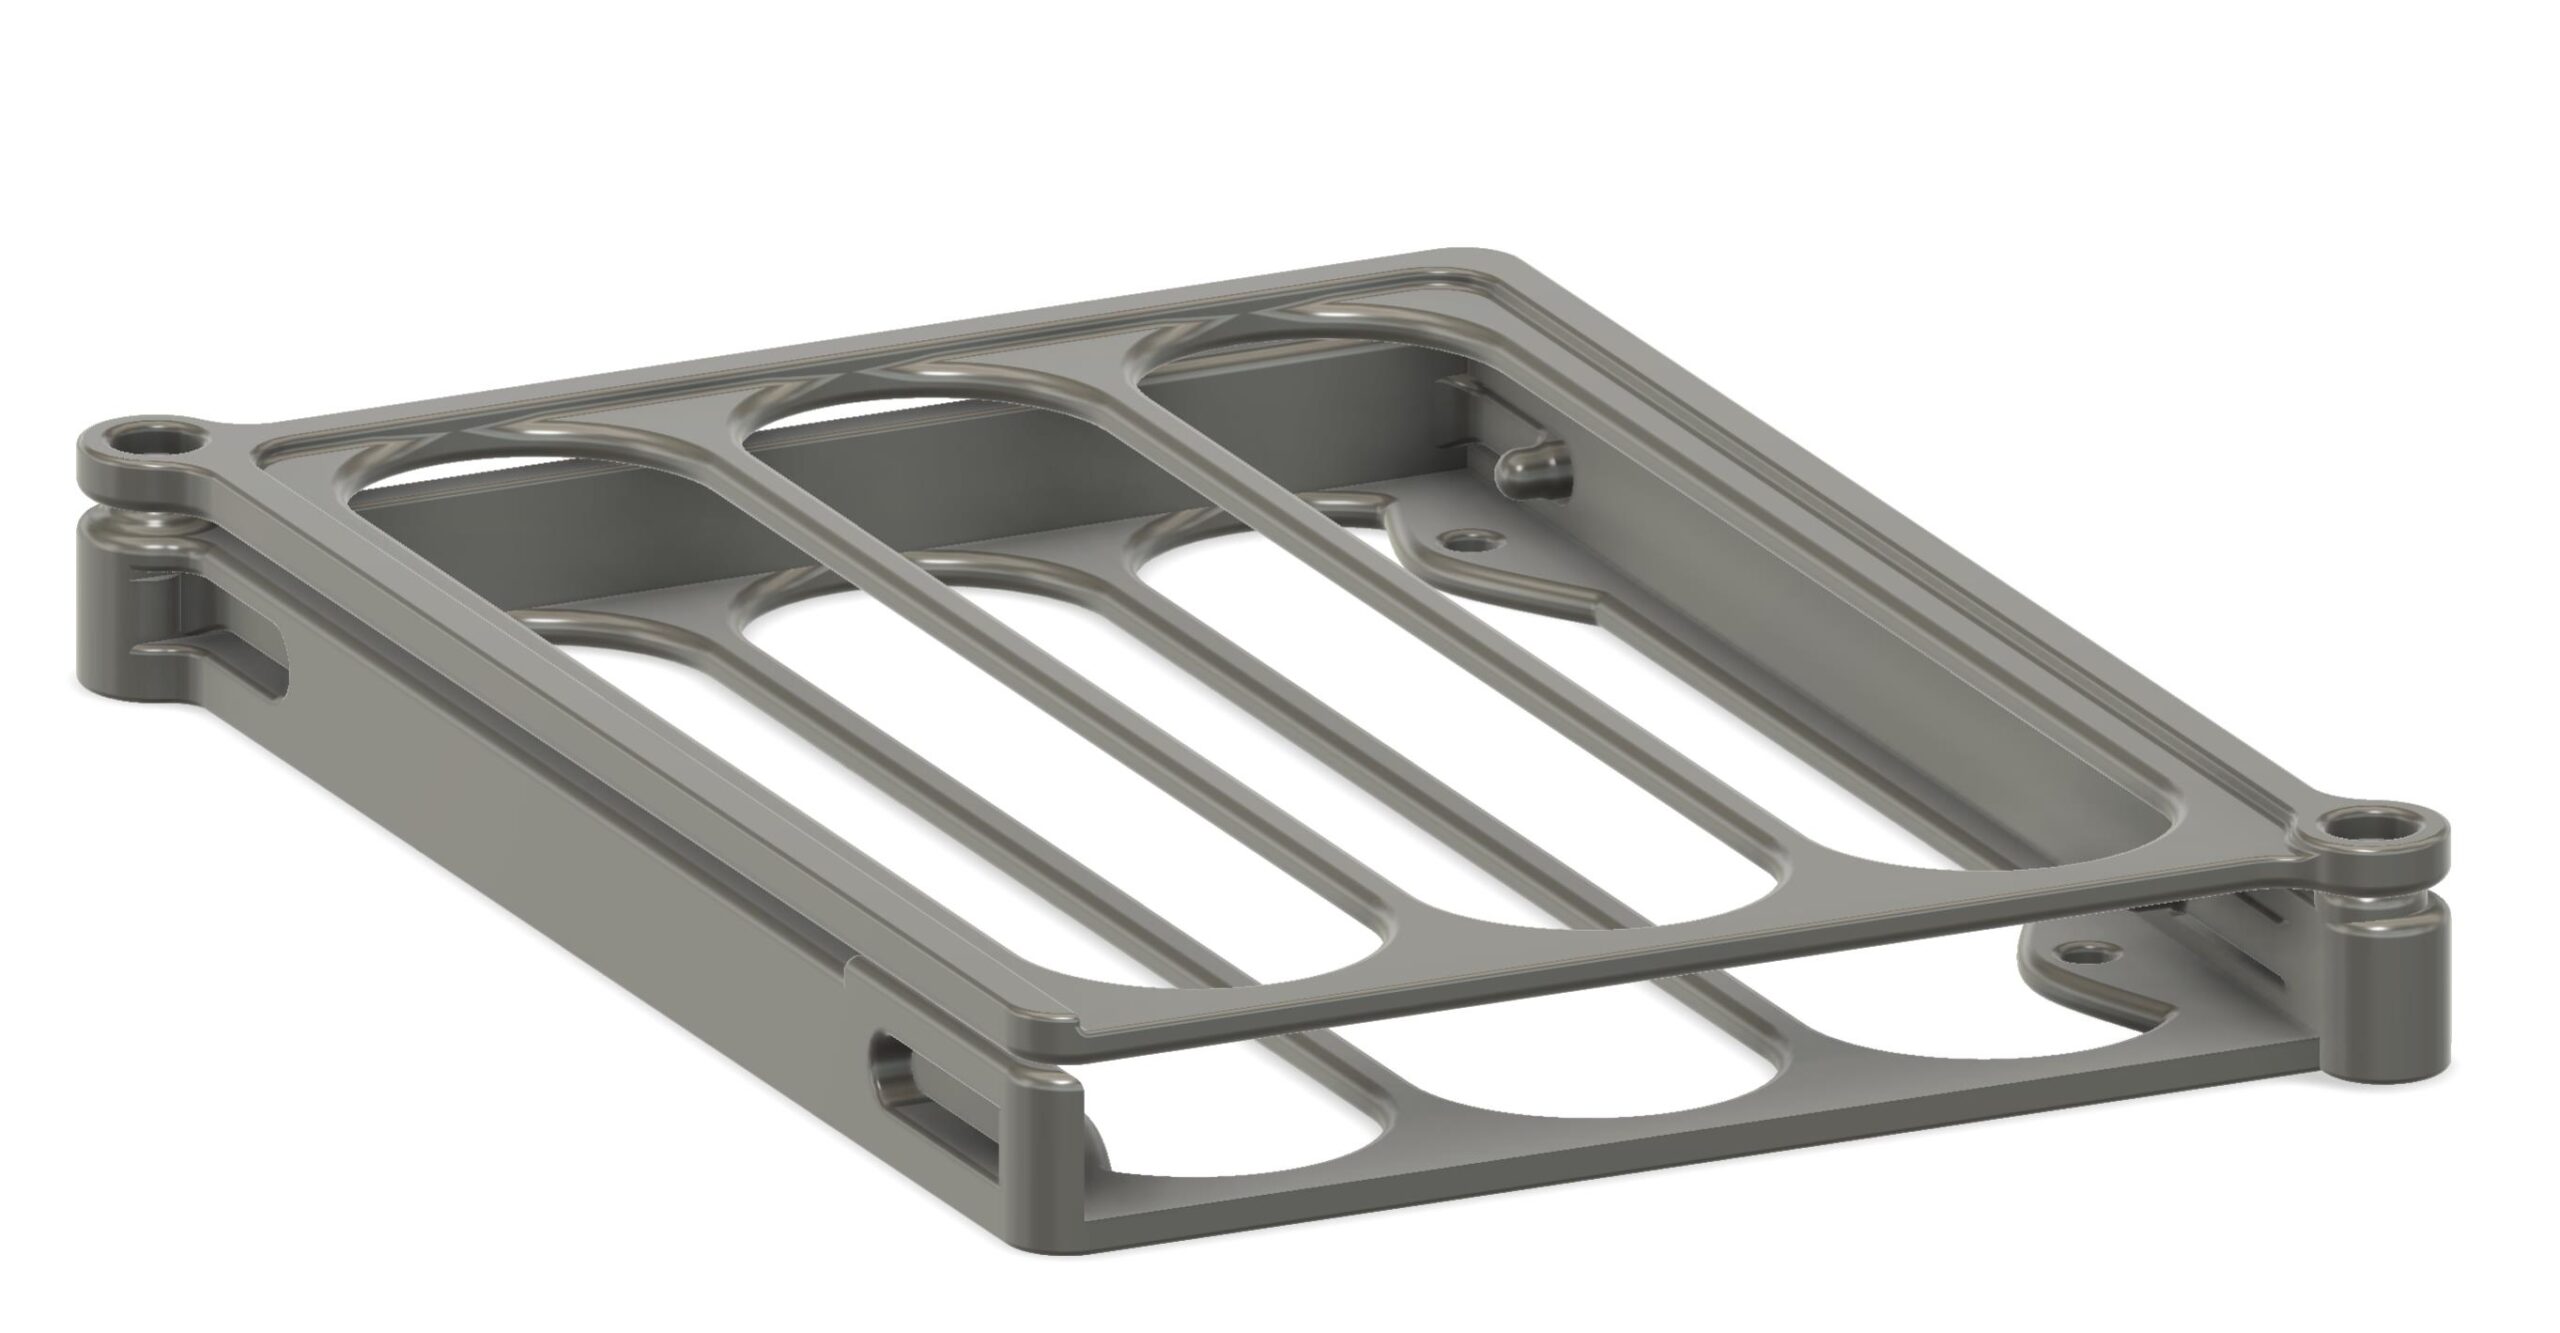
My custom toolless 2.5" drive enclosure
Initial power up
Installing Proxmox
New server in the "rack"
Janky power solution but it works flawlessly
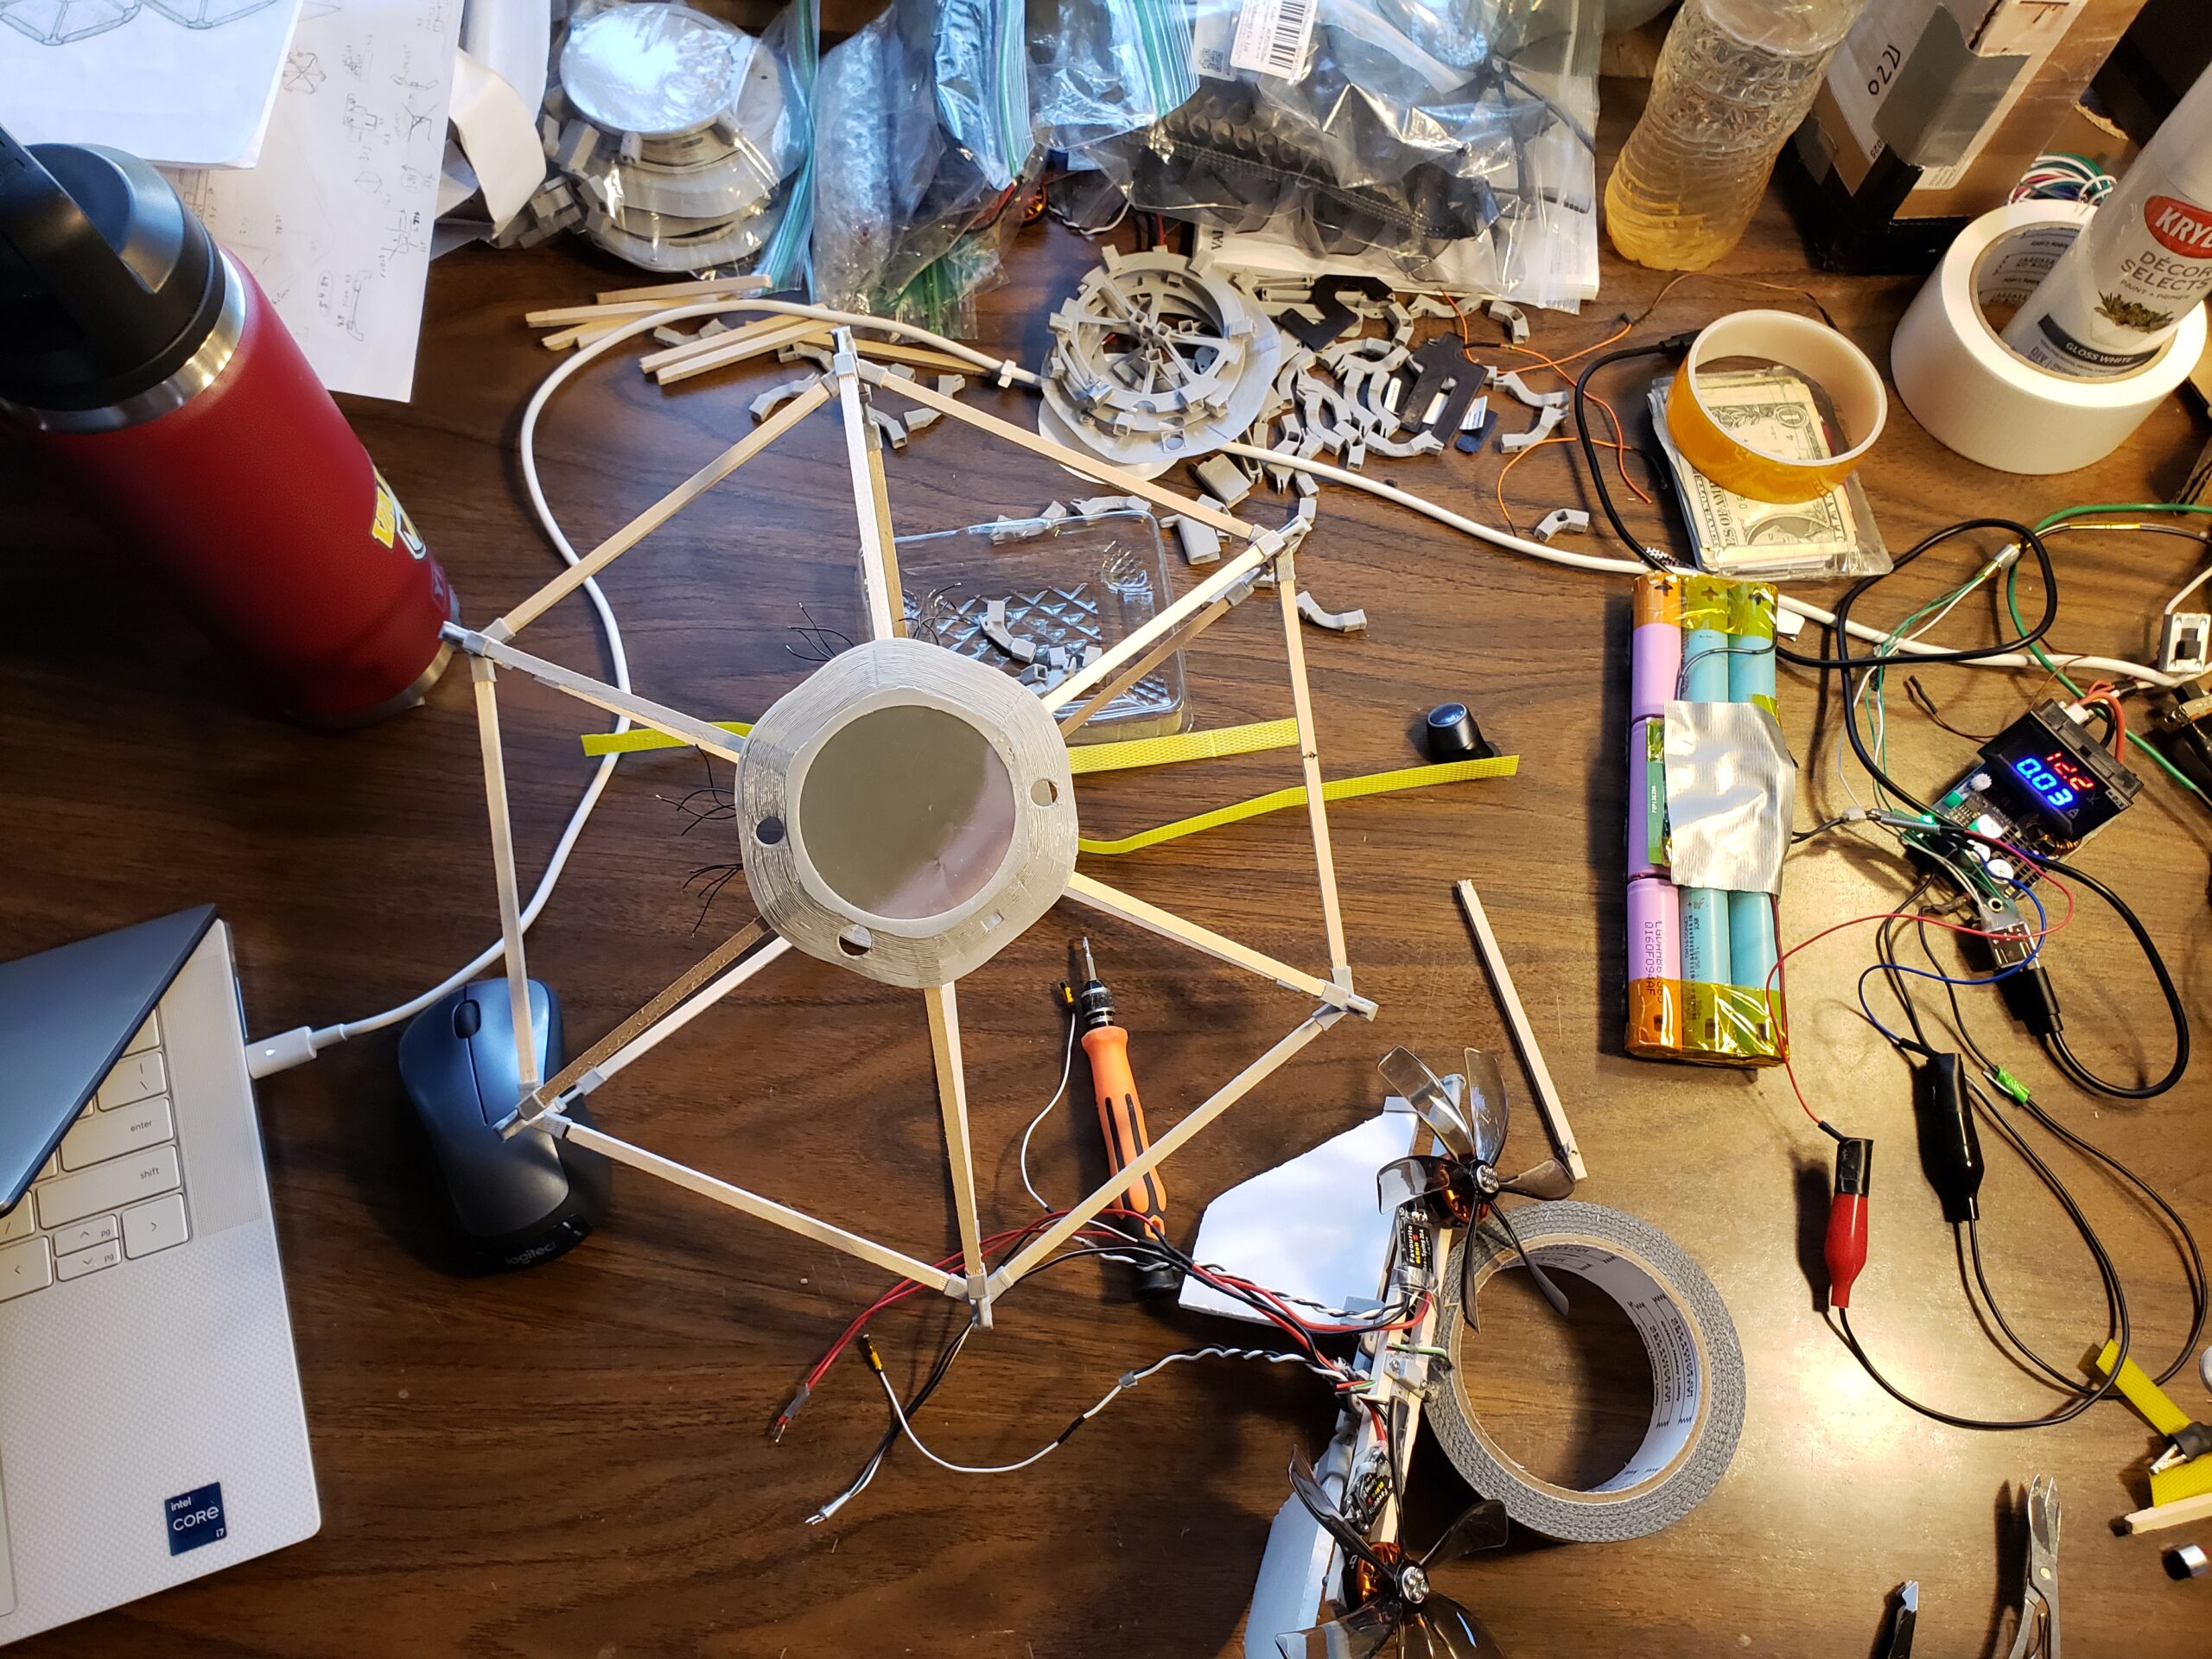
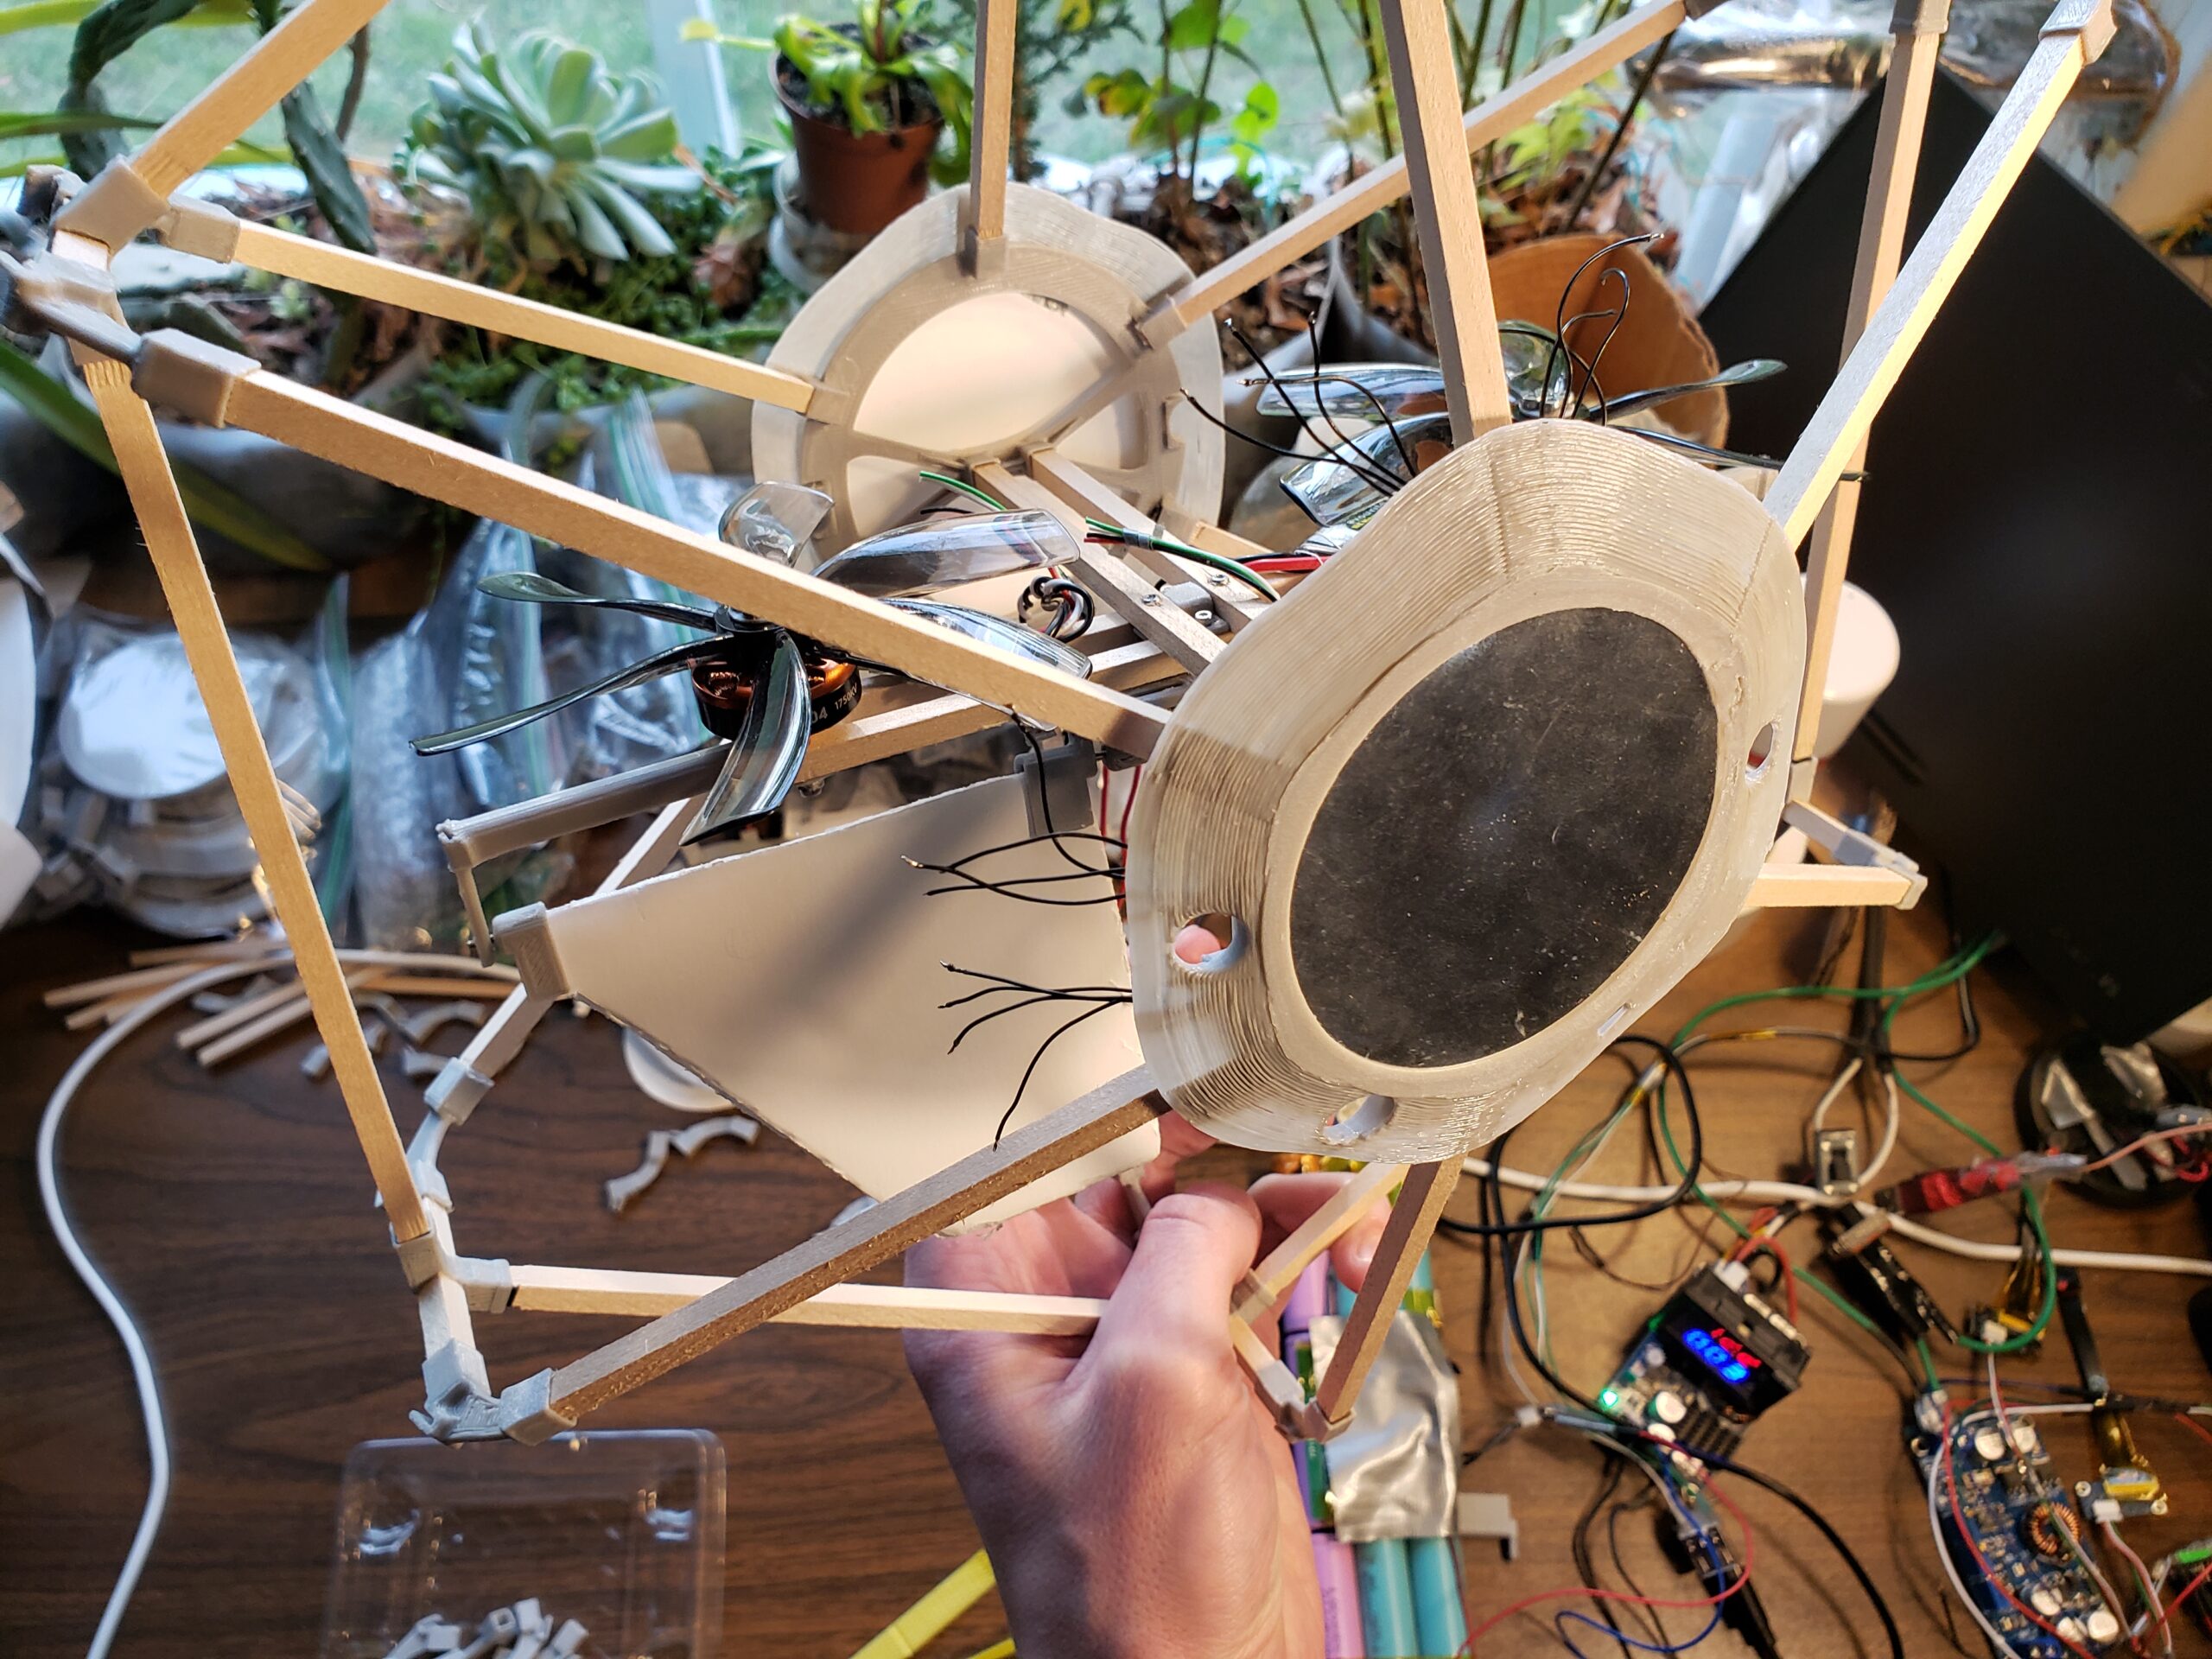
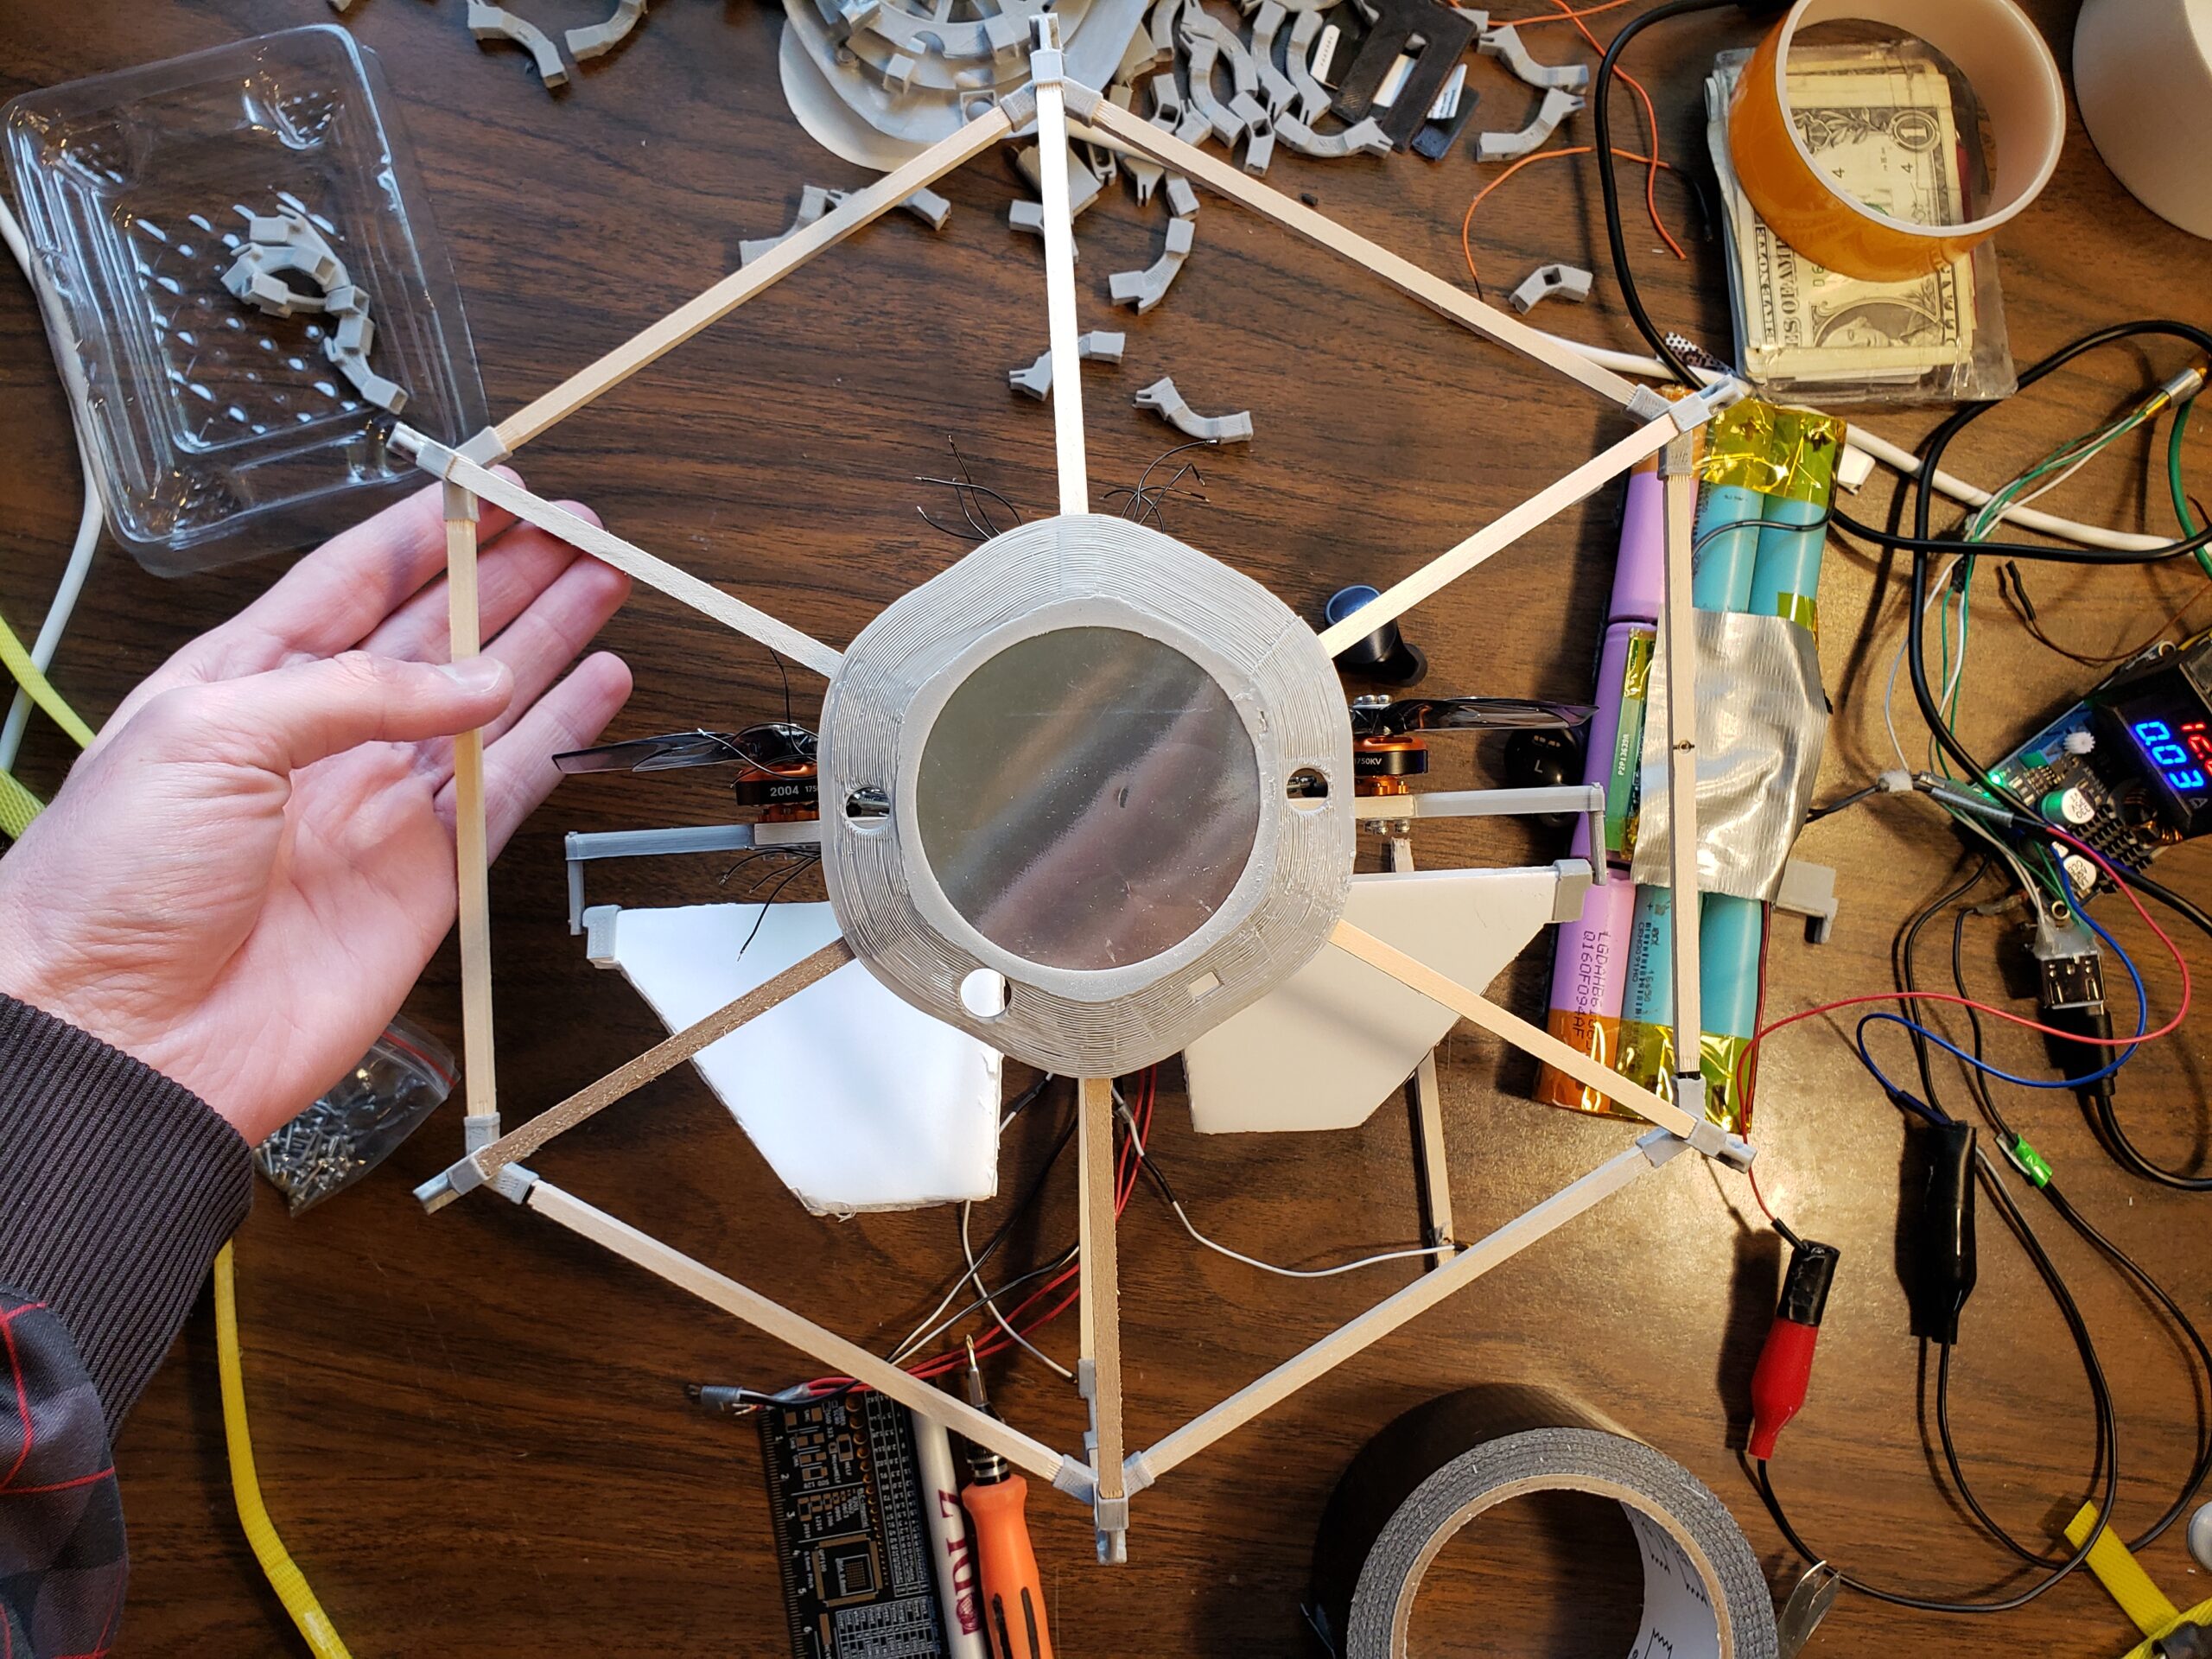
Quickly making progress on the tile build
Installing the thrust assembly
This size isn't final, I'll likely reduce the tolerance a bit
Plan for Remaining Weeks
I think I’m on pace to get my demo goals done but I want to be certain
Post 7 (Sun 14th): – Add foamboard panels to complete the assembly – Cut all the wires to the correct length after I mount all the hardware in the Tile – Resolder the circuit to the RPi zero
Post 8 (Sun 21st): – Install all the needed AI models on the server – Write the python script to accept audio and return speech (silence submits prompts) – Connect the RPi to the server to steam audio – Sentiment analysis for eye control if possible
Post 9 (Sun 28): – Additional programming for server-RPi connection – Tethered flight hopefully?
Post 10 (Sun May 5th): – Check for keywords in voice input “45”, commands, etc. – Additional work on flight – Get cameras working if time allows
Post 11 (Wed May 8th Midnight): – I won’t have time to make a post before the demo so I might record it and make a post with final thoughts and plans for V2! (hydrogen based)
Hopes and Dreams for the Tile project:
I’m very excited to continue this project as I think the next model could have real potential. This initial model is for learning and to get others on board with the project. I hope to get a team together after this model to help in areas I’m weak in (CAD, programming, …many more). The game plan is:
Next Year:
Get the V2 model in a place where I can bring it to campus with me a few days a week. Every Friday?
Senior Year, Senior Project:
Deploy 45 as a sales associate or on Geek Squad at our local Best Buy!….
Why isn’t this crazy? I’ve previously worked there in warehouse, sales, and I had an offer for Geek Squad before I left for my internship. I have connections there. I would also pitch it as if they were hiring me and 45 is just there to help me. It would be just like looking things up on my phone but in a faster and more interactive way. This would ensure that they wouldn’t need to jump though hoops to get my robot operating in their store.
I would always be just a few feet away if something went wrong. 45 wouldn’t even need to fully complete on the vision side to be useful. I used AI to research this entire project up to this point -including the server build! AI is already a very good technical support and the models will only get better over the next two years.
We just need to make sure the V2 hardware is up to the task and that the software is in a good spot. If I can build 45 in two months!, I’m sure I can pull off this plan in two years! Especially if I have help.
I’m taking a project course next semester just to work on this and I prepared to dedicate the rest of my college career to this project. This project is a dream for me and I’m motivated to make it real. It has already taught me so much and V2 is going to teach me even more.
Why the Tile Project is Meaningful (OPINION)
Right now the billion dollar AI startups are all chasing humanoid robots. They are focused on the manufacturing side of things and are trying to replace the human assembly role. This might be practical for large businesses that don’t want to pay or don’t have the need to automate things properly with dedicated robots. Human workers can be expensive so humanoid robots might have a niche if they are to be paid off over a few years or so.
I won’t deny that they could fill an assembly or warehouse role but they don’t make sense for the role that AI is already great at. Chatbots are everywhere and are great for answering questions or just talking with. It just doesn’t make sense to build a full humanoid robot for this purpose. Nobody wants a multi-thousand dollar robot clunking around their home being barely helpful. They also require massive amounts of compute power to accurately control their limbs. The “Figure 01” robot has human-like dexterity because it processes visual inputs at 200Hz! That must take a small country’s worth of compute to run properly!
The Tile V2 design will be almost lighter then air and is entirely focused on AI’s current strong suit. This design (if pulled off properly) will always beat them on price point, Safety around people, SCALABILITY, and usability. Humanoid robots still struggle with walking so flight will allow this design to be much more mobile in an indoor space. There is definitely a market for a simpler robot that focuses on the chat aspect of AI.
The hydrogen base isn’t an issue either because pure hydrogen isn’t explosive or easy to light. I built a electrolysis reactor in high school and used it to float vegetable bags. I would then bring these bags of pure hydrogen out to the driveway with a lighter to see what would happen. I was always disappointed when not much happened. I would light the bag and the hydrogen would all leak out of the burned hole before it could catch. Even if a flame got to hydrogen based tile, it would just smolder and go out. The hydrogen generator in the base station would need a bubbler to arrest flames but the Tile itself should be safe.
Overall I think that the Tile could be the robotics platform that AI needs reach its full potential. Only time will tell though. The space is constantly changing so over the next two years I’ll figure out where this project is meant to go. This project came from a daydream and I don’t want it to return to one. I believe the V2 concept has potential and work will begin right after the demo. I’m enjoying every second of the all-nighters I have to pull to get this project done!